NU Marine Testing Timeline
Some of the major milestones in the development of our platforms
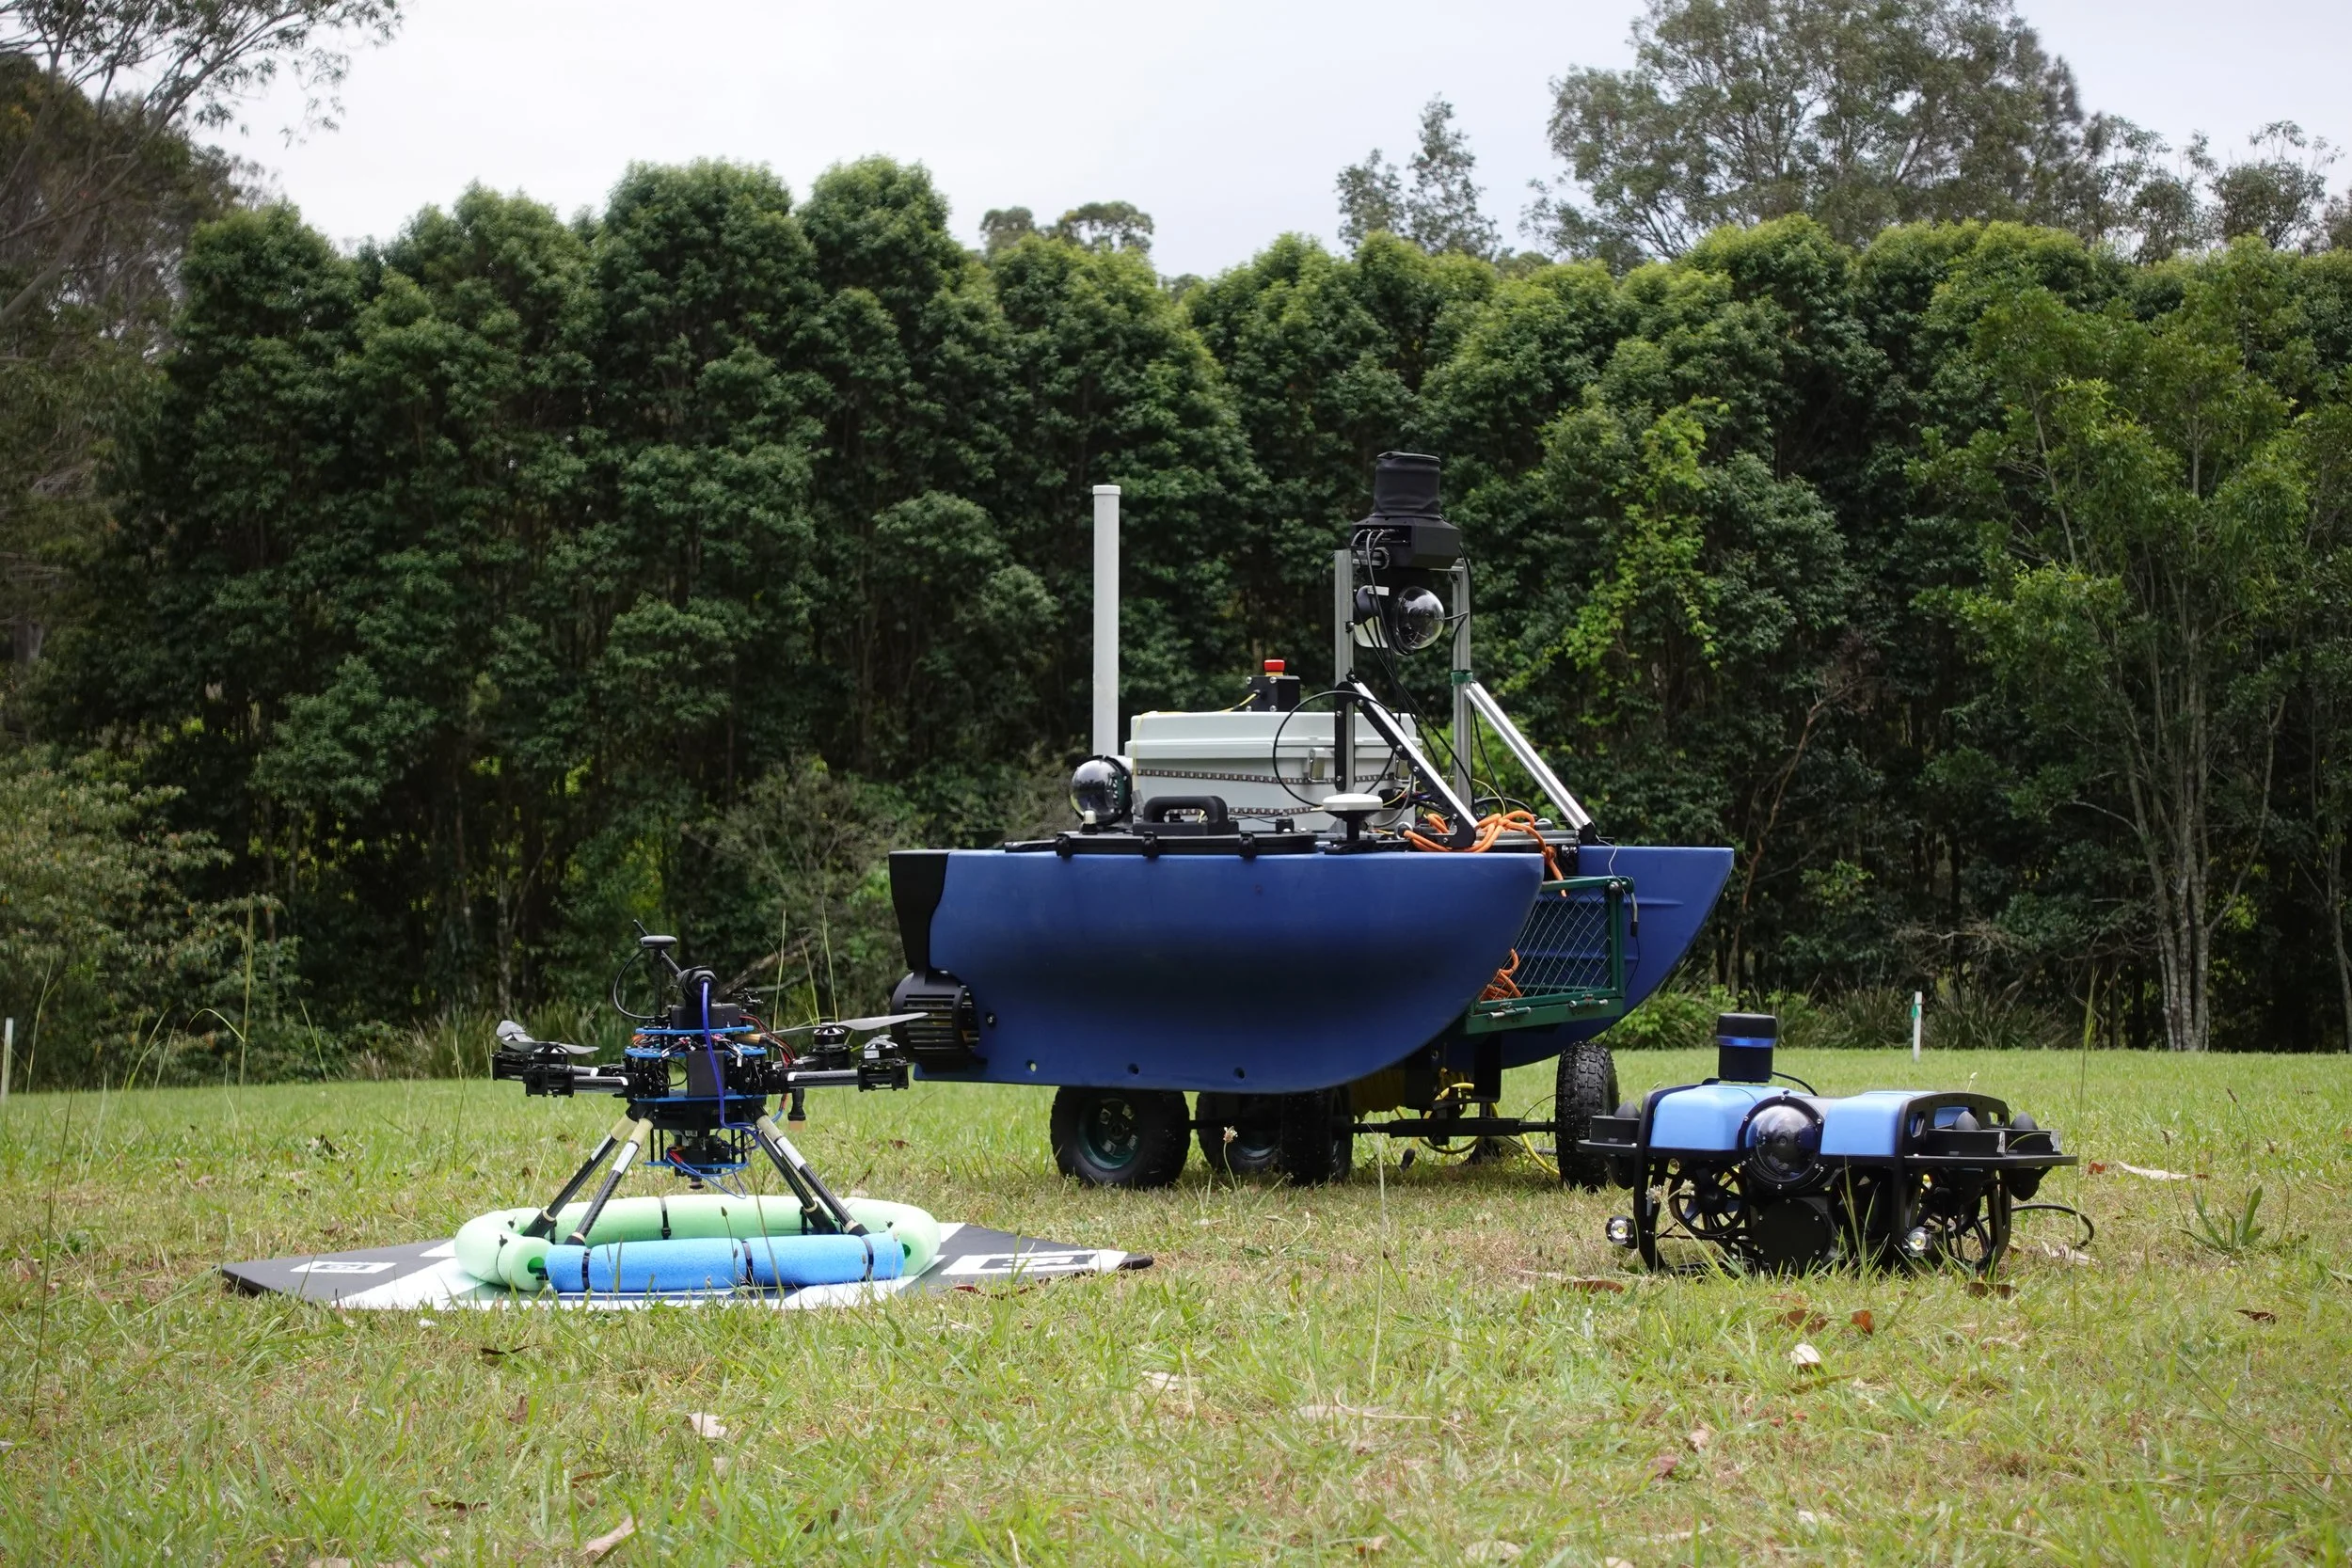
USV - Atlas
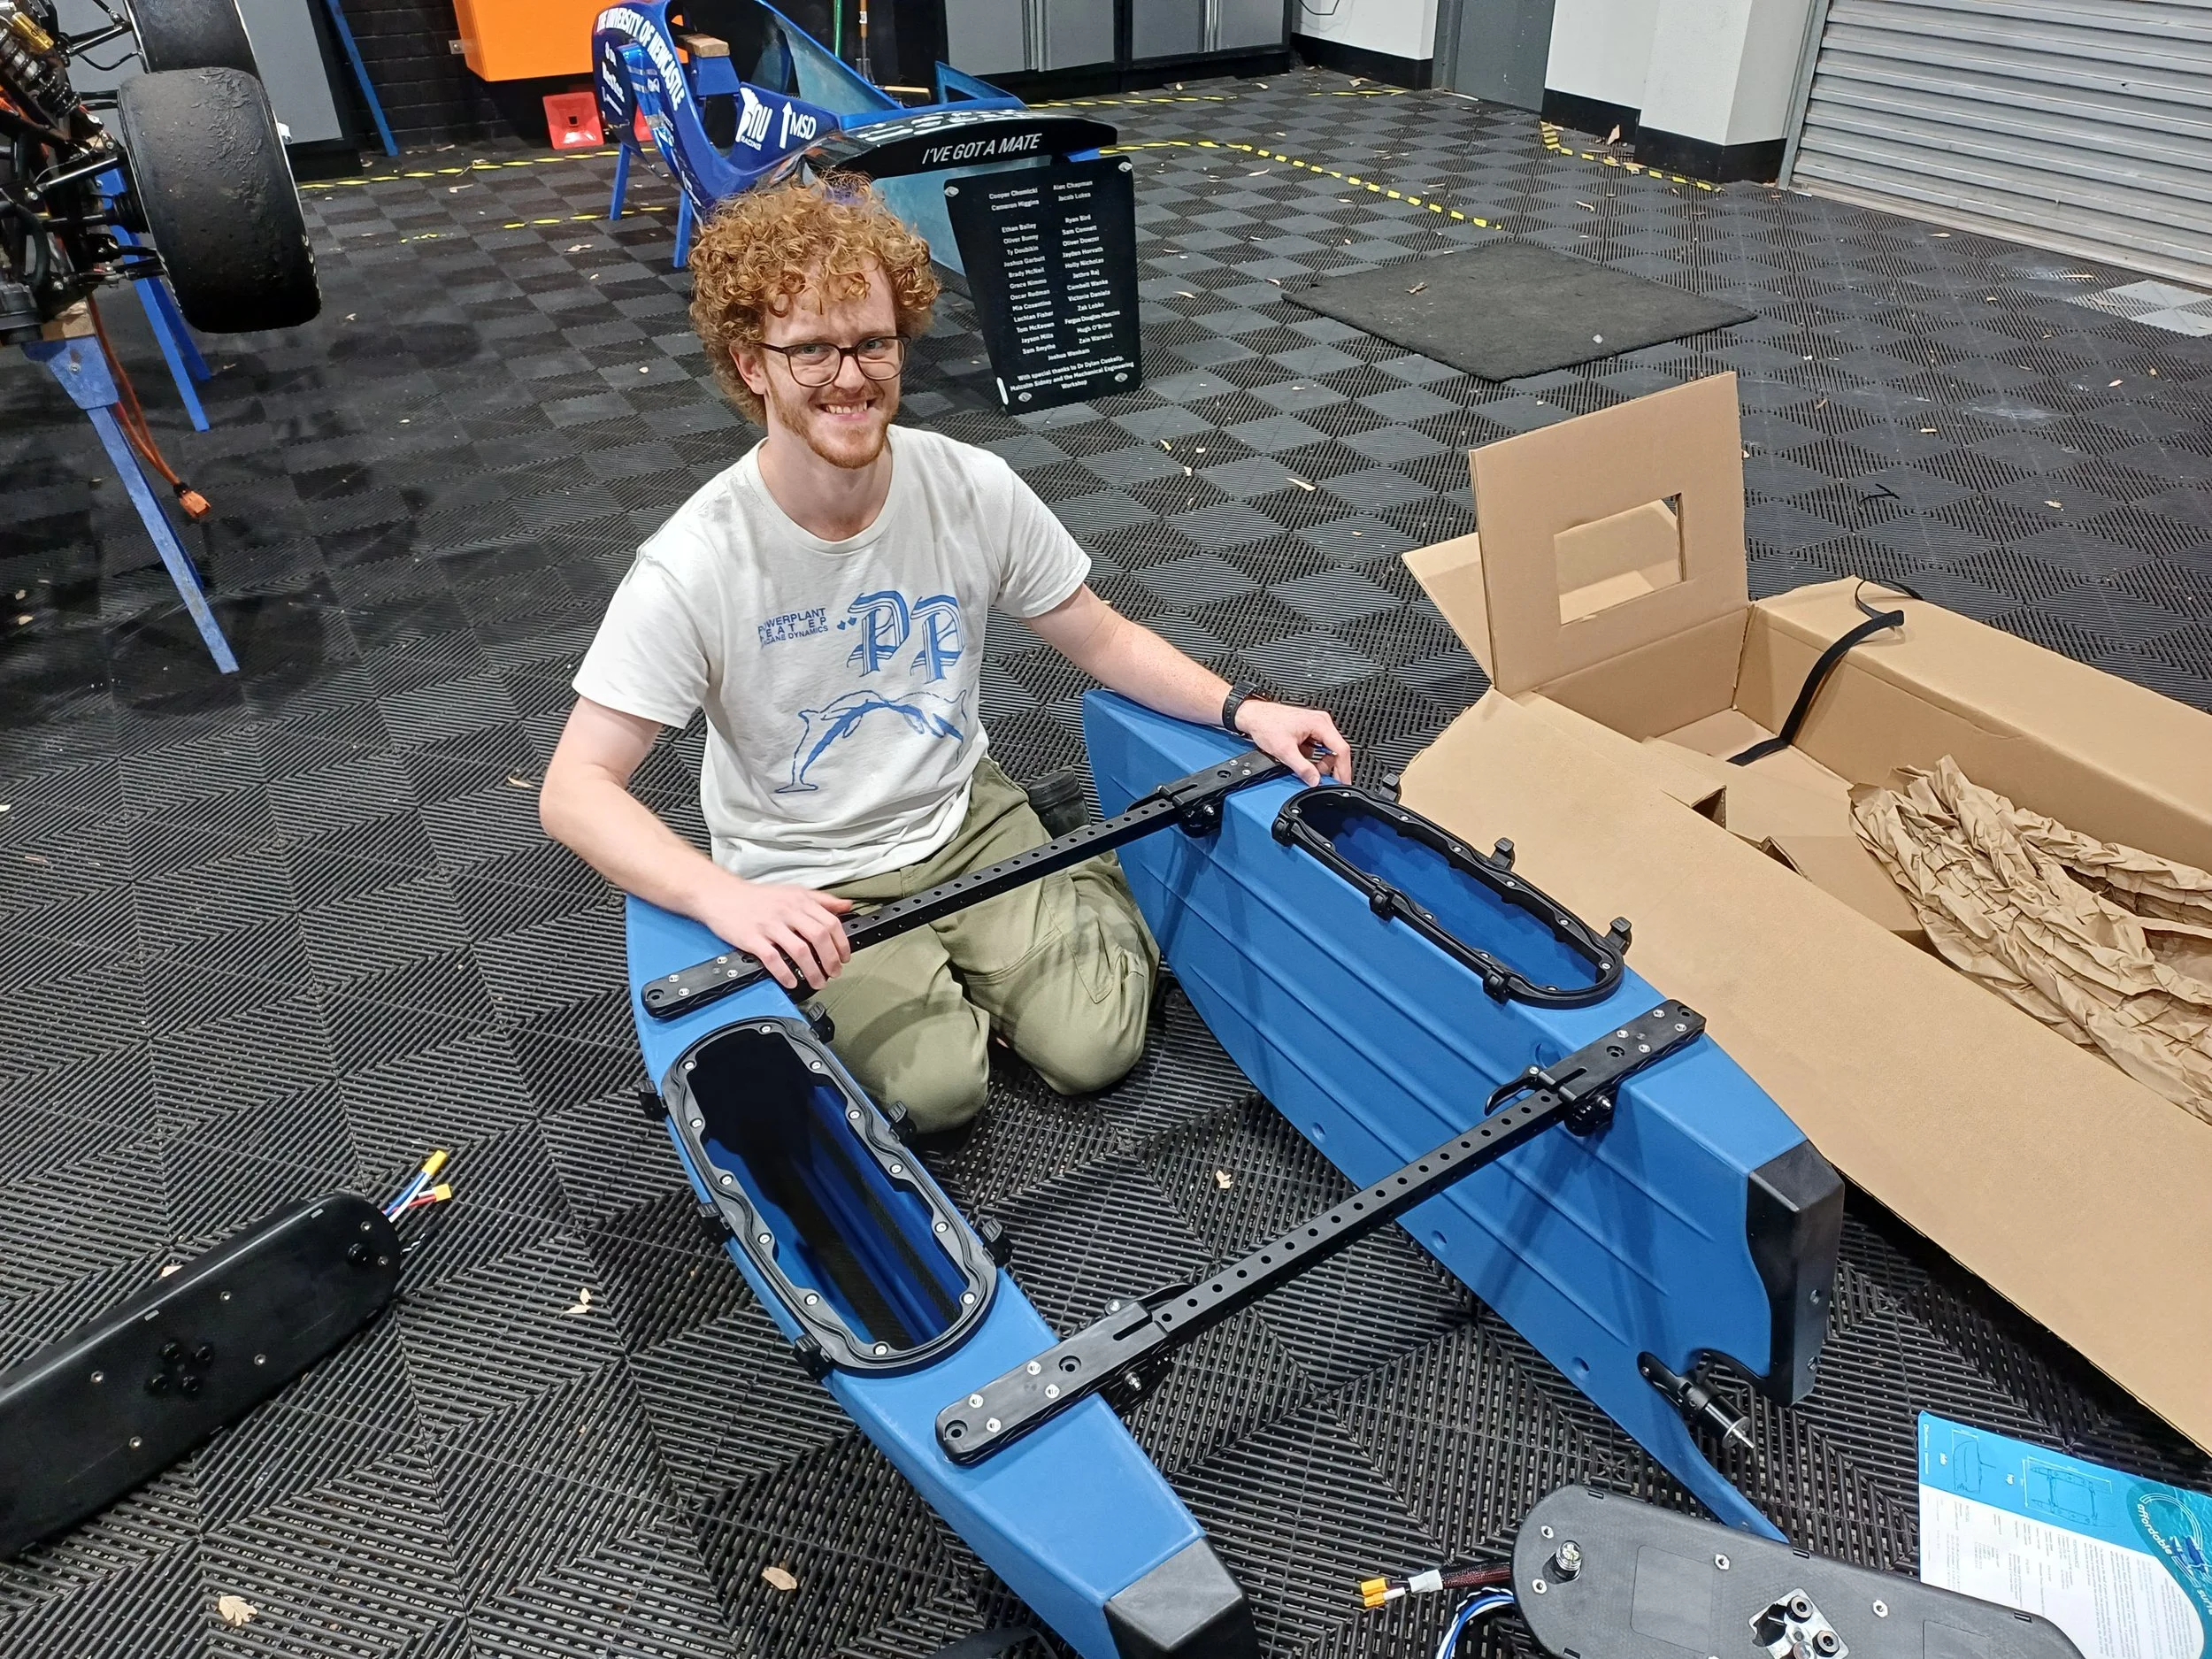
14th - 30th Jan 2026
Assembly of Atlas, our USV
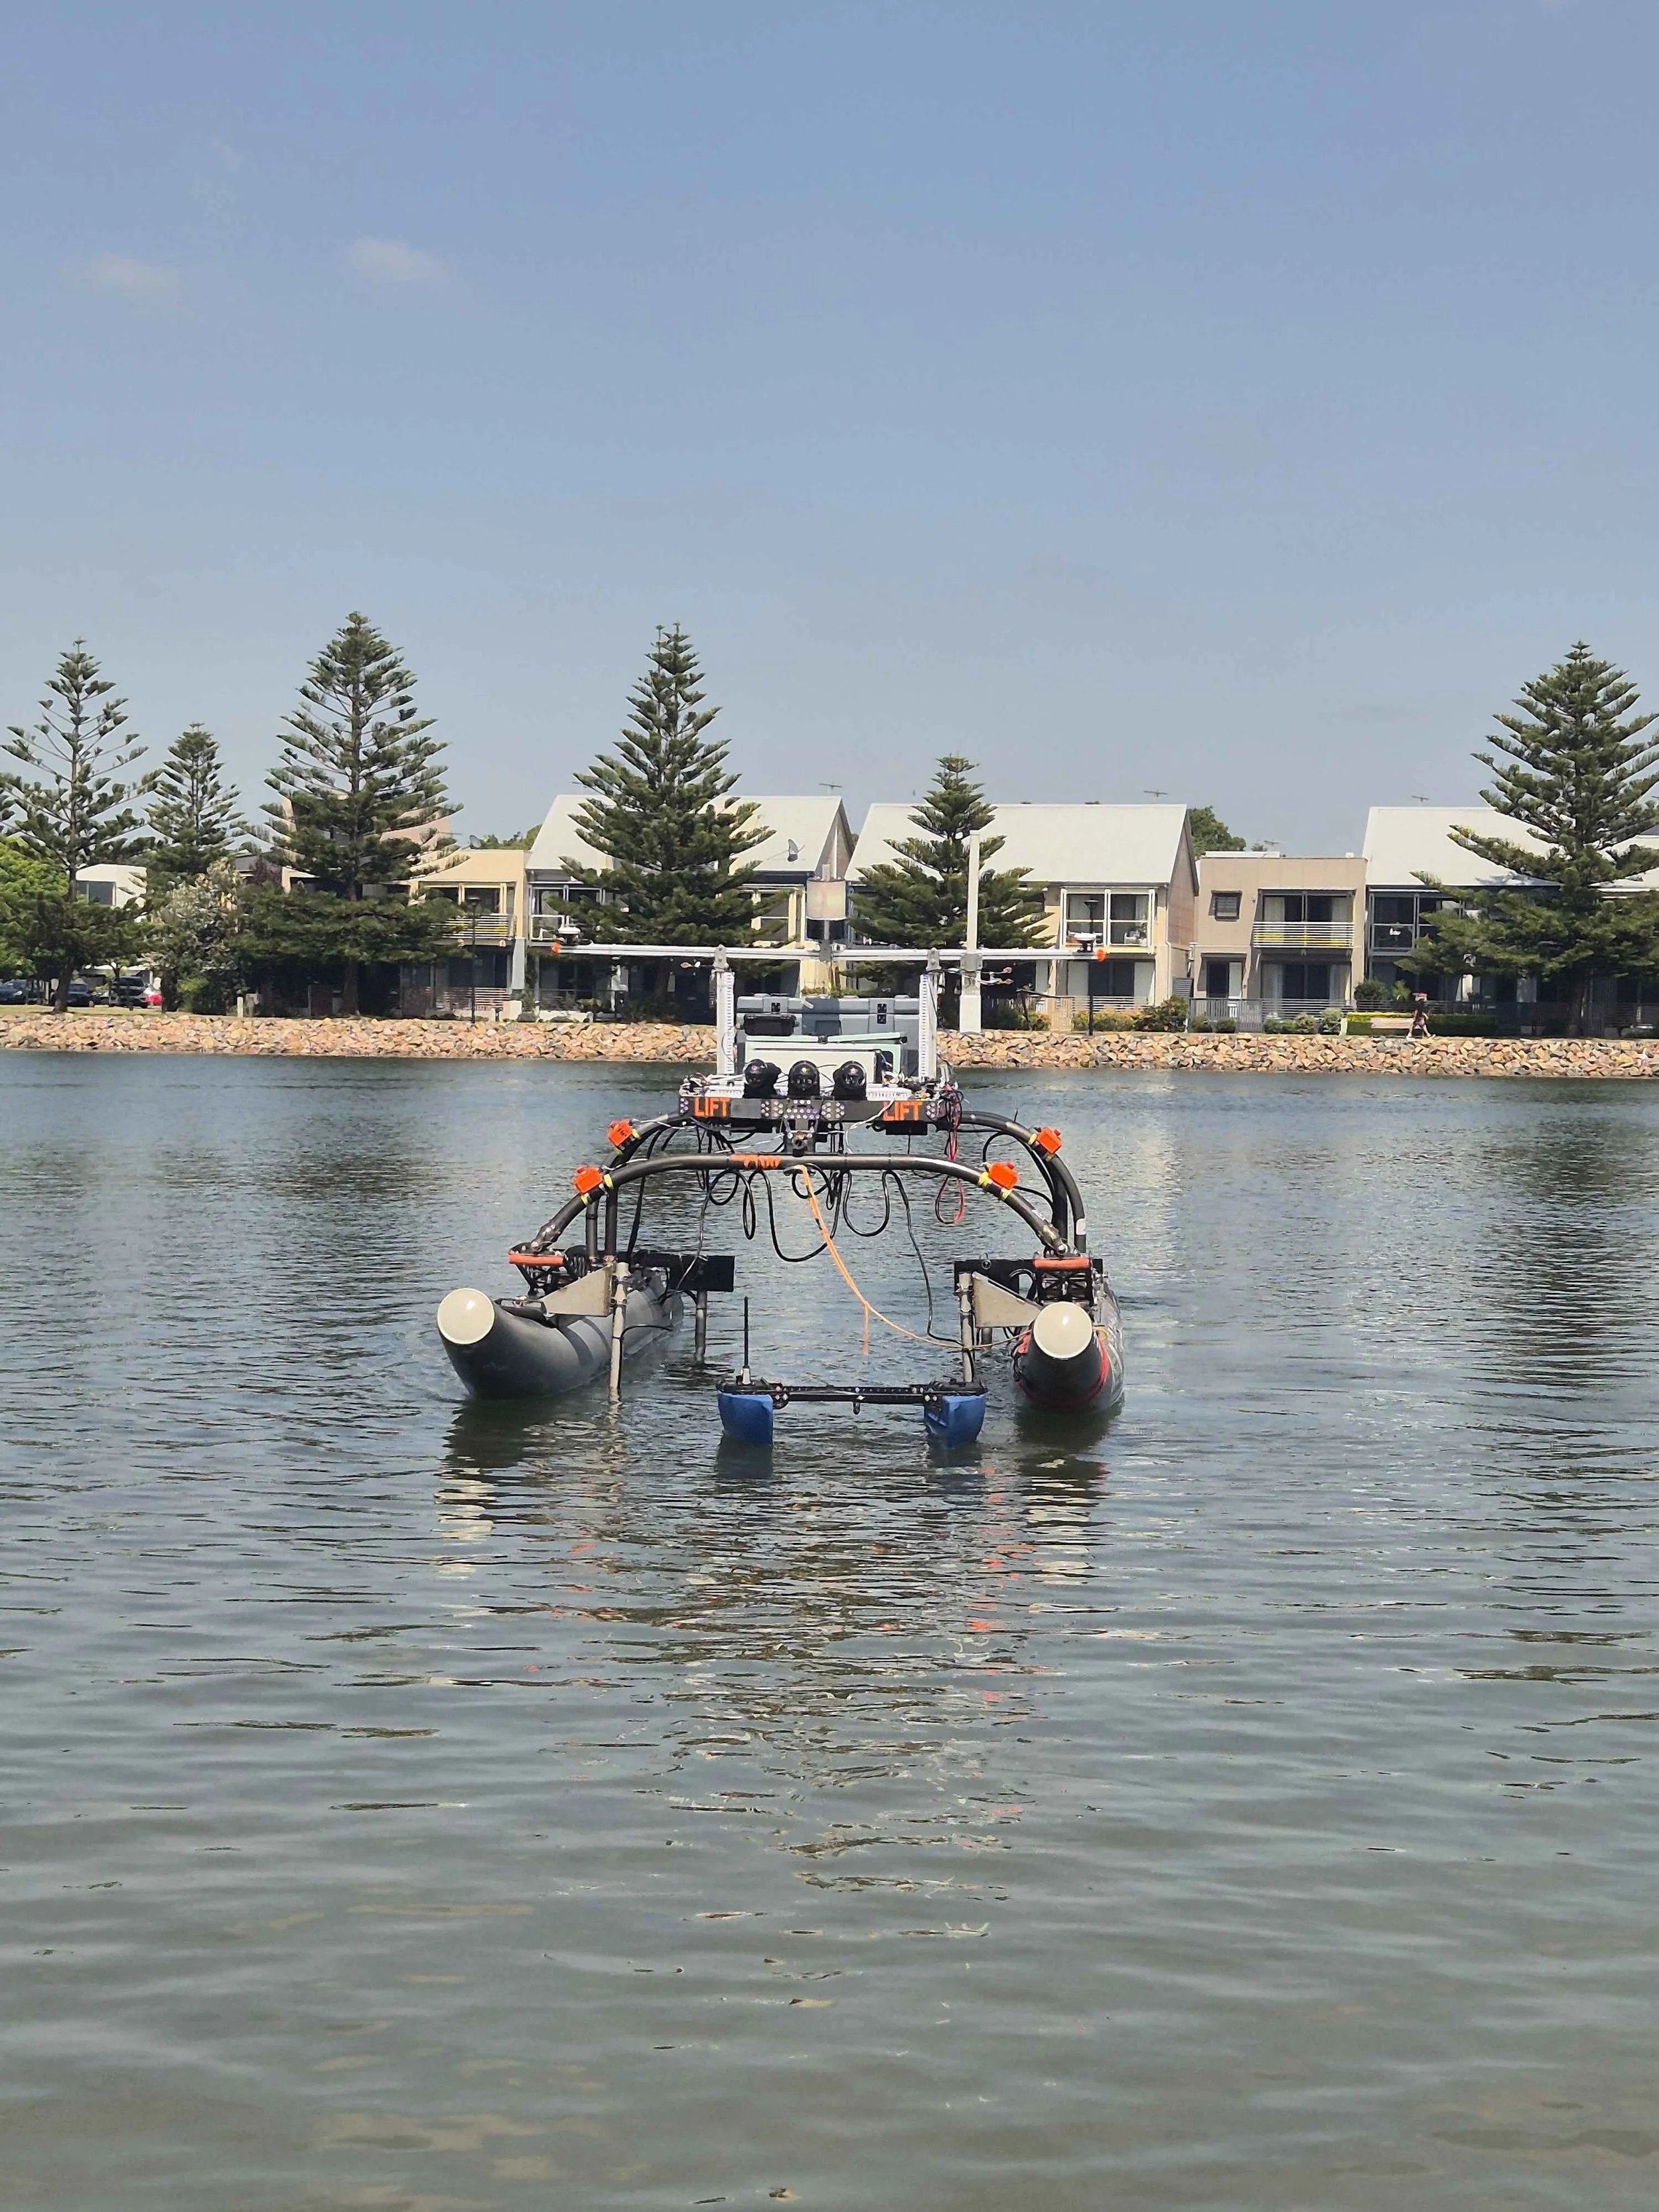
6th Feb 2026
First on the water test day with our old WAM-V and new BlueBoat platforms
19th Feb 2026
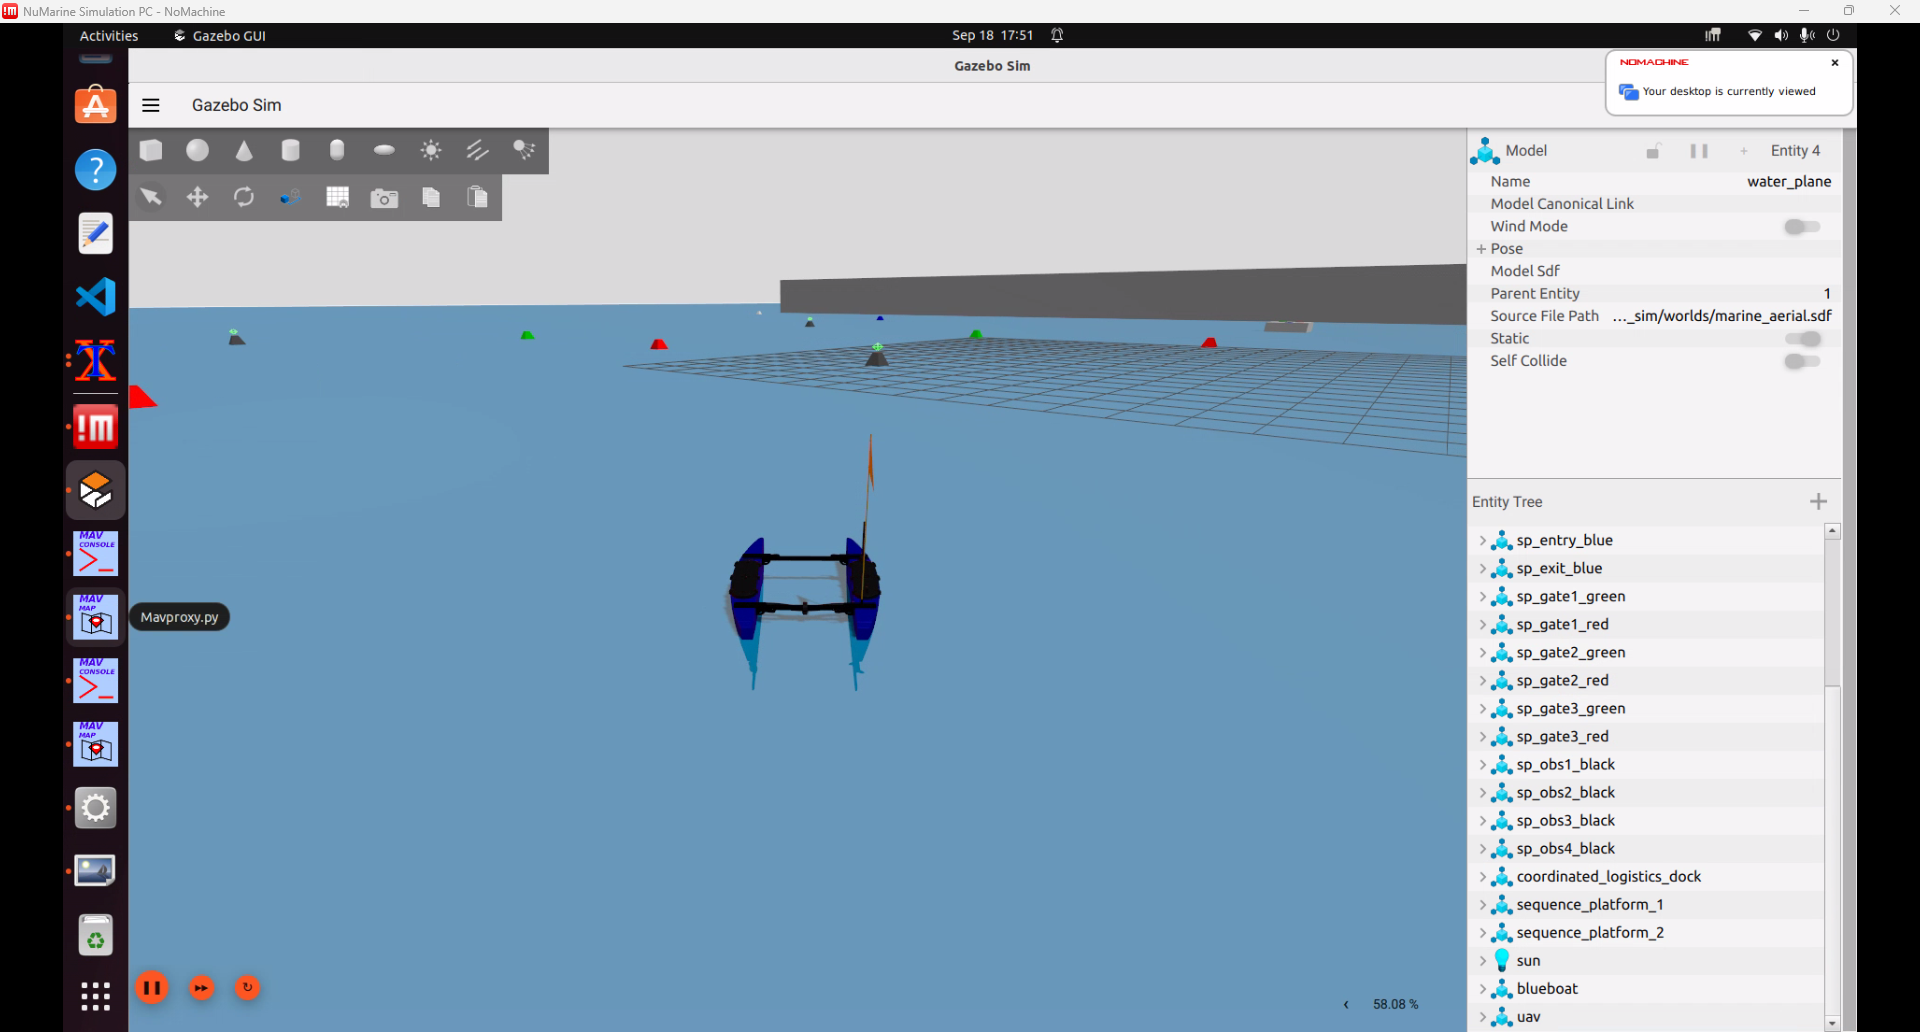
Integration of ardupilot and ROS software within the gazebo simulation of our USV, Atlas
24th Feb 2026
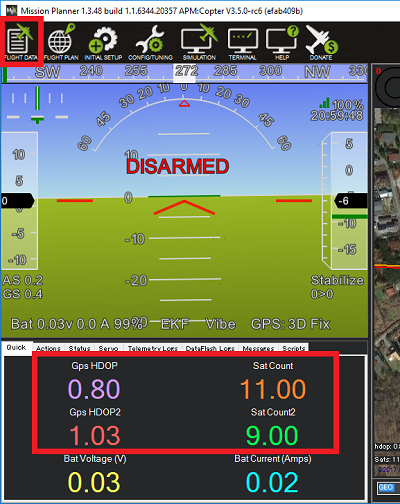
GPS data collected from Atlas using ROS and pymavlink
27th Feb 2026
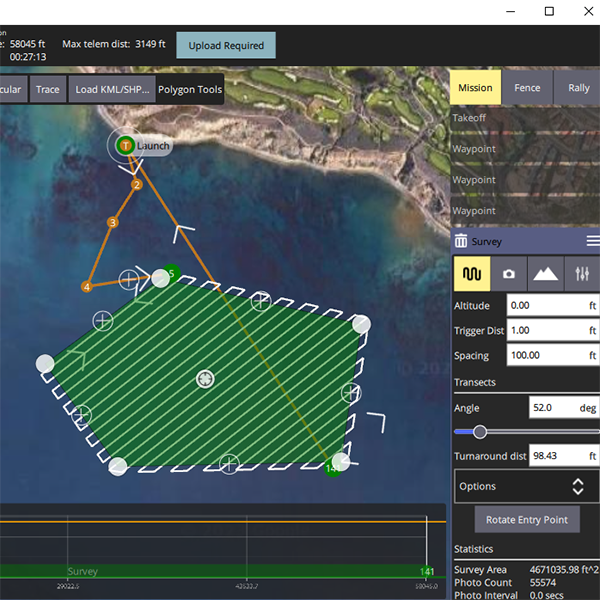
On the water test day with Atlas. Verified failure states. Conducted some initial PID tuning. Manually placed waypoints using Qground control and ROS
4th Mar 2026
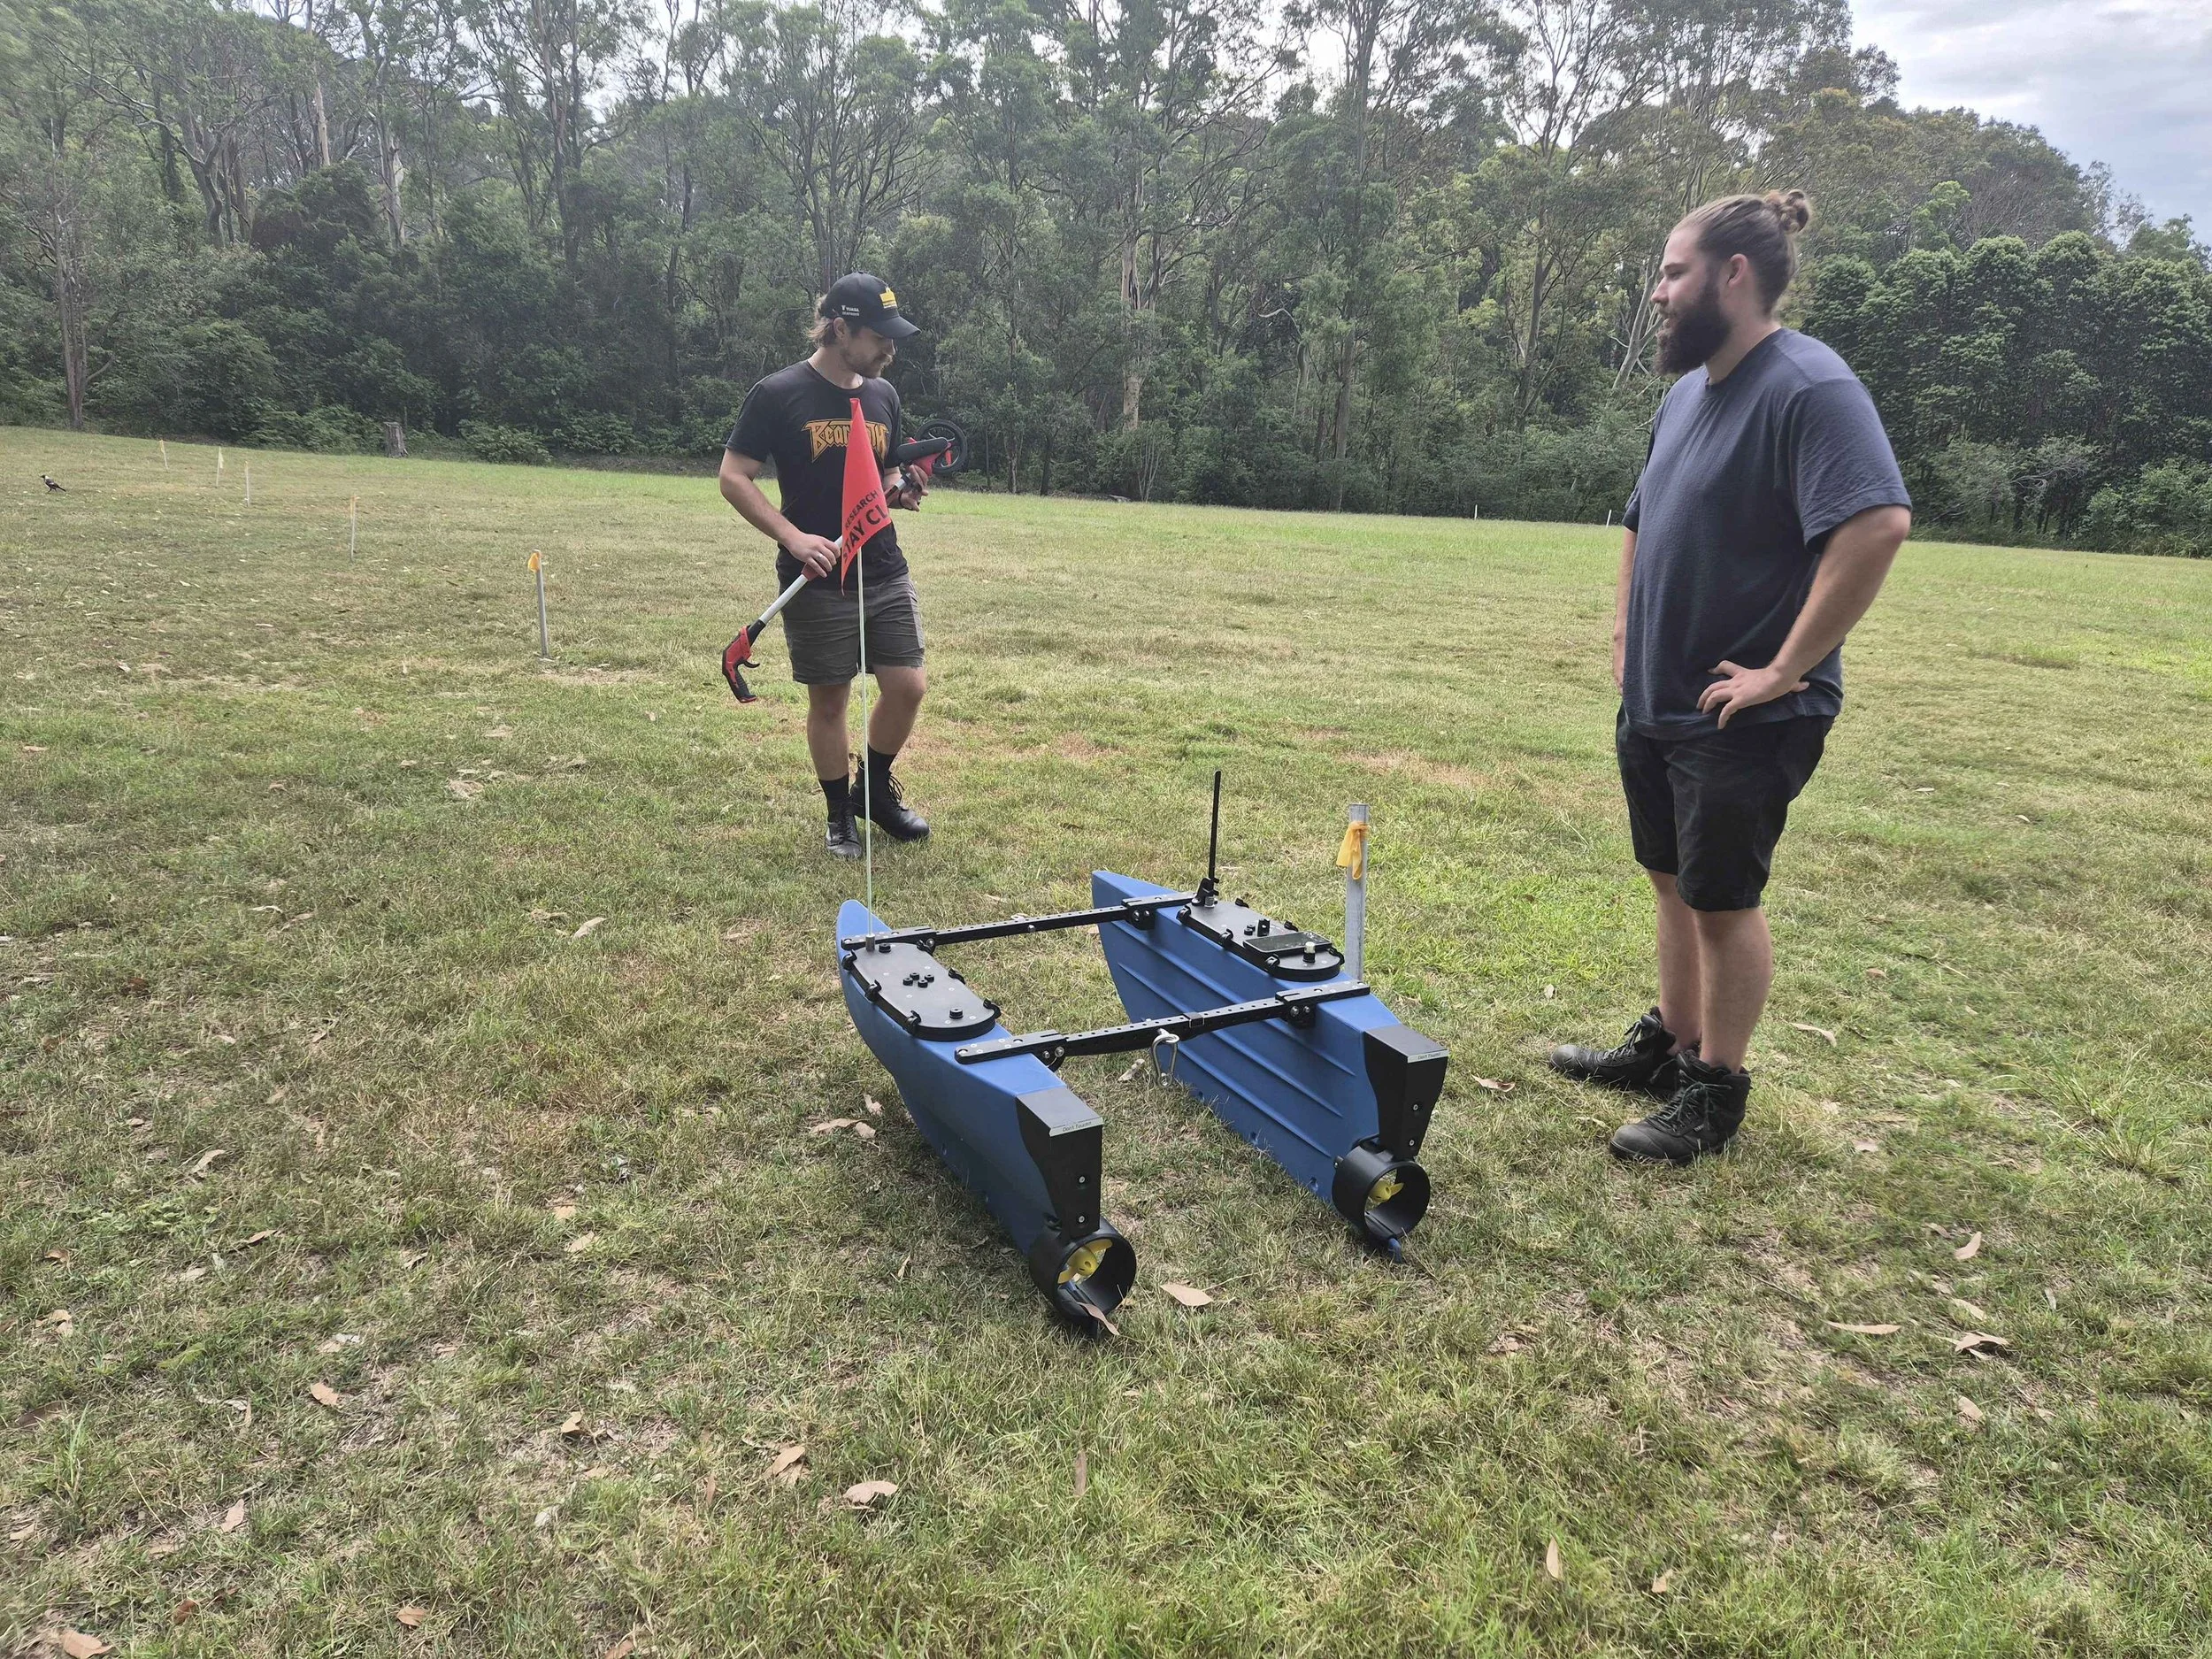
Testing Atlas’ inbuilt GPS accuracy on an oval near our workshop
5th Mar 2026
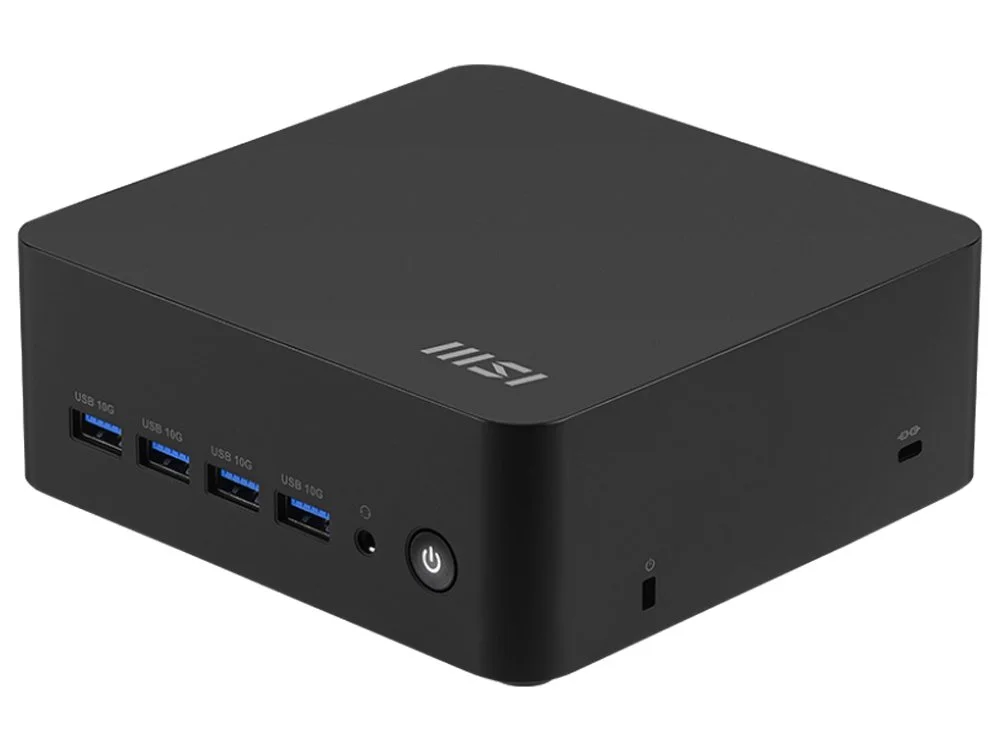
First time using a companion PC connected to Atlas for running the ROS network in our workshop. This allowed us to send commands to the flight controller using pymavlink by remoting into the companion PC
13th Mar 2026
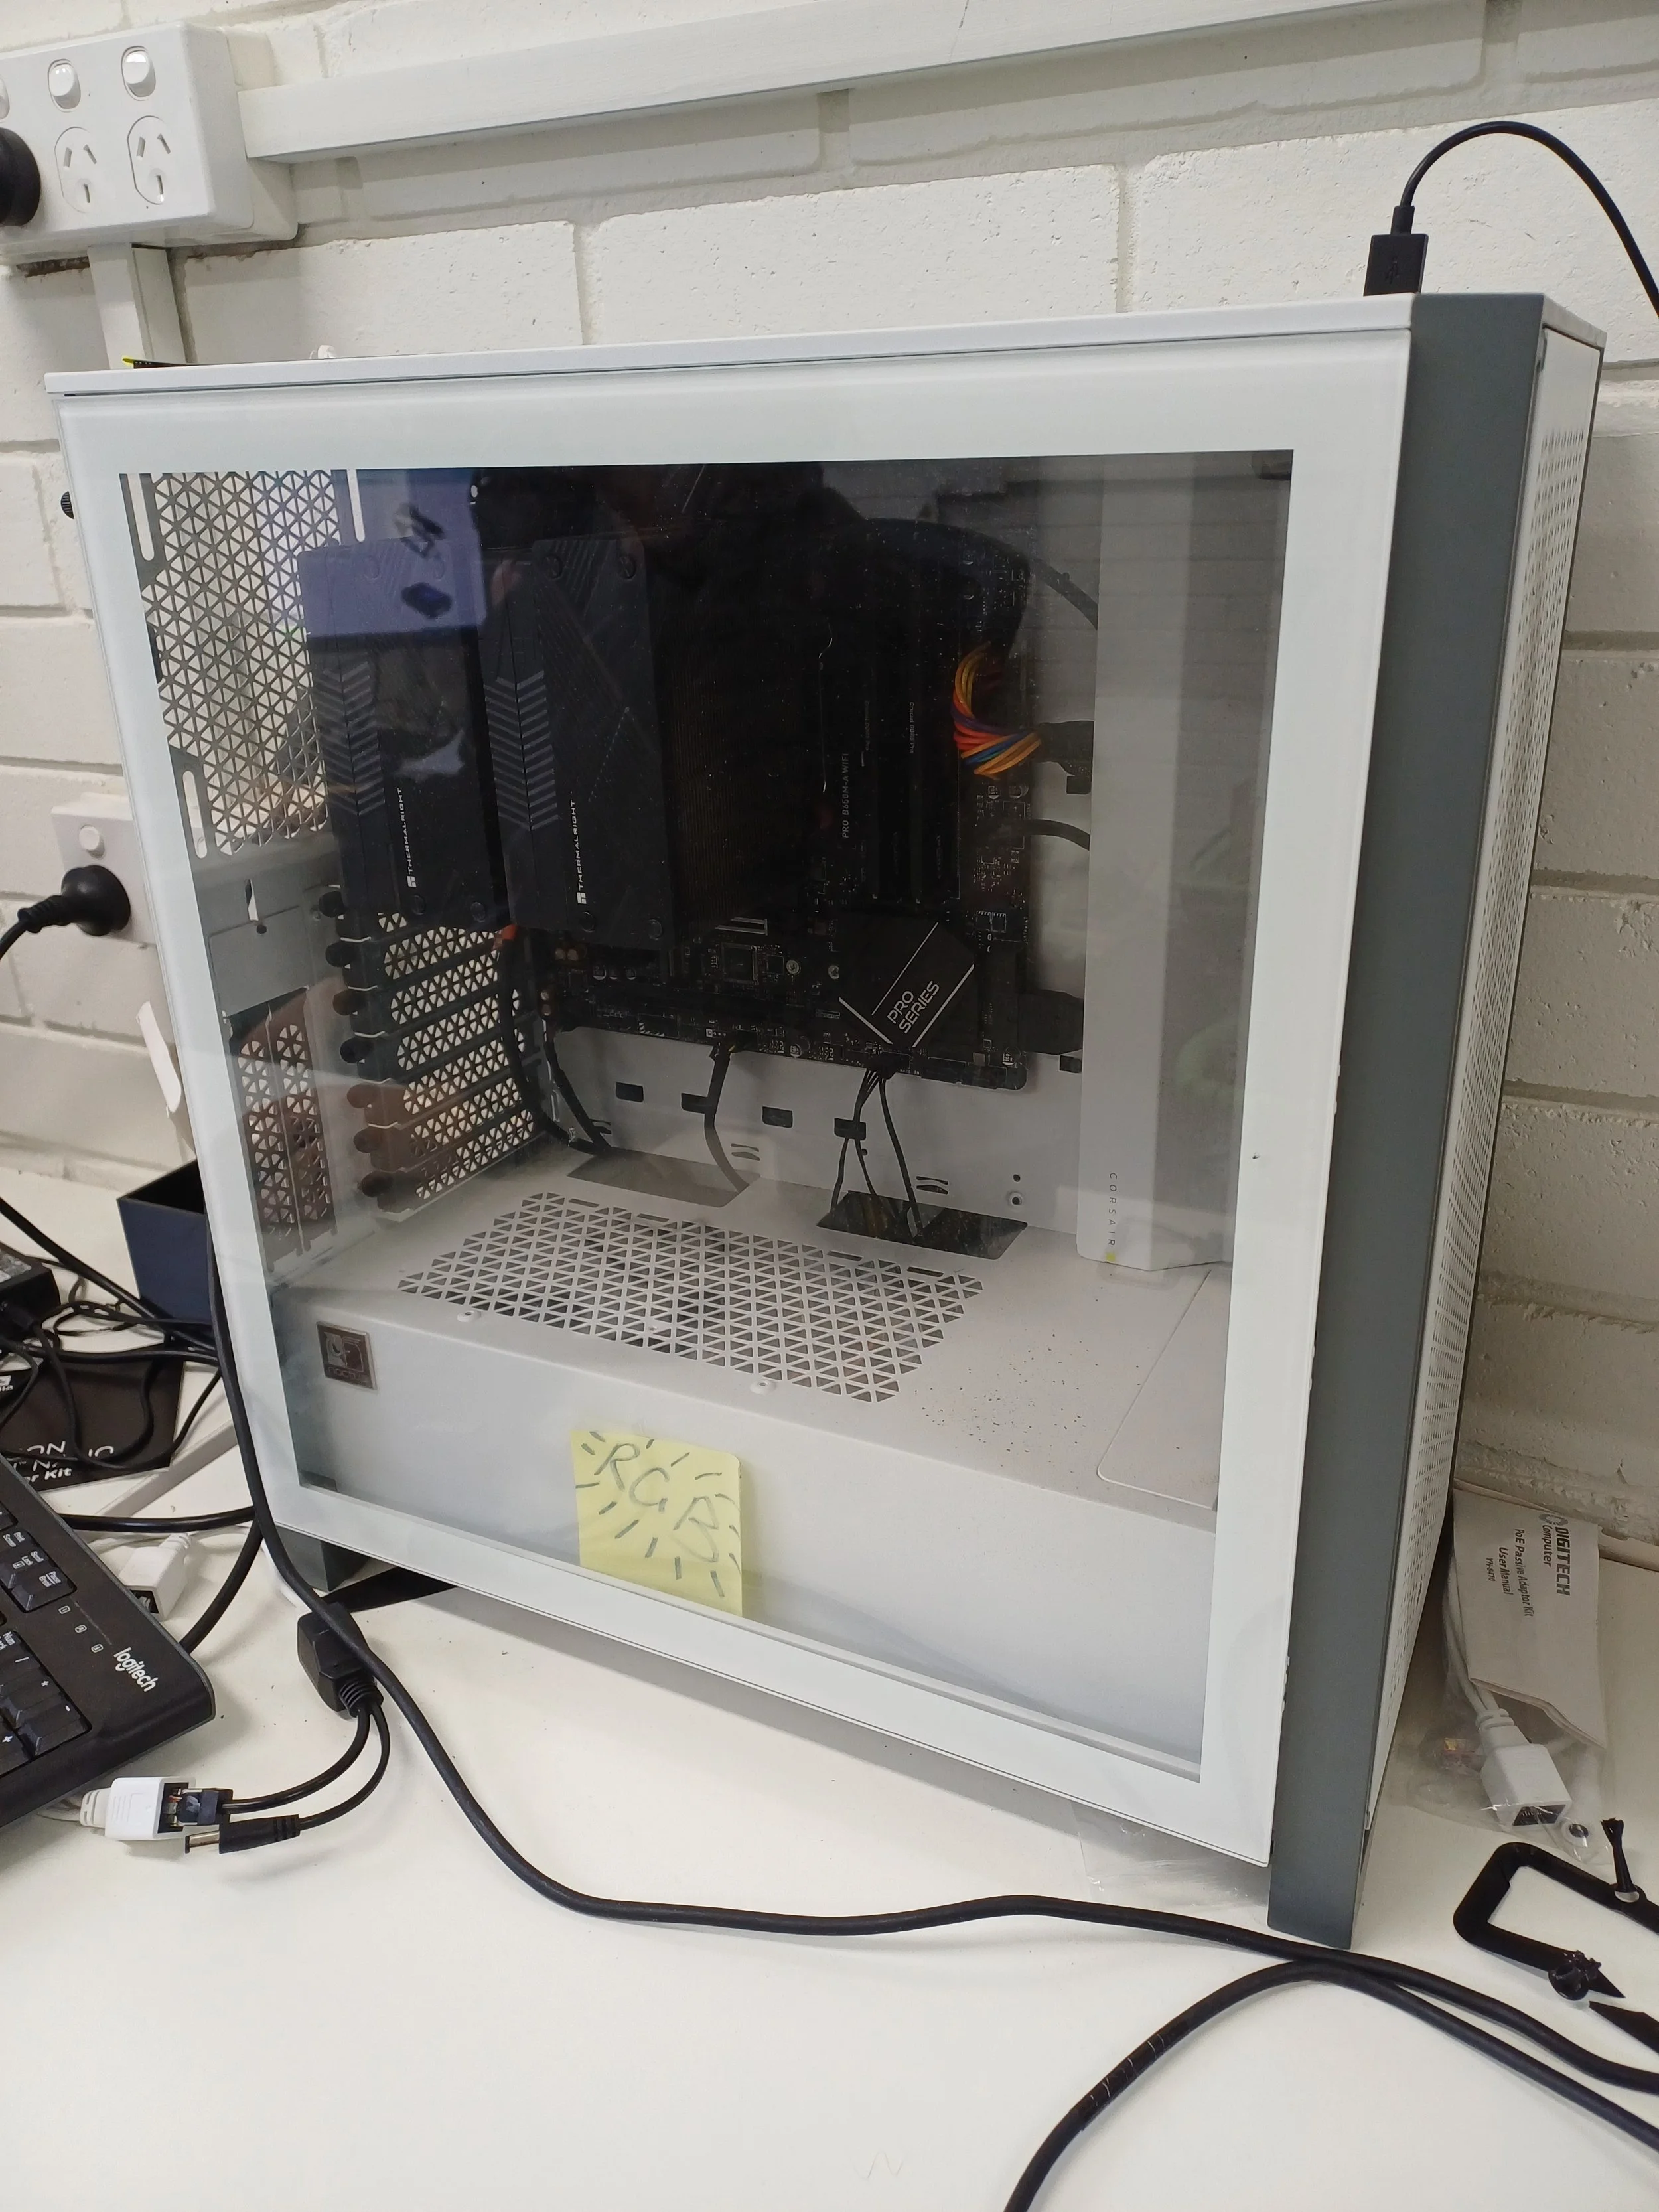
Installation of a custom simulation PC in our workshop for running gazebo simulations of our platforms
18th Mar 2026
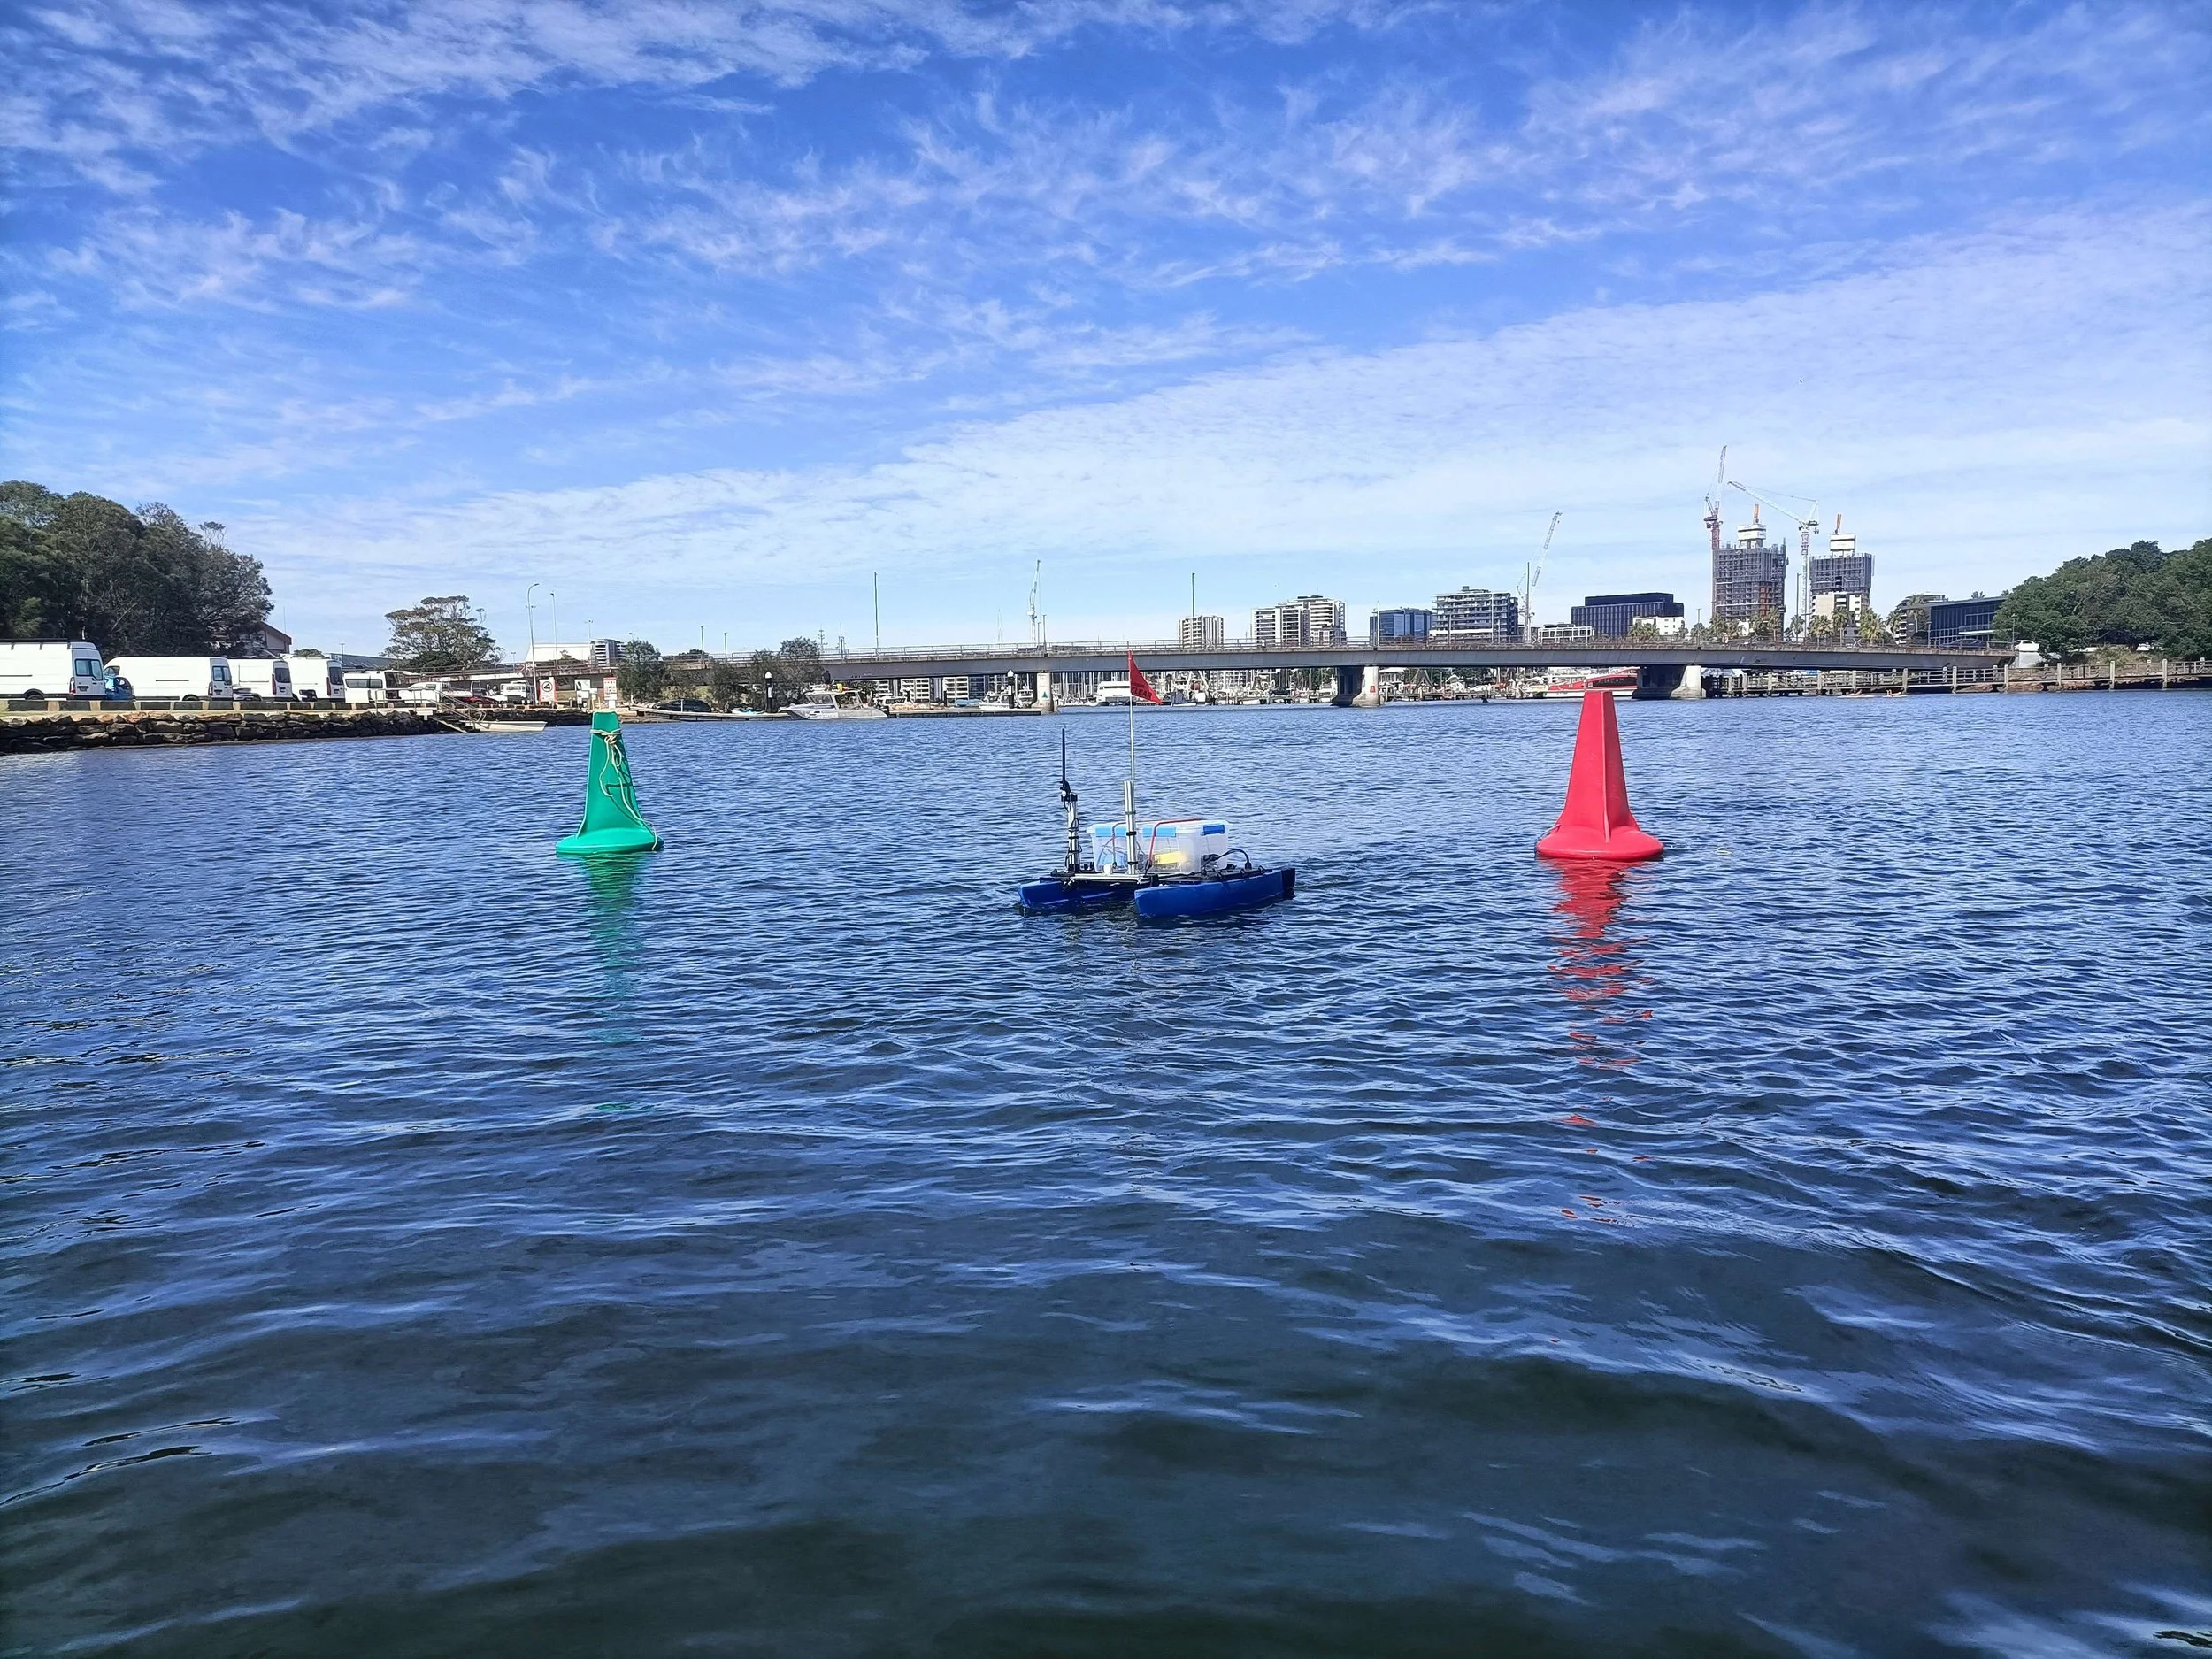
Installation of the first iteration of Atlas’ smart box which houses all of the computers responsible for autonomous capabilities
26th Mar 2026
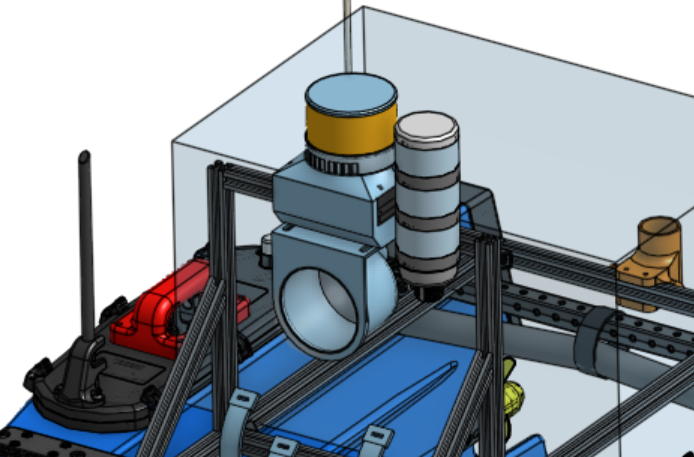
Mounted LIDAR to Atlas
Testing our spatial dual GPS
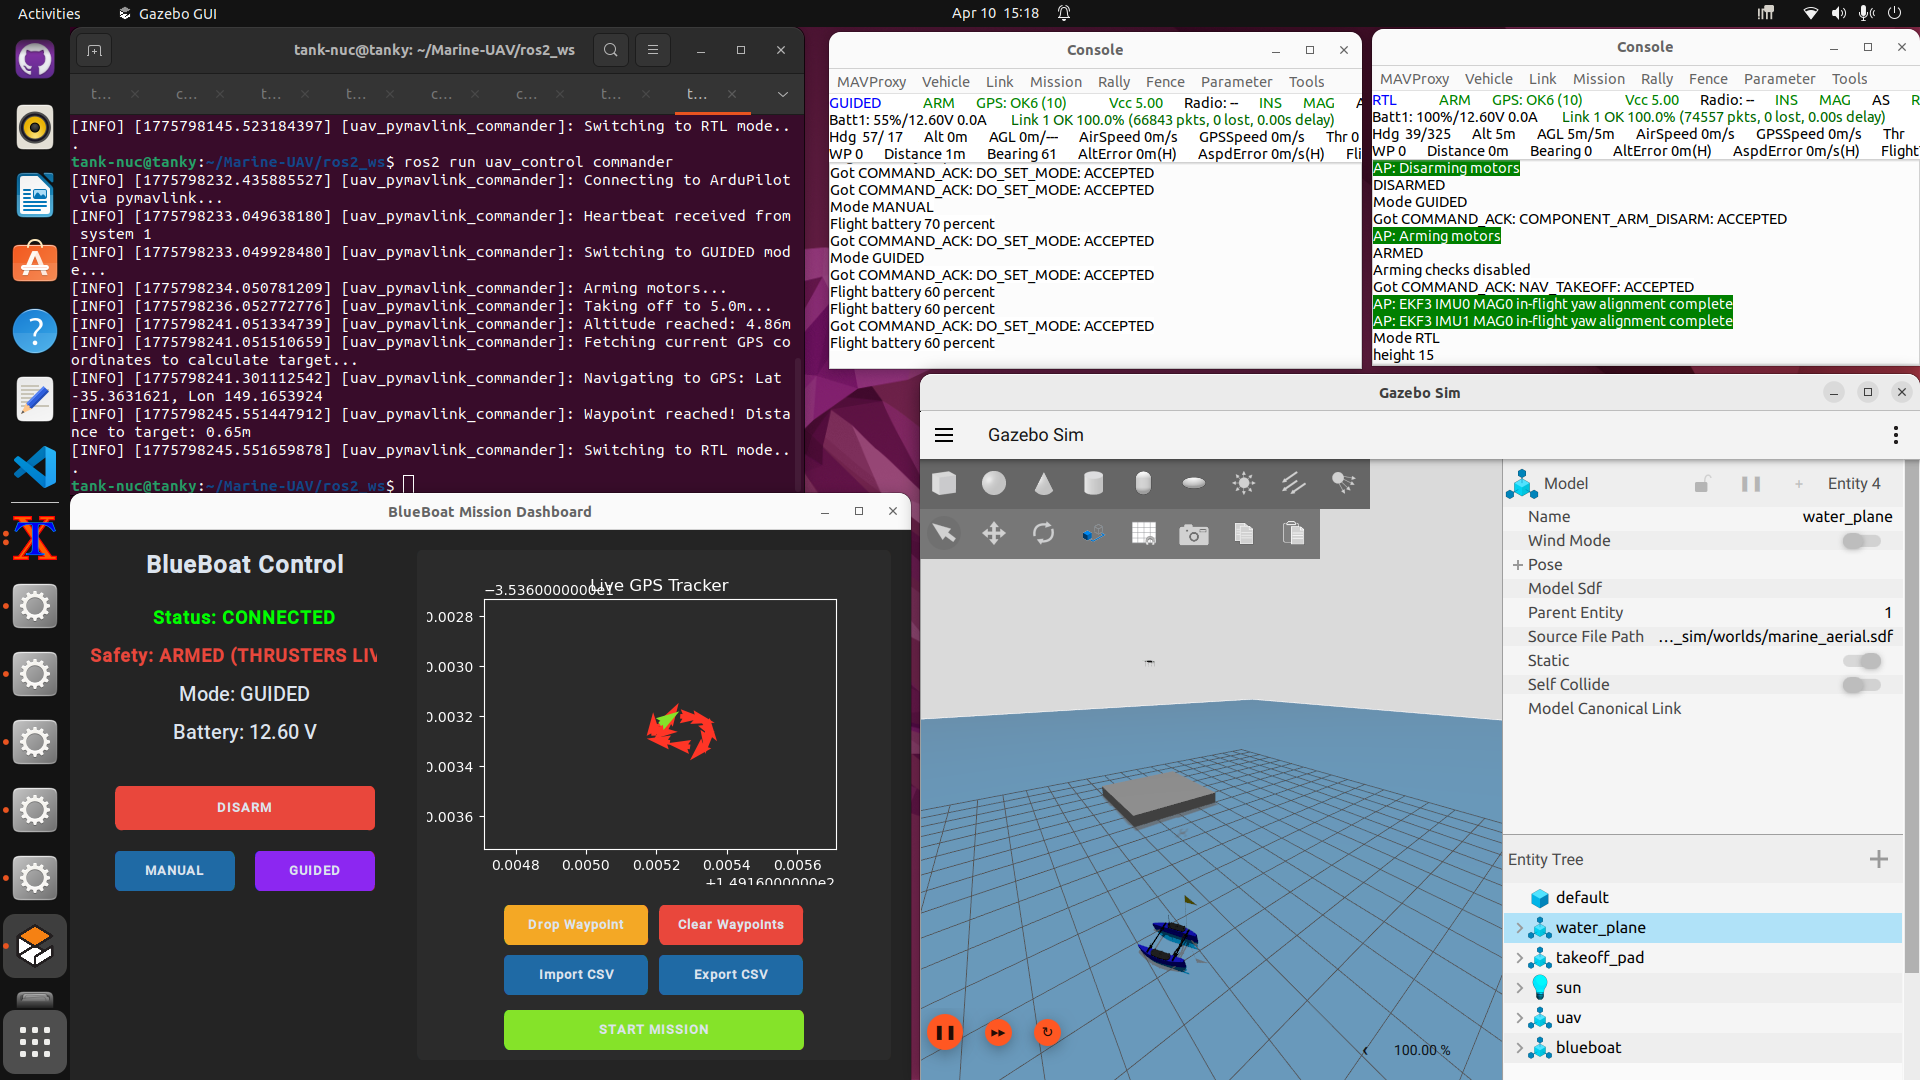
First multi-vehicle simulation run in gazebo on our simulation PC
27th Mar 2026
On the water test day where we deployed a GUI for use by our on-shore command centre to lace waypoints and monitor Atlas’ position/path
17th Apr 2026
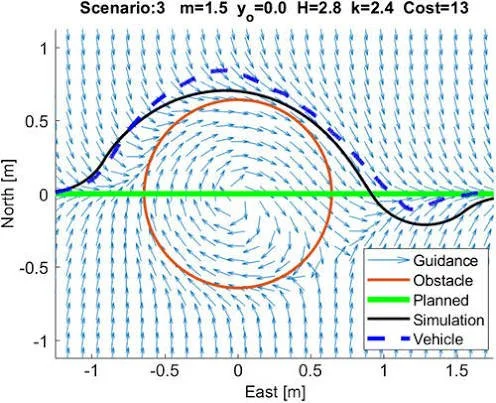
On the water testing of failure states and mode switching using ELRS remote
First test runs of basic waypoint and obstacle avoidance scripts
22nd May 2026
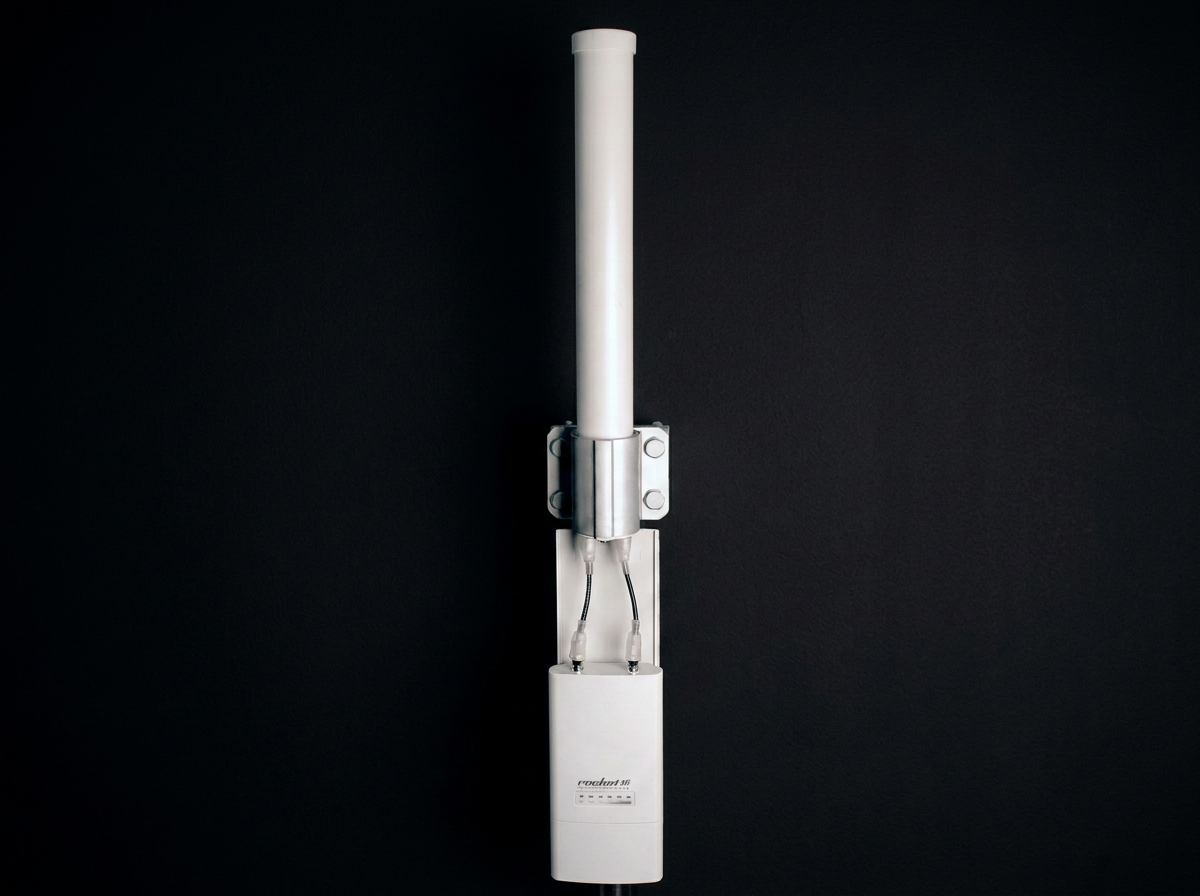
Testing of Ubiquiti WIFI antennas on the water
29th May 2026
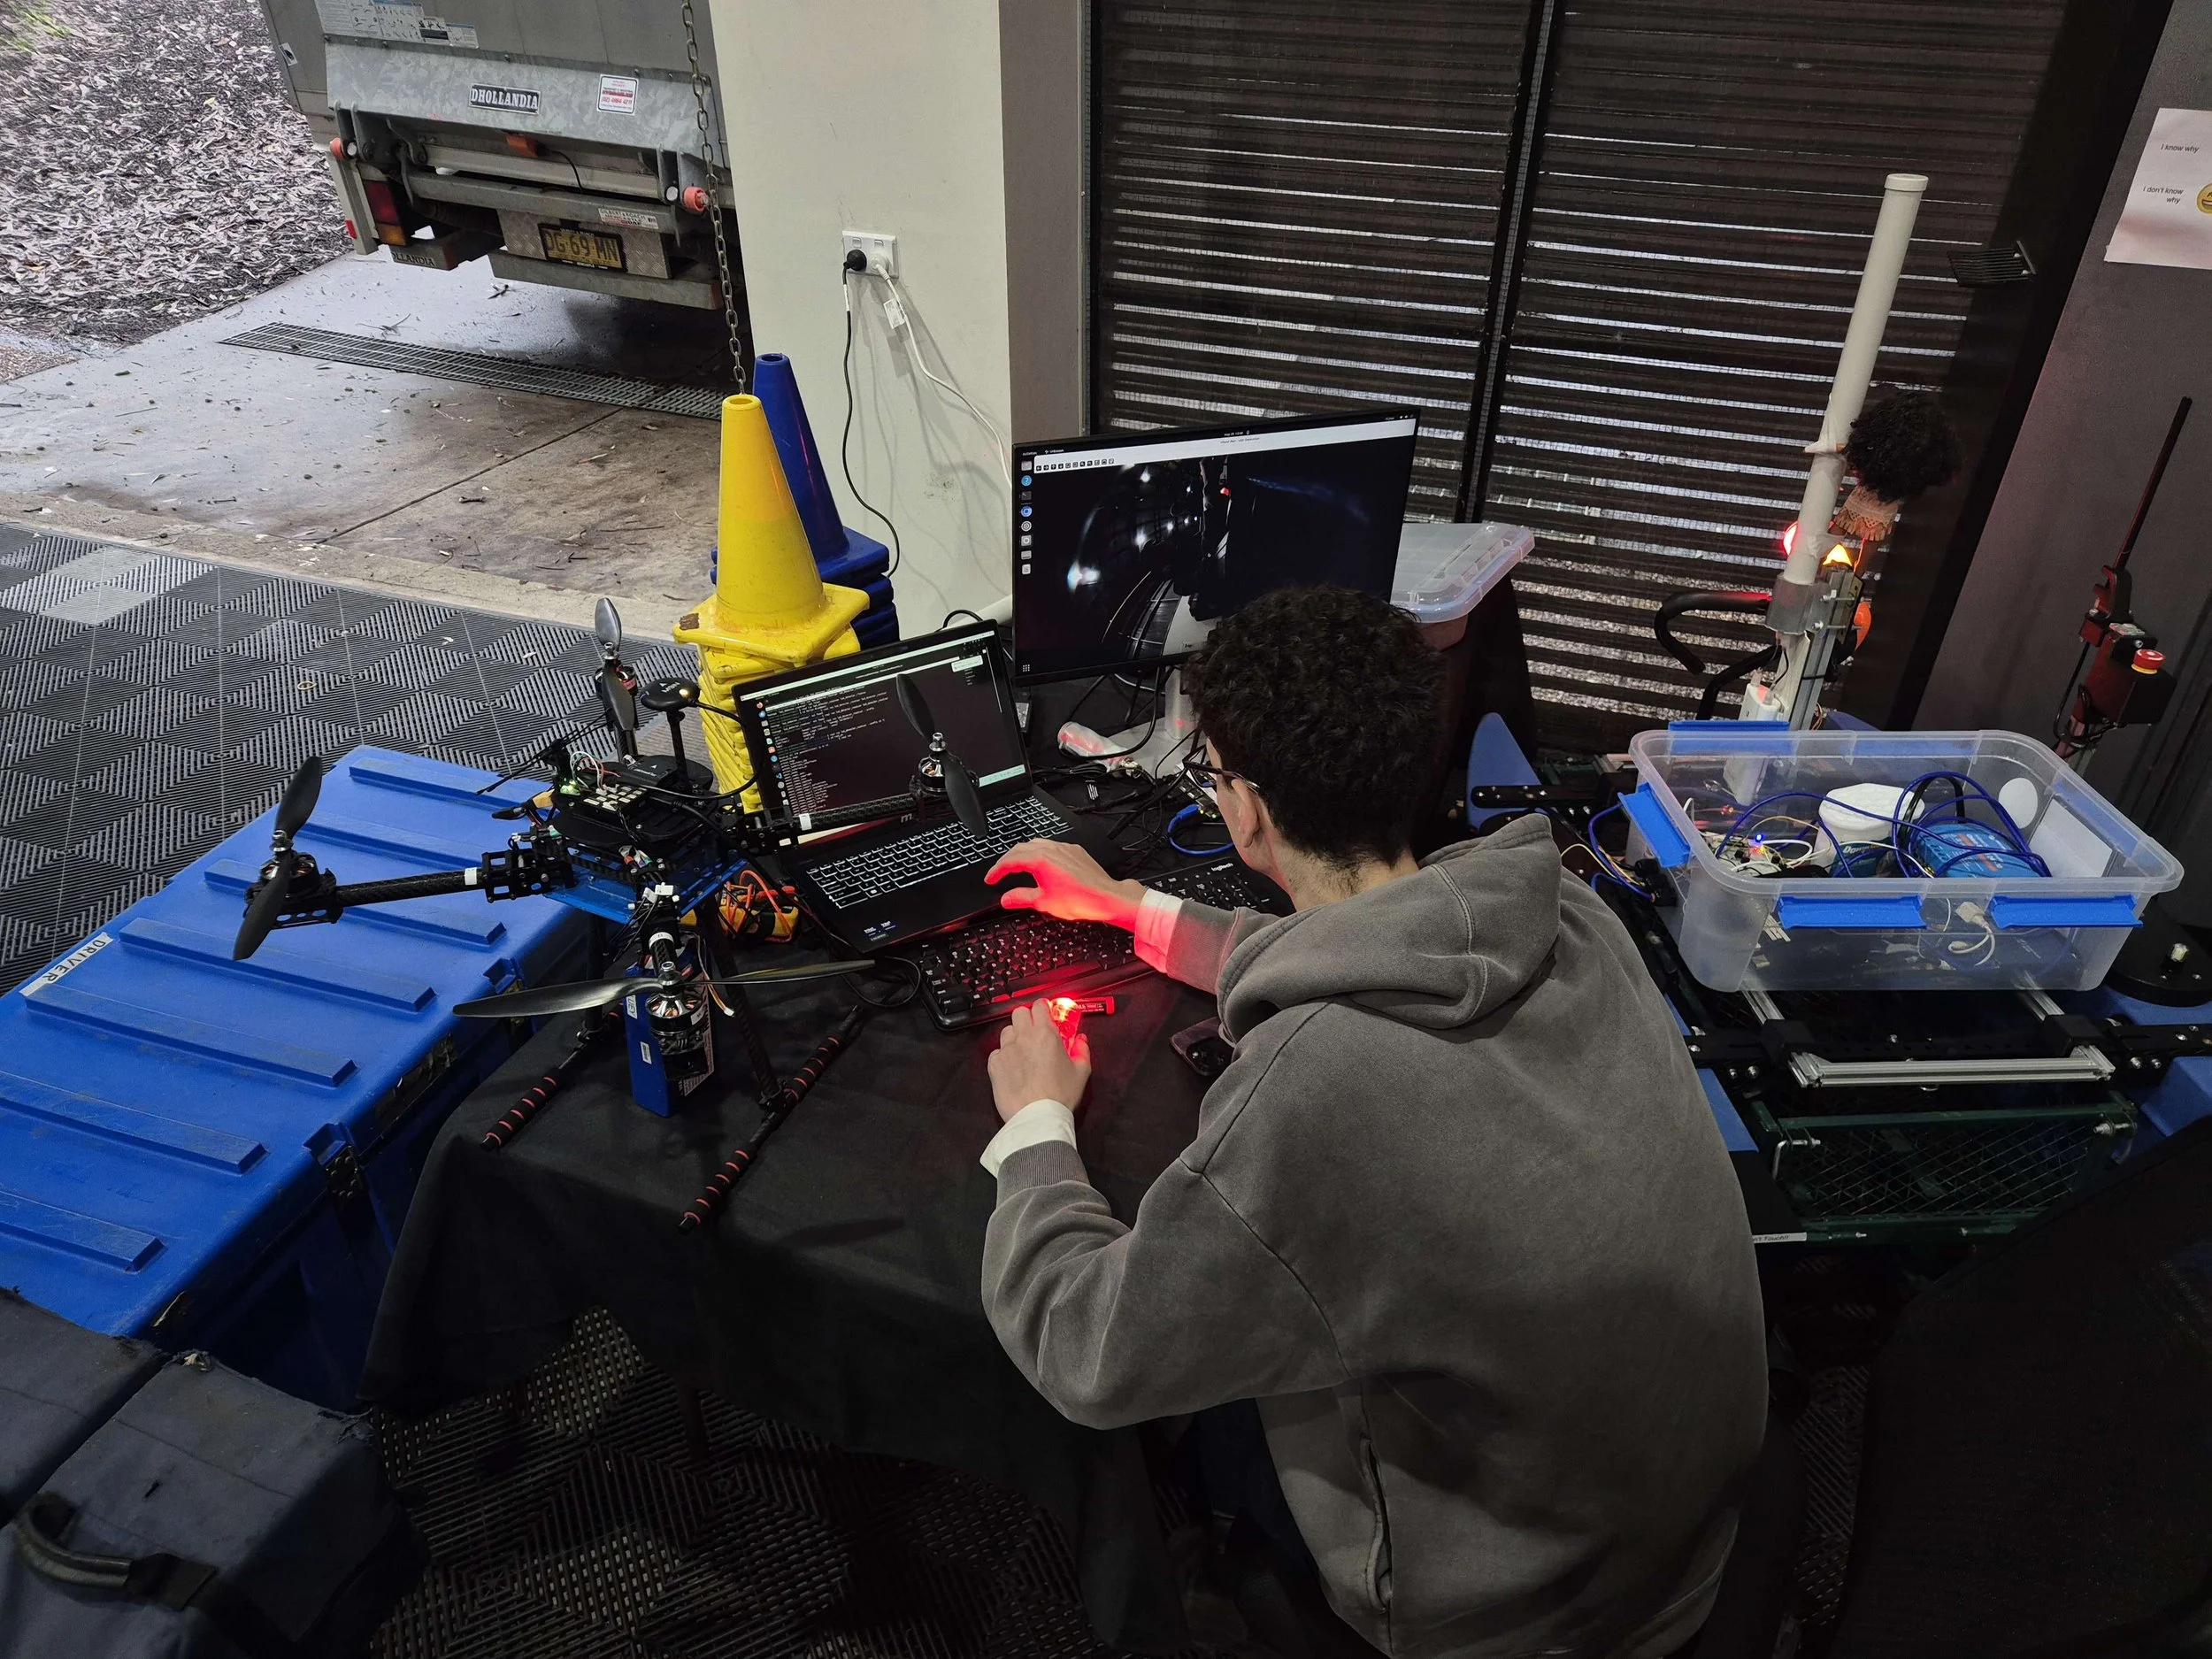
Testing communications between our UAV, Artemis, and Atlas’ companion PC using Ubiquiti WIFI antennas
3rd Jun 2026
First iteration of robo-command node reads telemetry data from Atlas during on the water testing
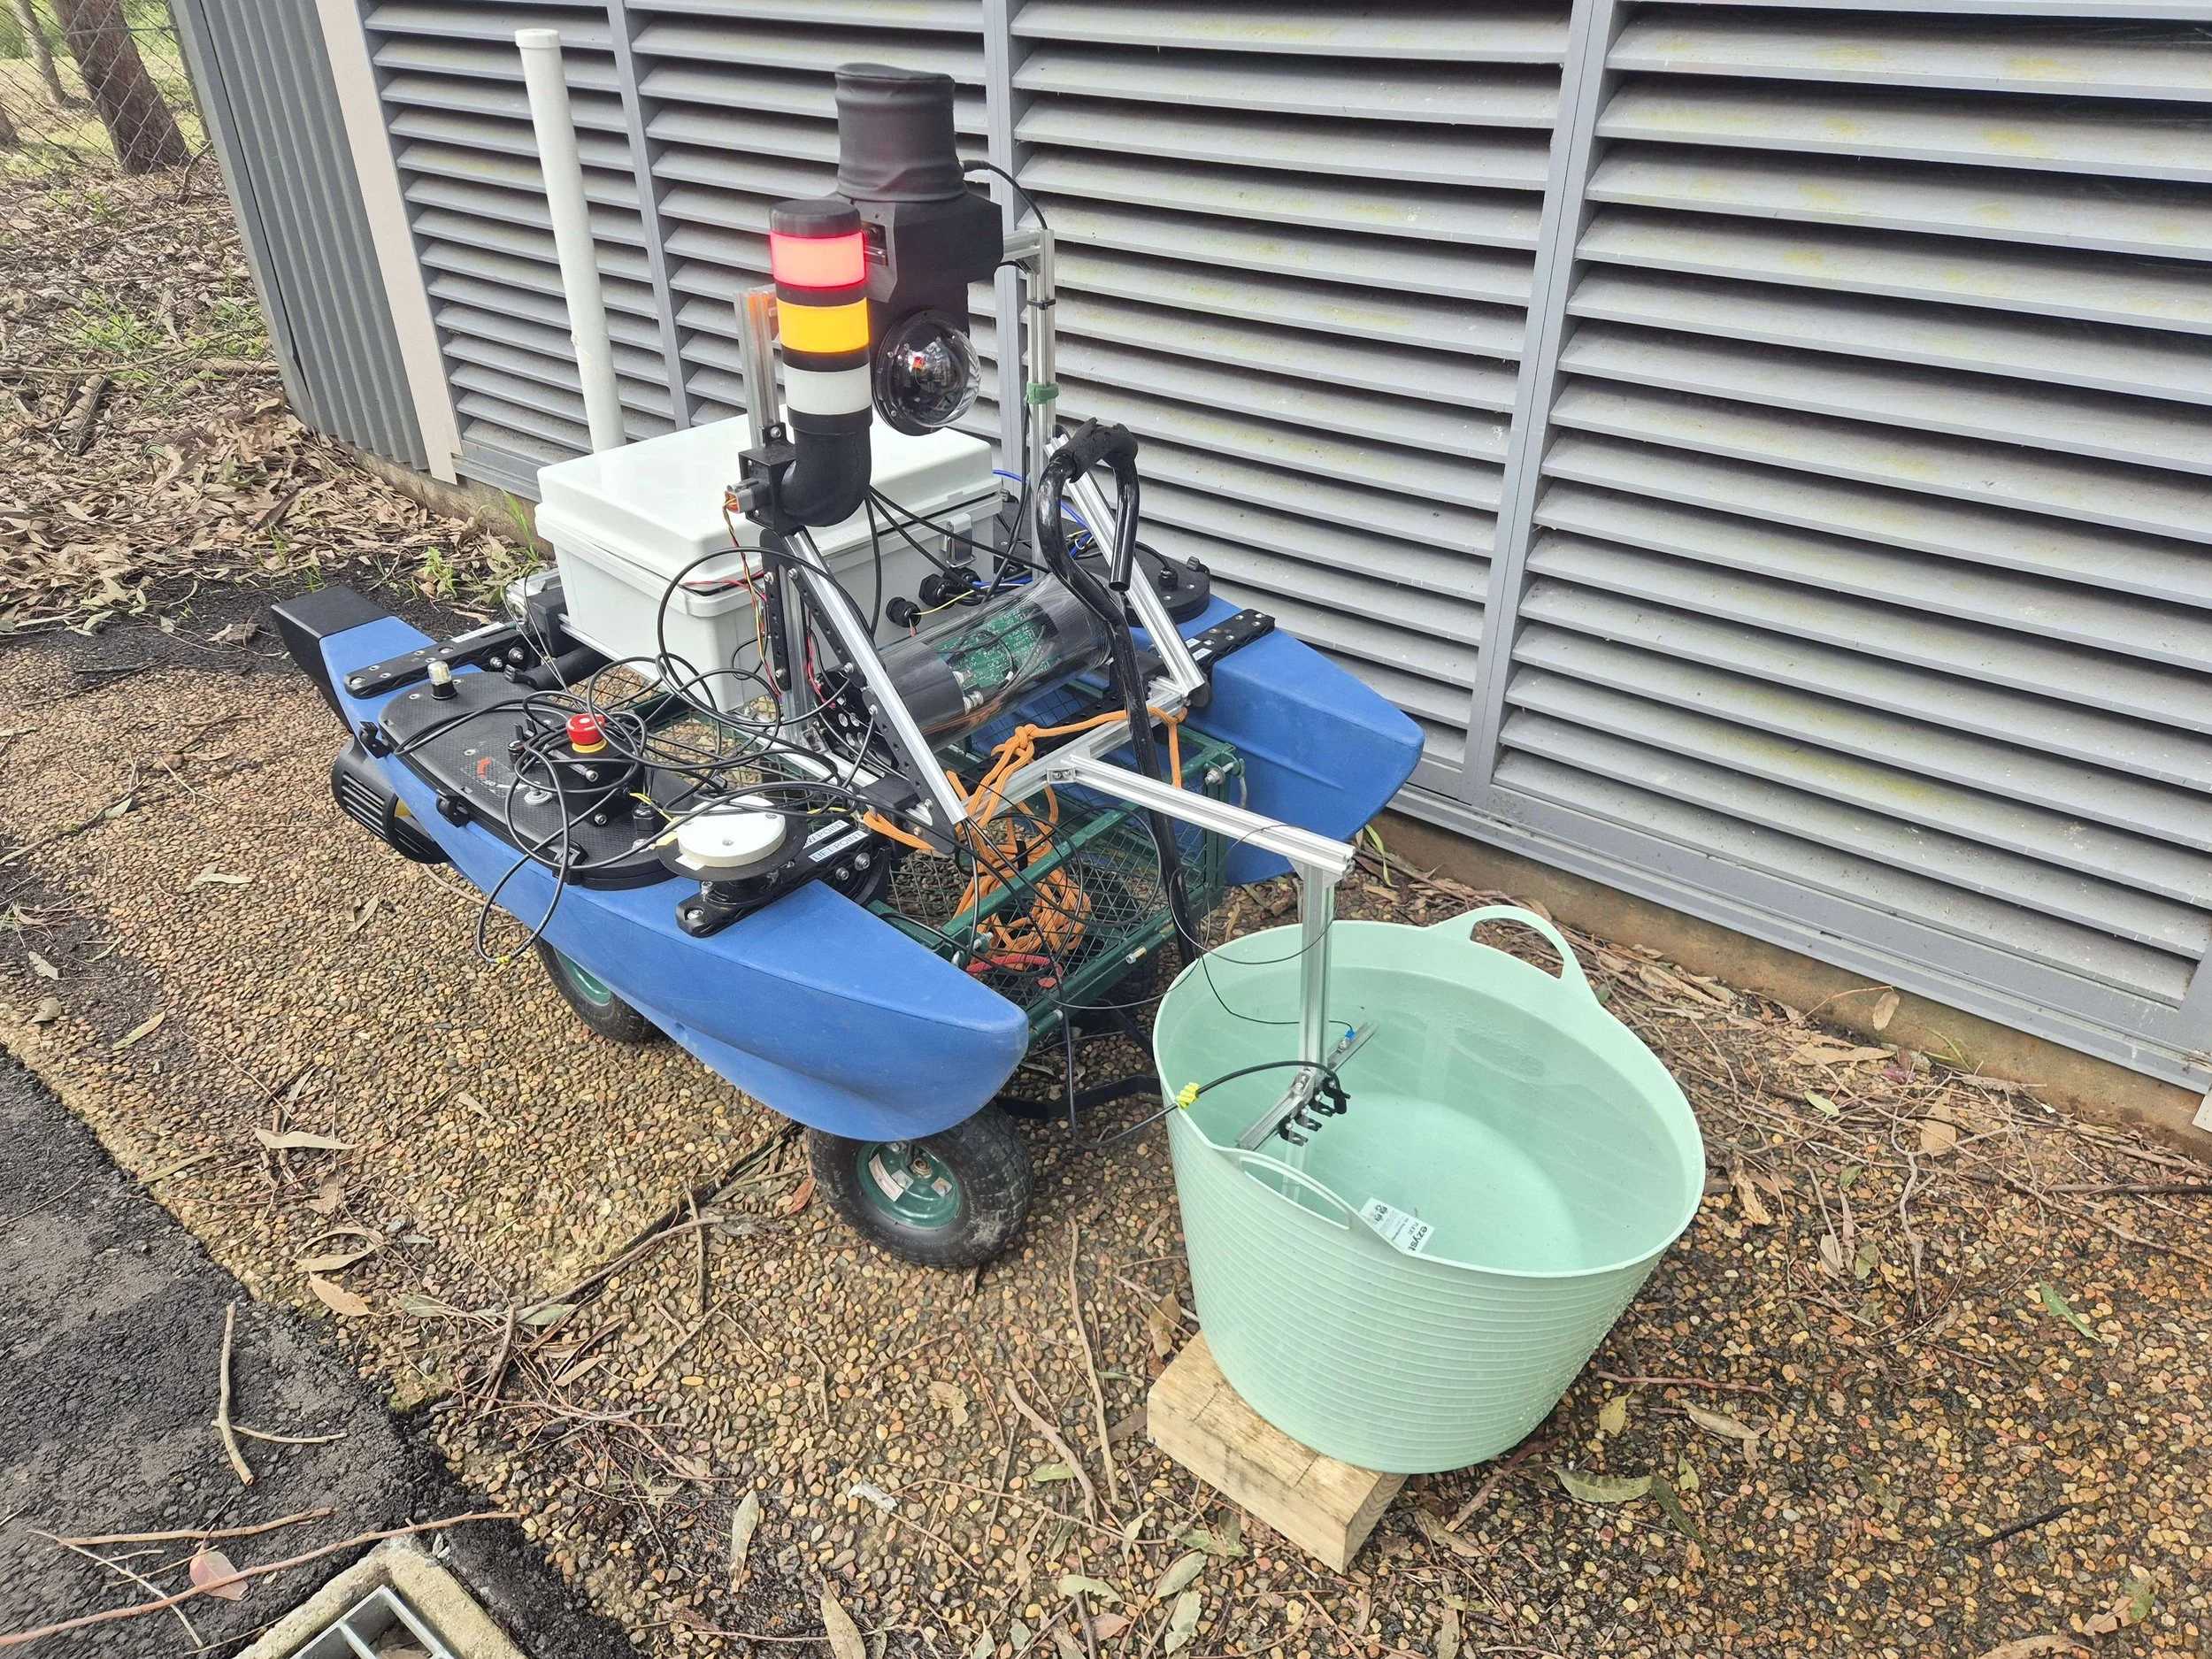
Tested the weight capacity of the boat with its current hulls
15th Jun 2026
Initial testing of hydrophone array mounted to Atlas in order to localise an acoustic pinger
19th Jun 2026
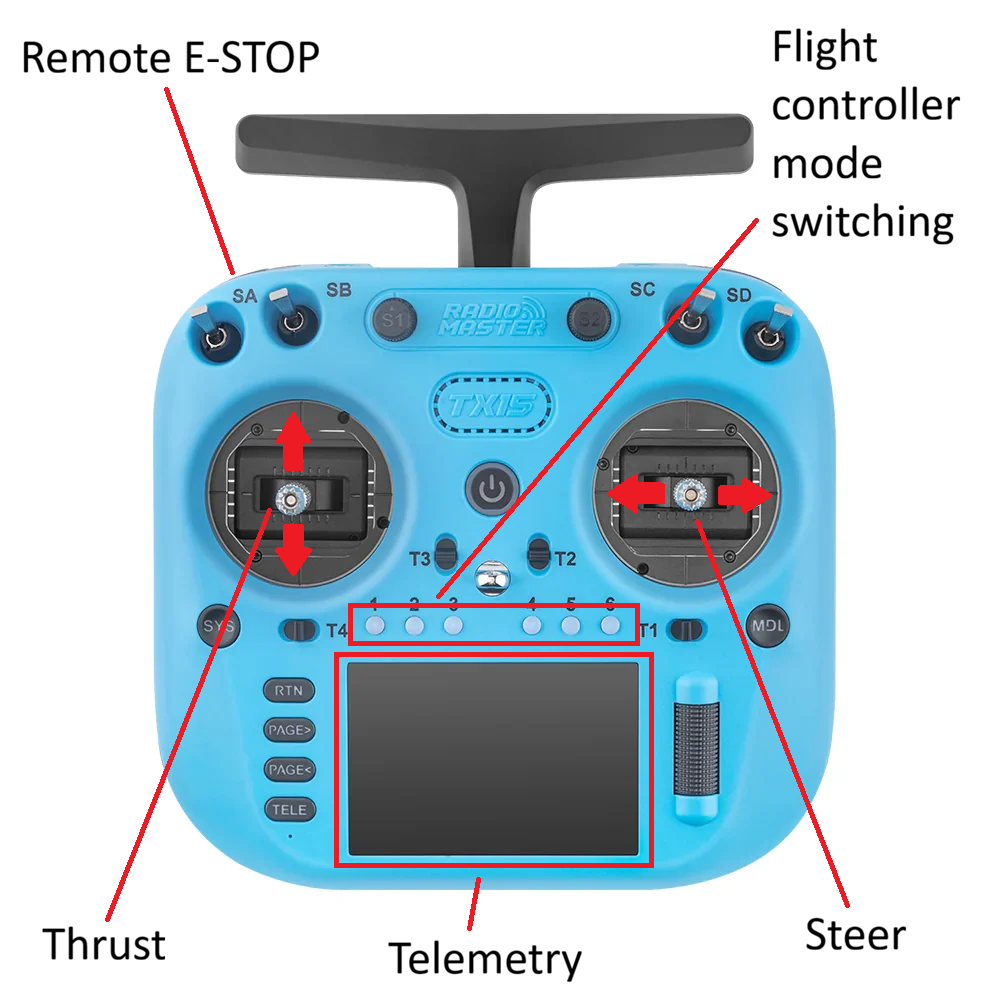
Testing failure states of Atlas and the remote E-STOP
3rd Jul 2026
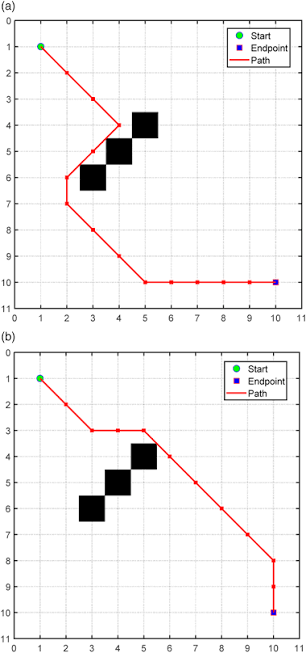
Initial test of our guidance algorithm on Atlas
Part of POR video recorded
21st Aug 2026
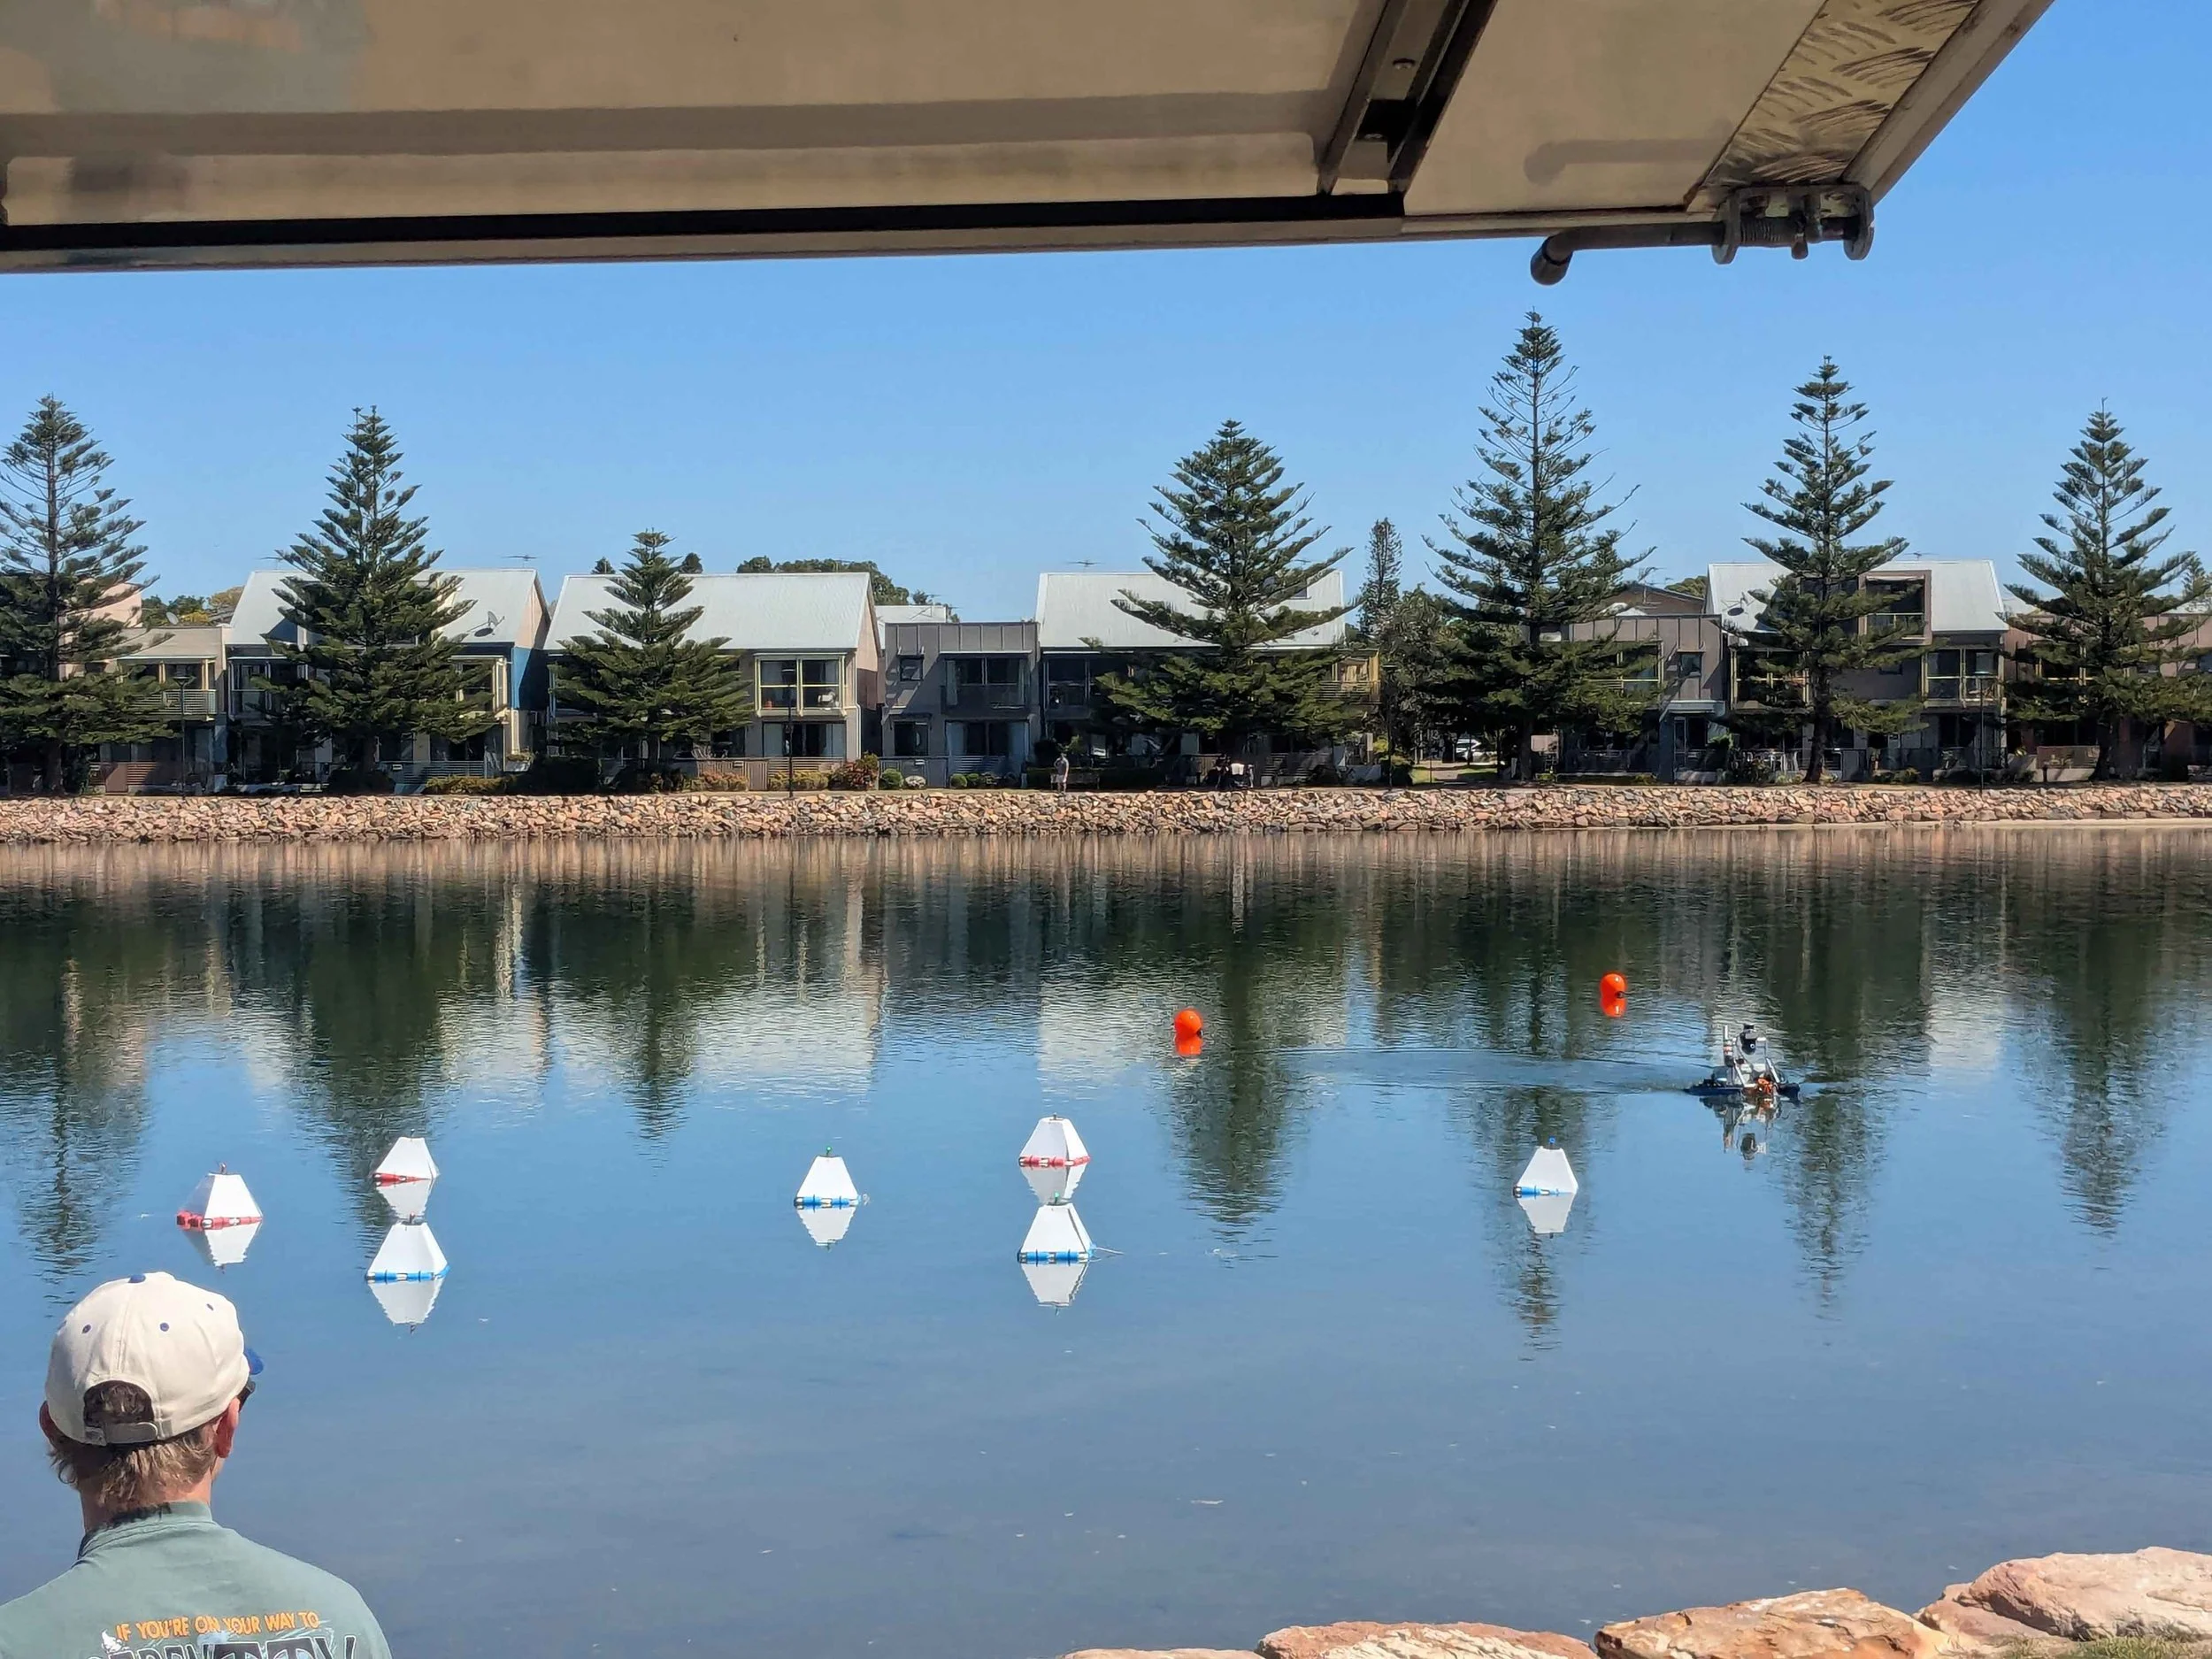
Testing of Voronoi corridor guidance solution on the water
24th Jul 2026
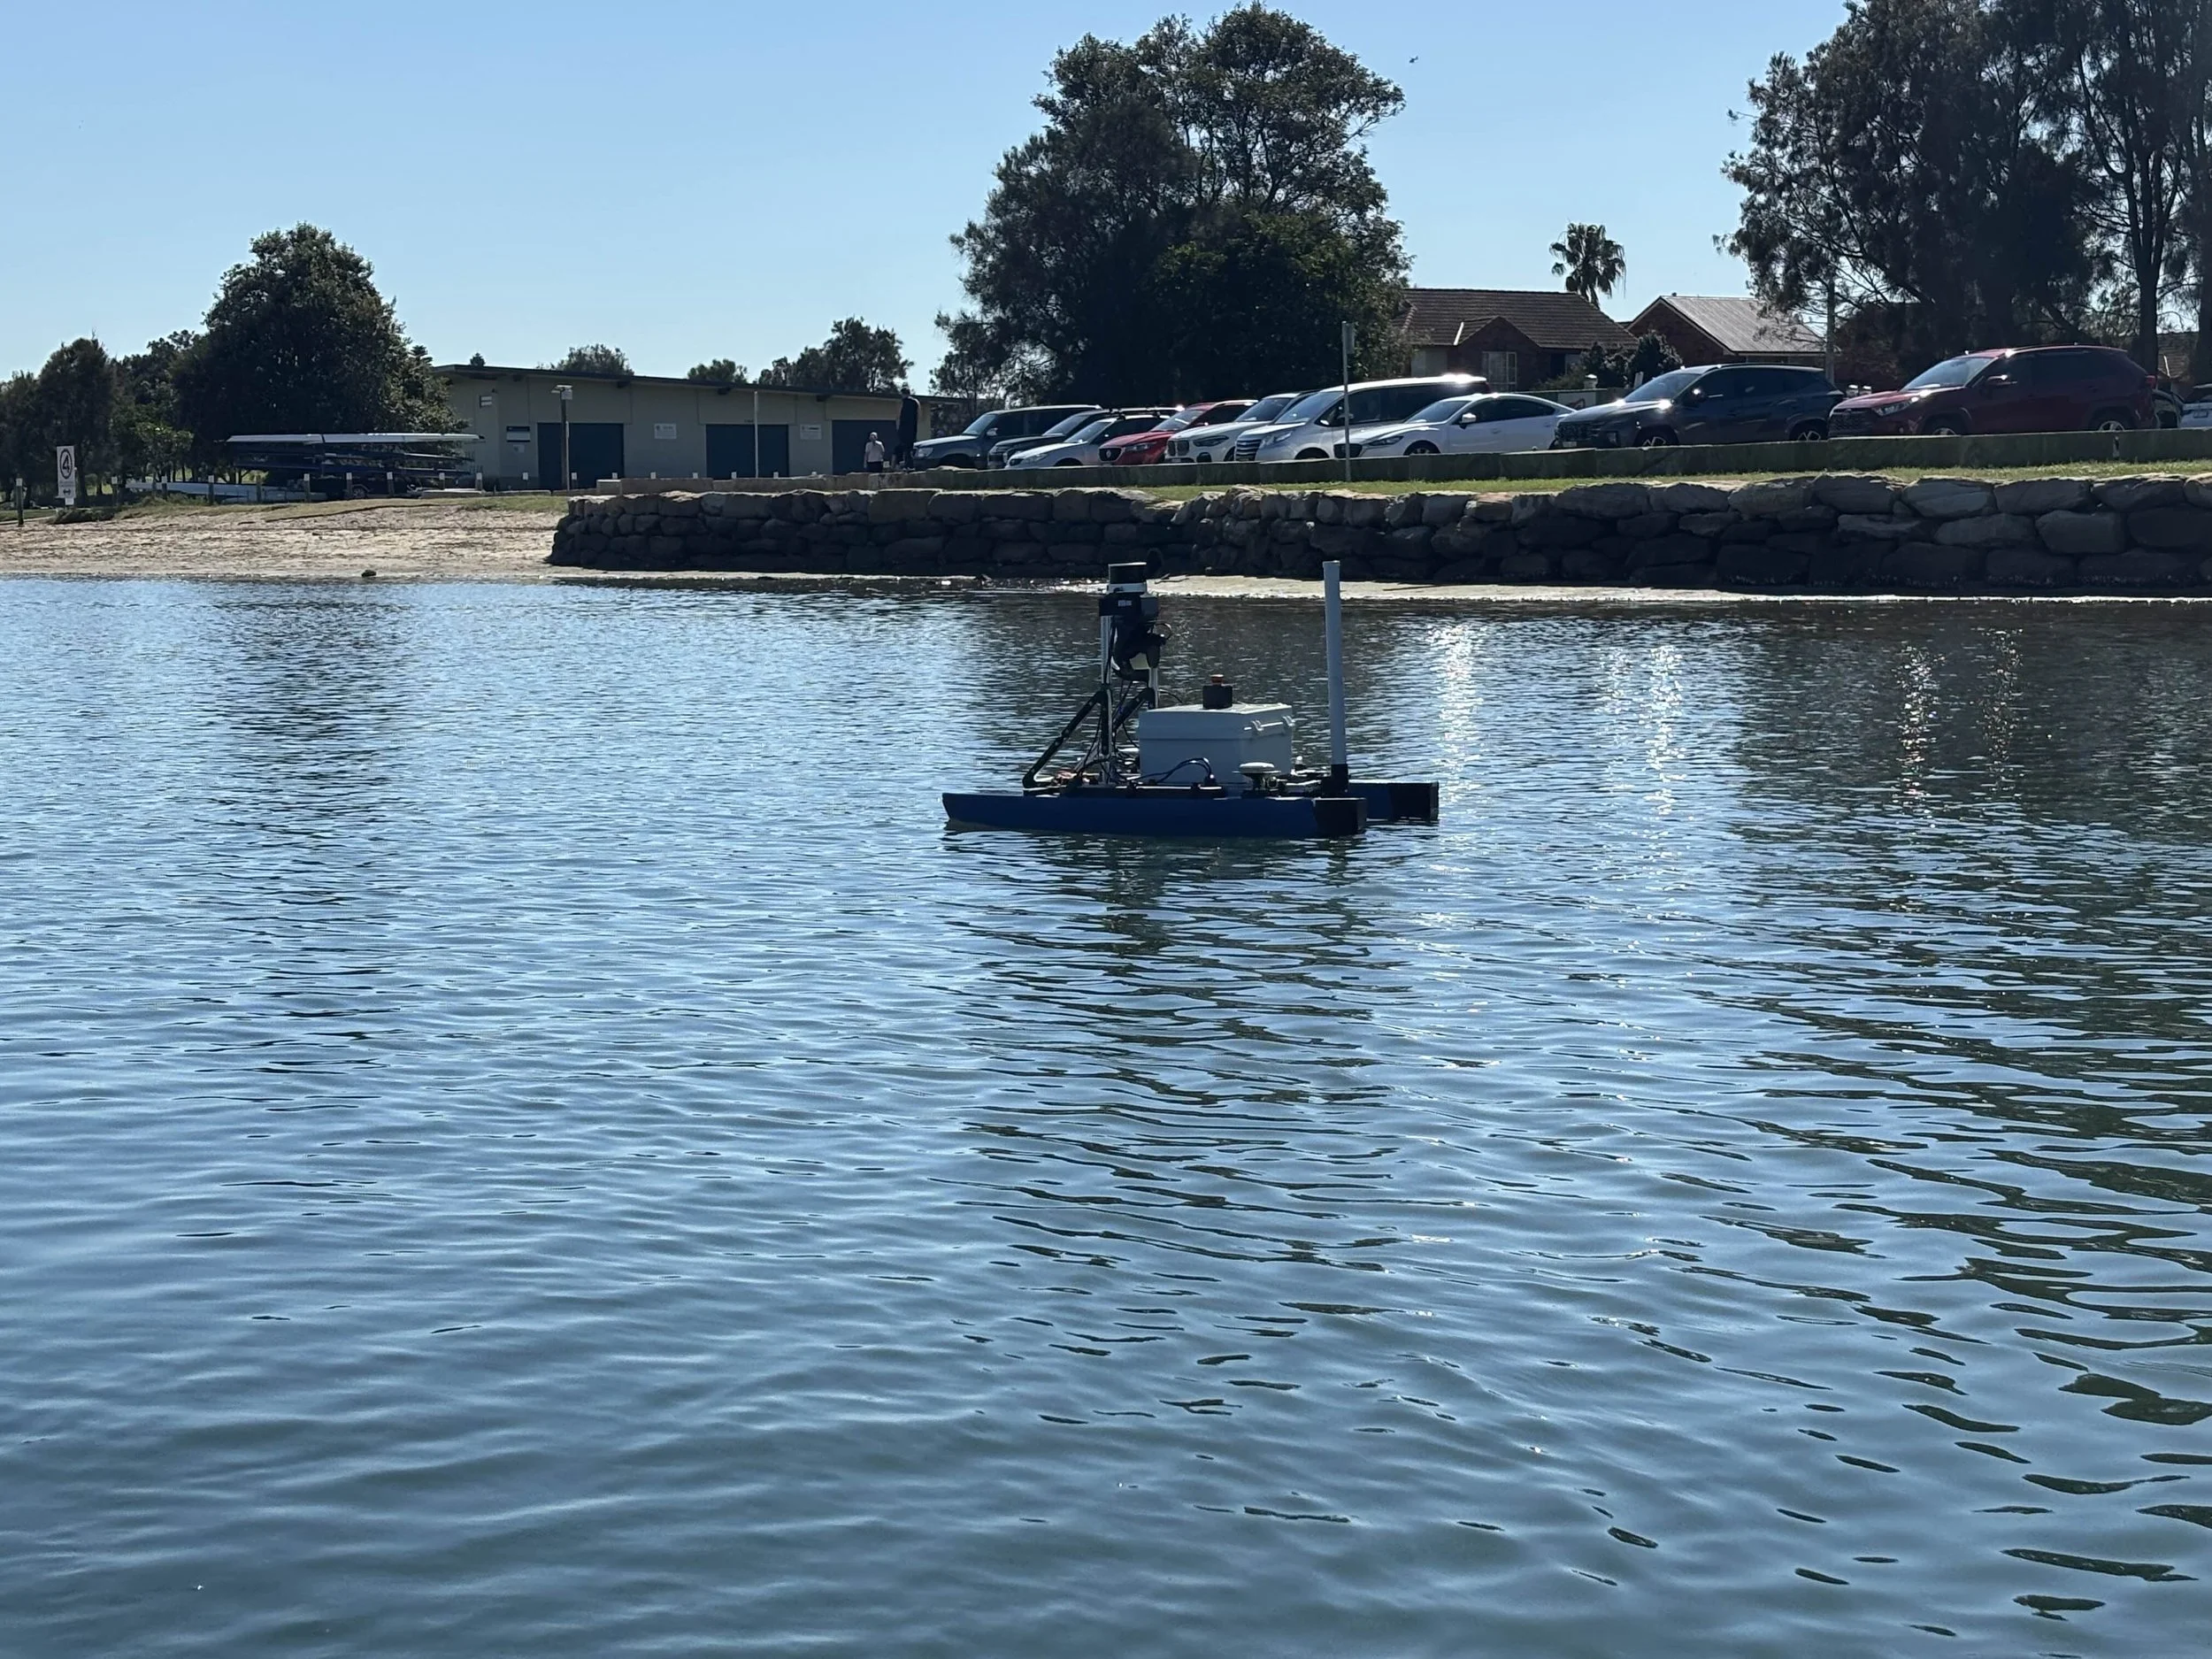
Tested mission planning architechture
11th Sep 2026
Live obstacle avoidance running using guidance and perception solutions working together
UAV - Artemis
4th - 11th Feb 2026
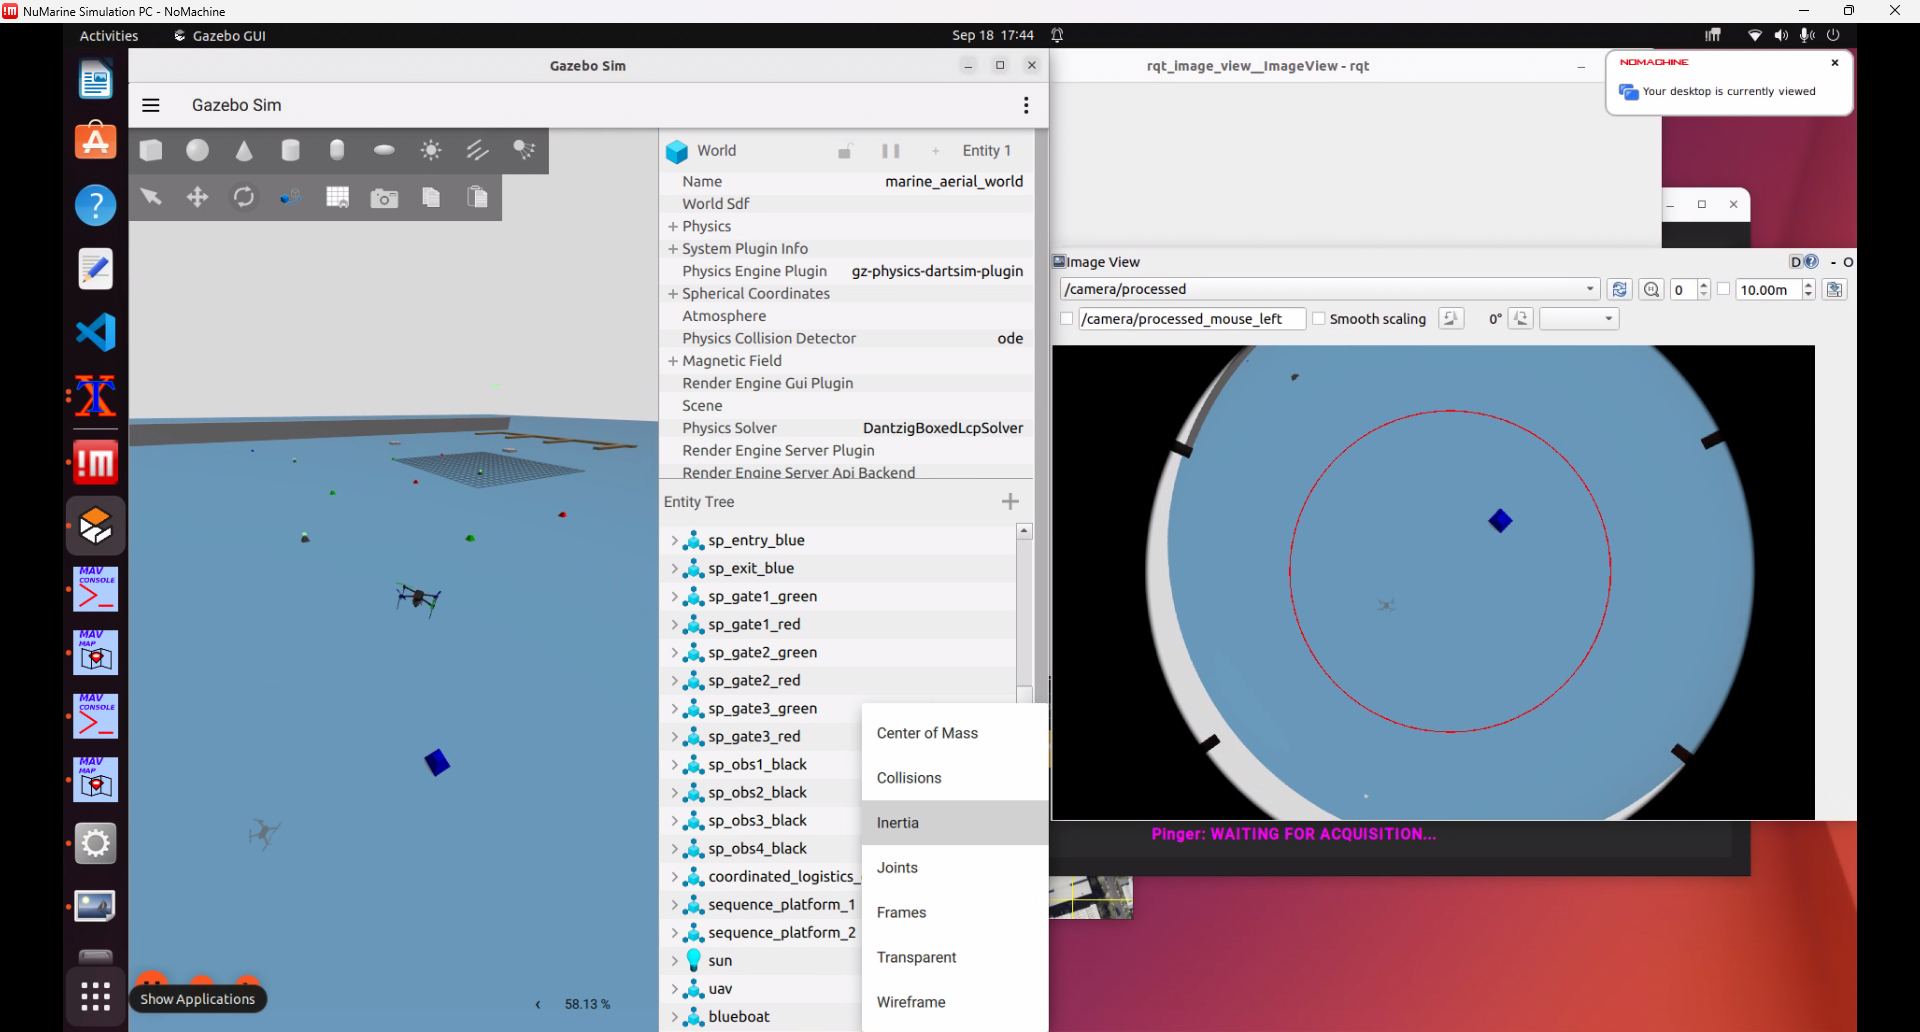
Set up mission planner, ardupilot, mavROS and SITL simulation for our UAV, Artemis
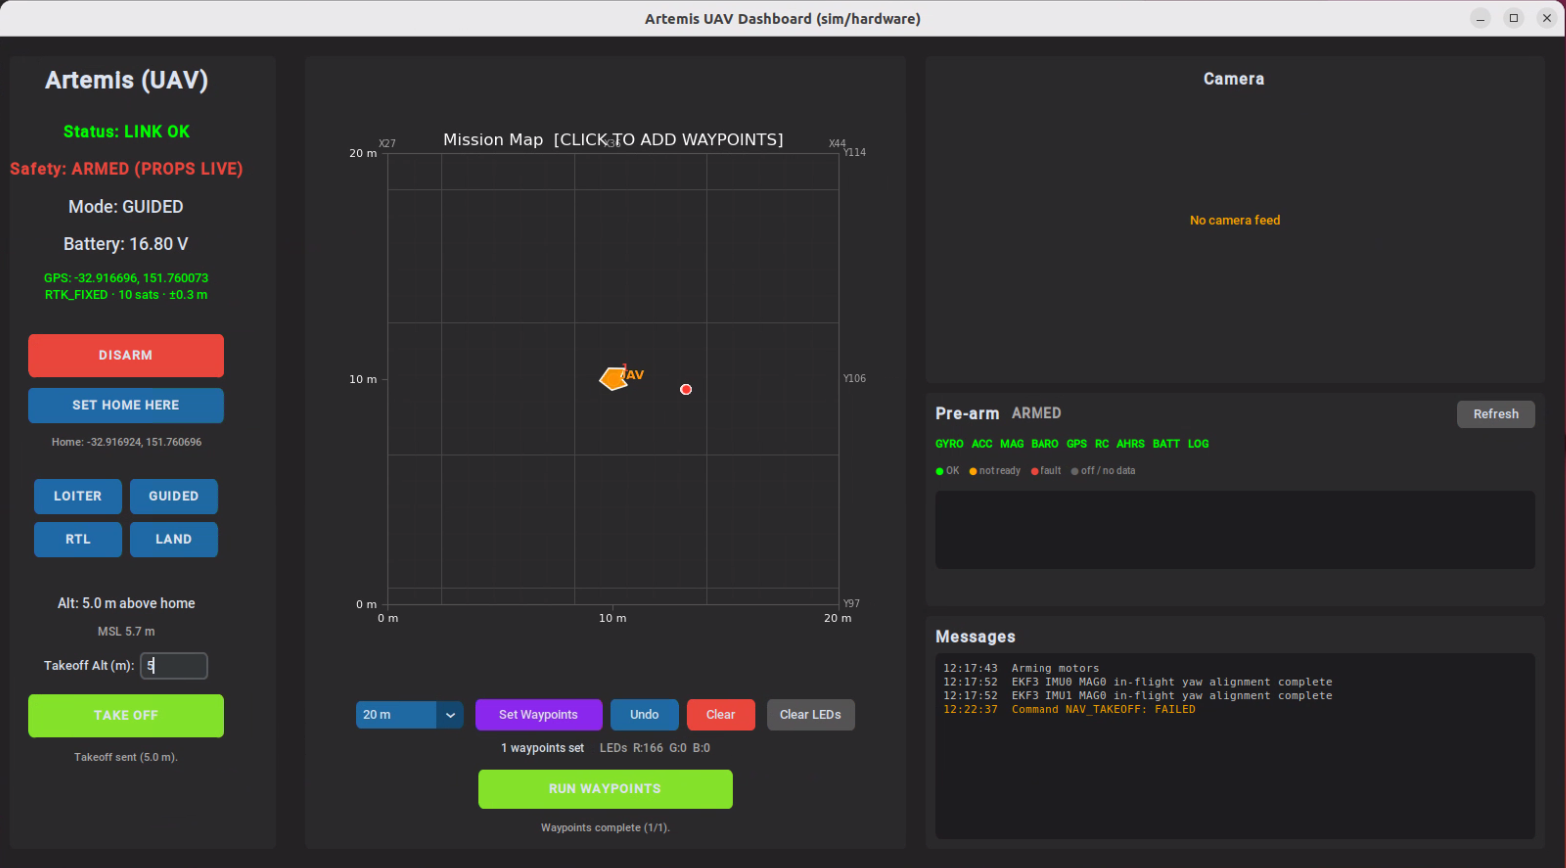
12th Mar 2026
Established control of simulated UAV using ardupilot and gazebo. Virtual flight controller was run as a SITL in conjunction with gazebo physics engine
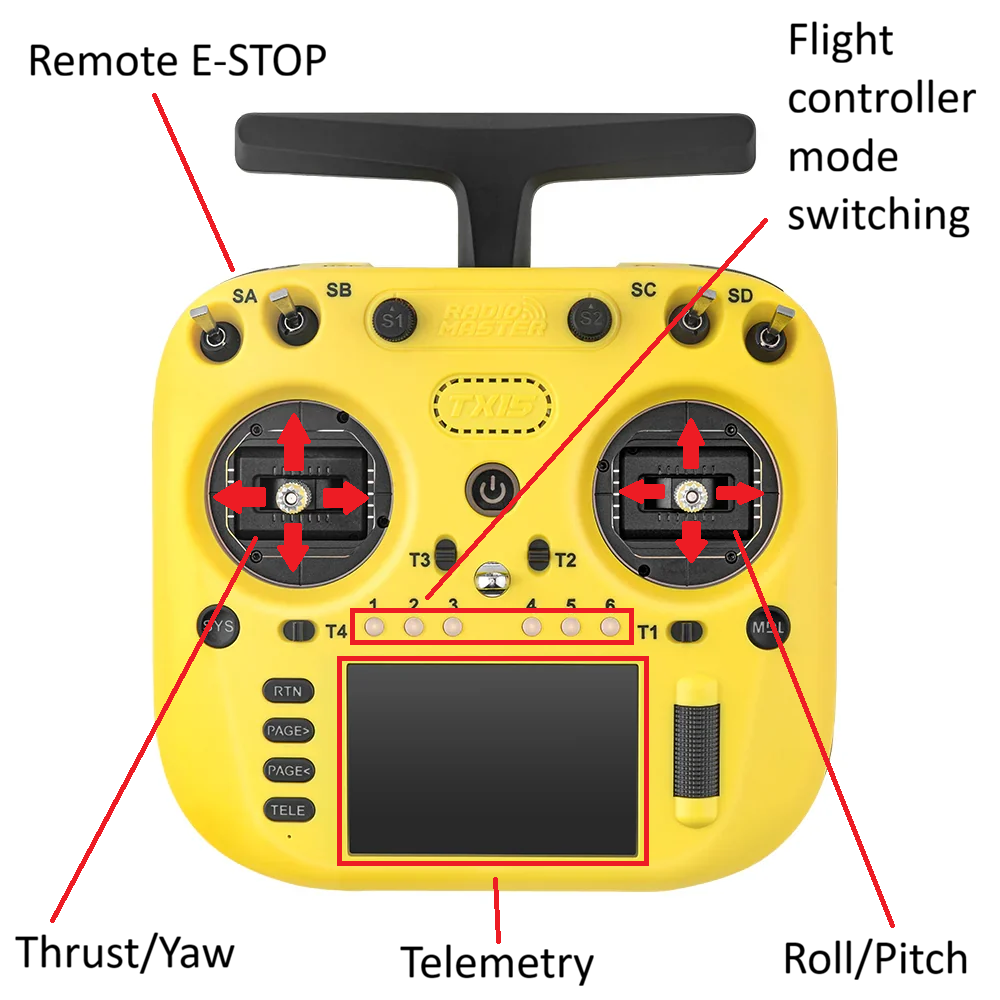
25th - 31st Mar 2026
Set up ELRS remote control including telemetry of battery data and flight mode
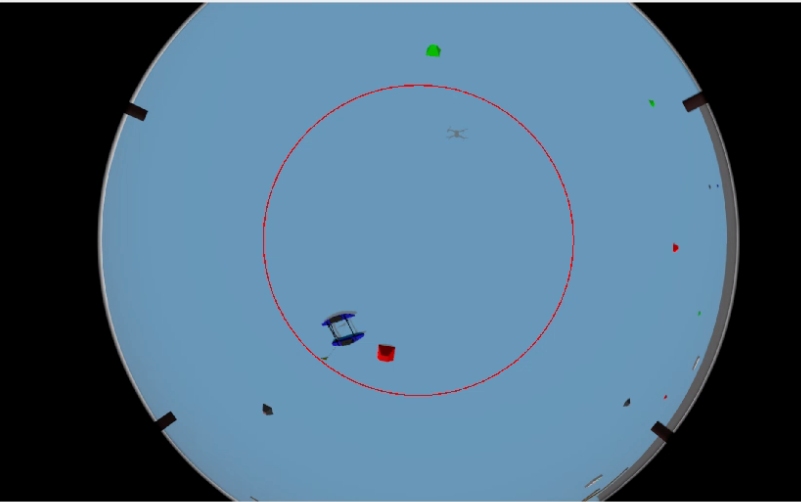
8th Apr 2026
Ran a manual waypoint mission with our simulated UAV in gazebo (SITL)
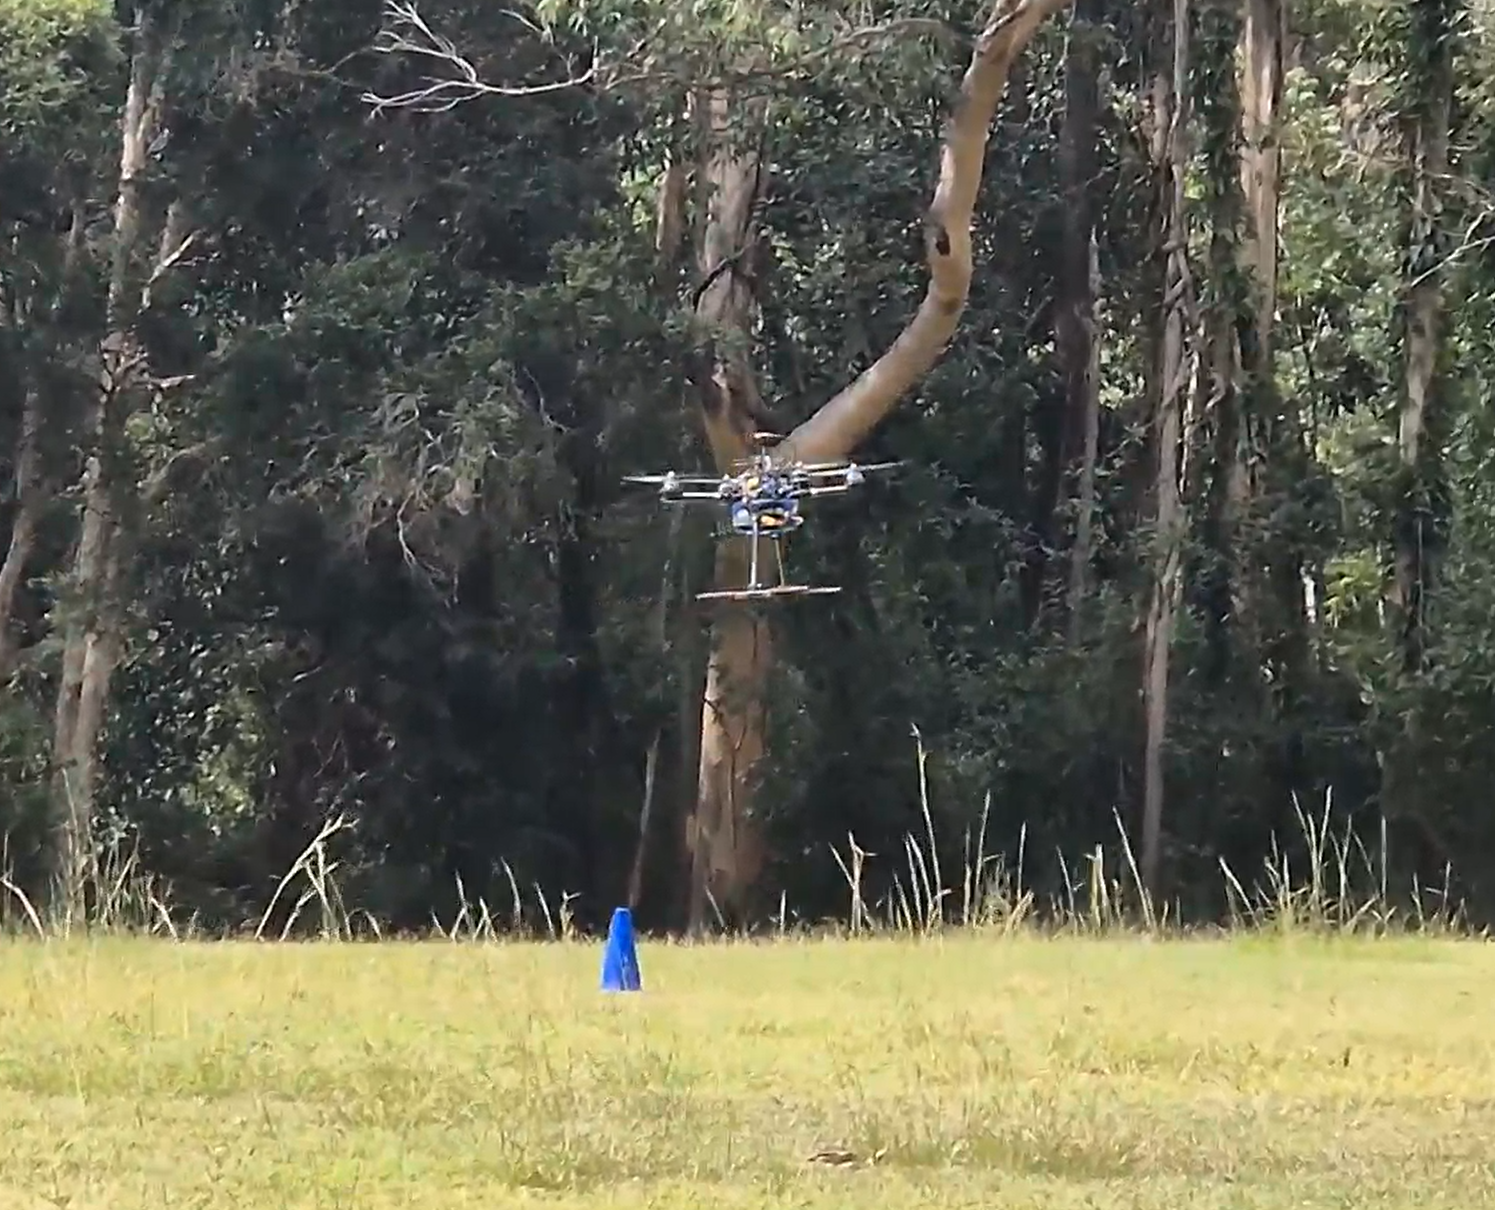
20th Apr 2026
First UAV flight! (take off and land)
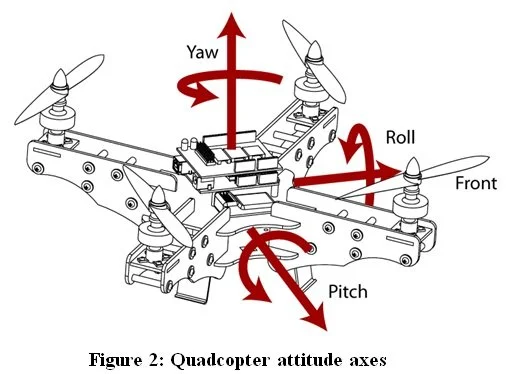
29th Apr 2026
UAV flight (calibrated accelerometer, validated RC inputs)
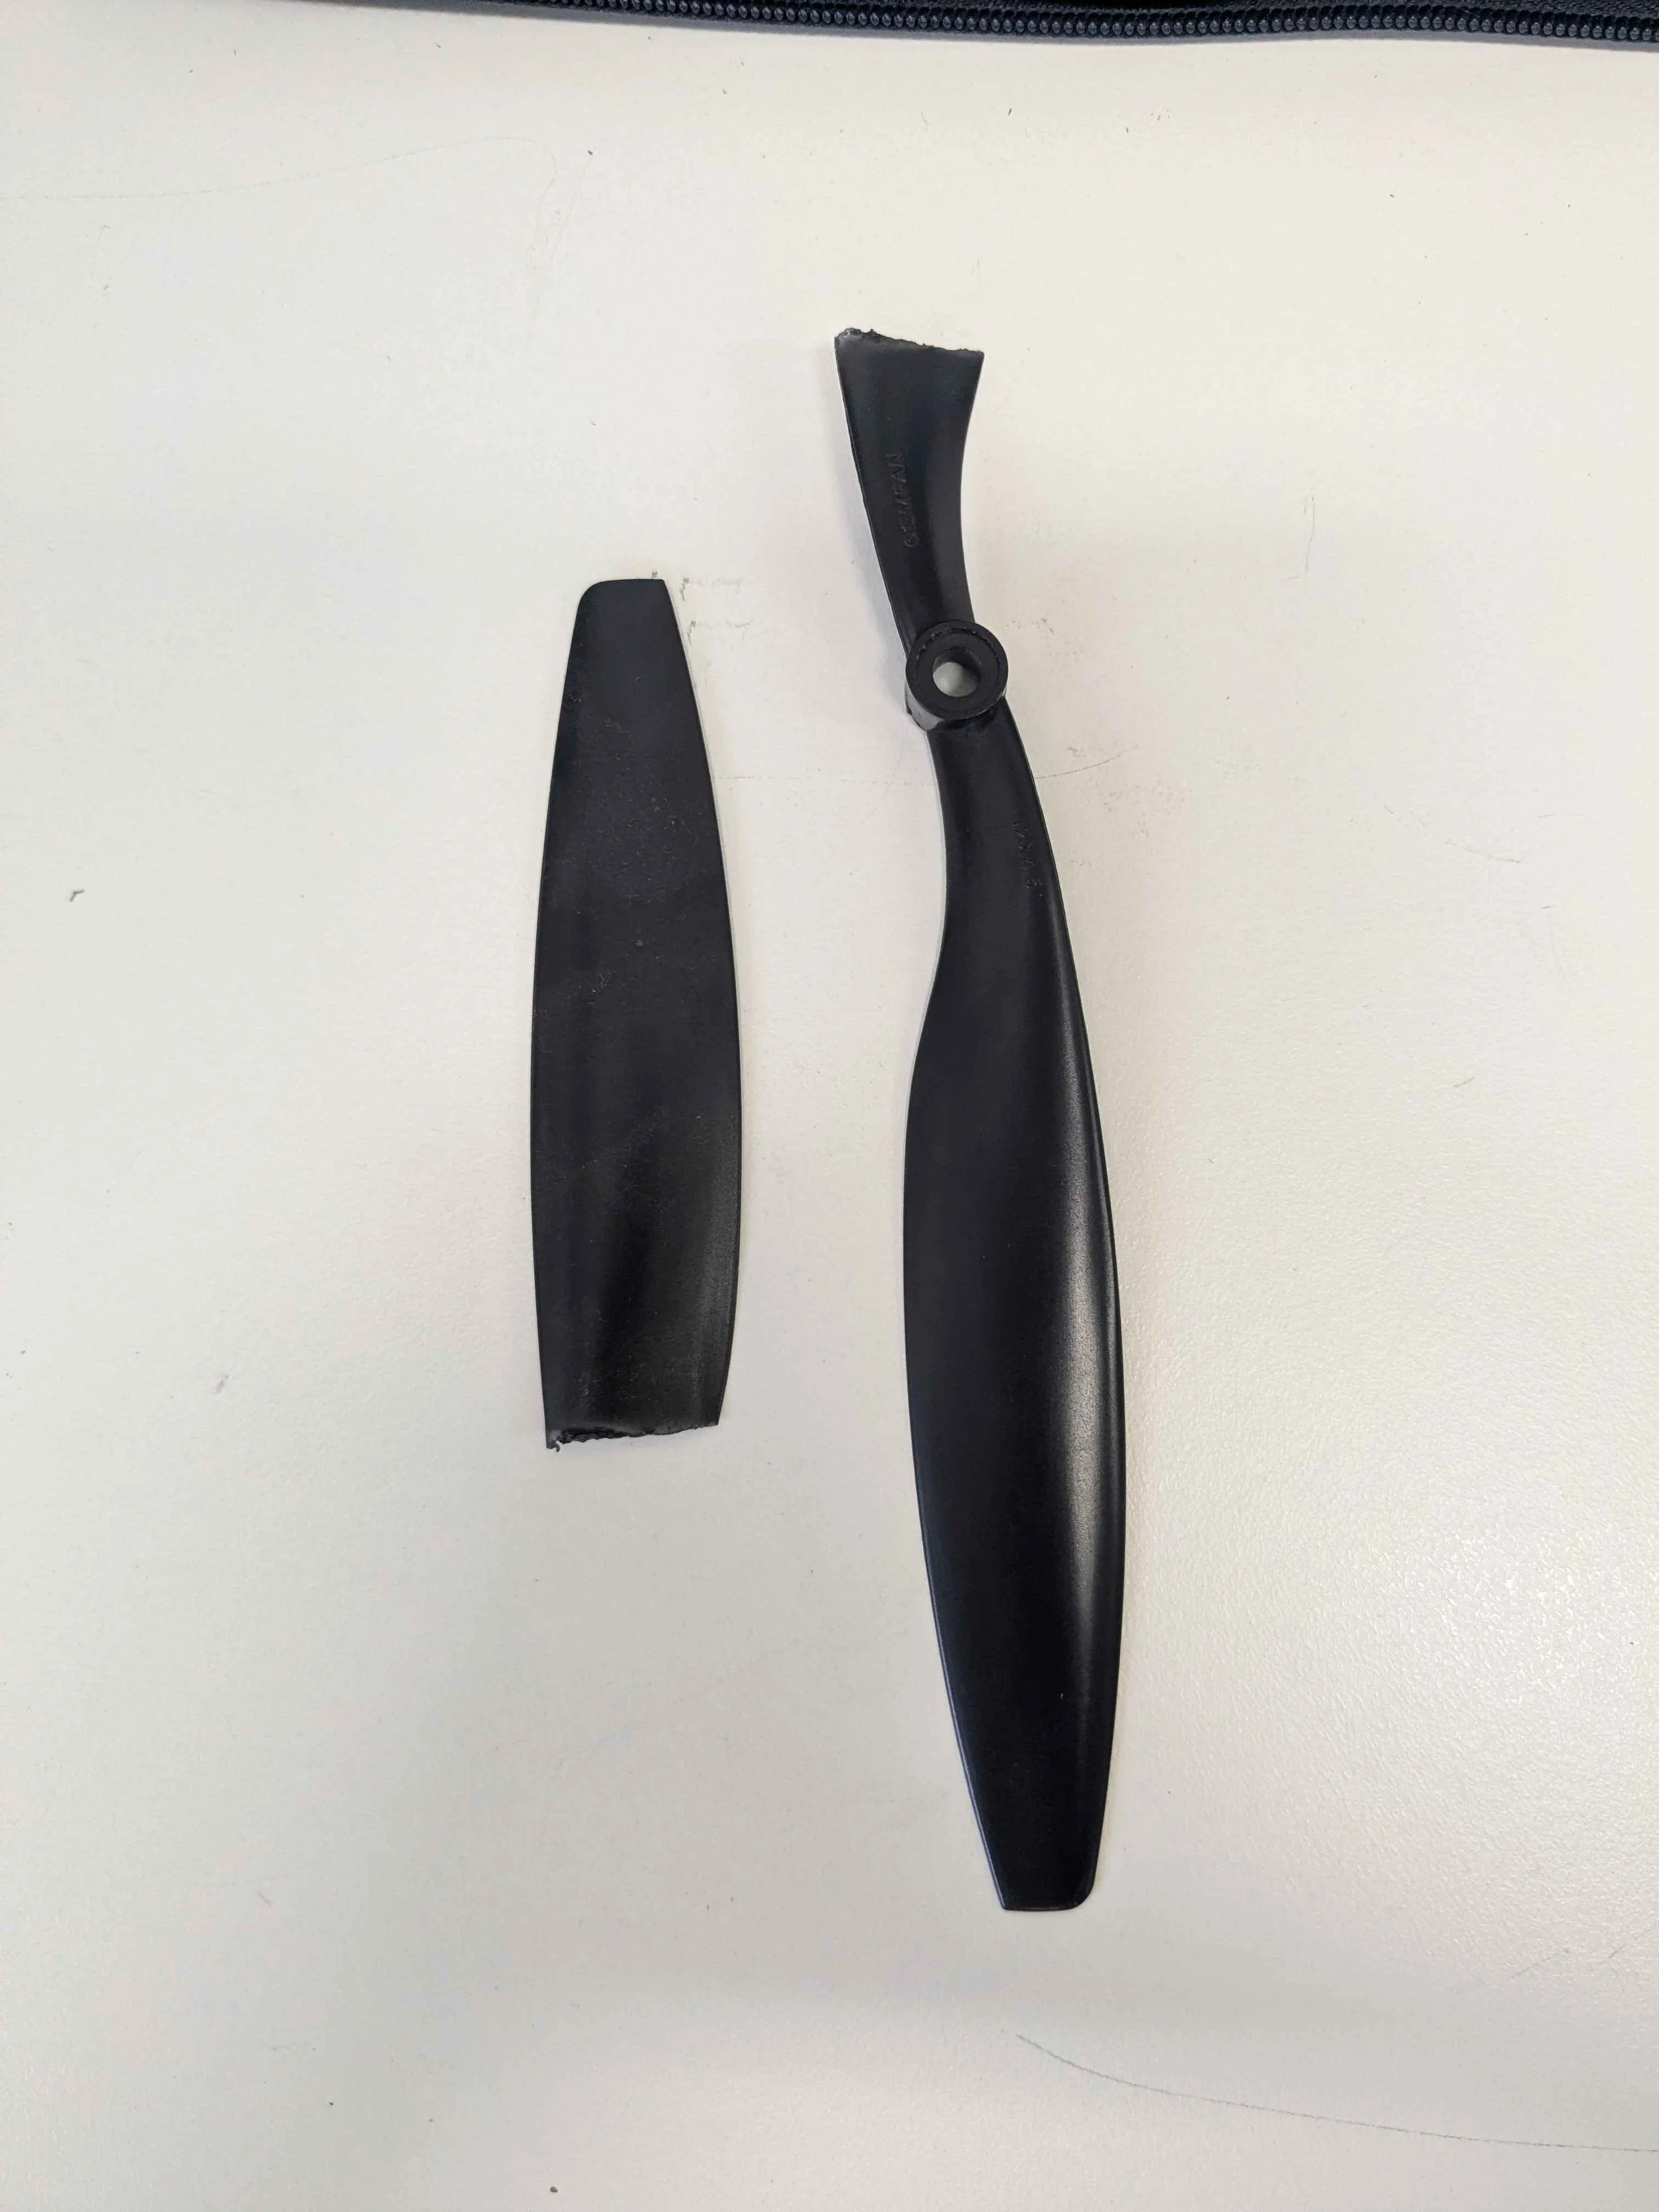
20th May 2026
UAV flight (premature use of auto-tune caused propeller failure)

27th May - 10th Jun 2026
Re-calibrate Flight Controller using manual tuning while grounded (non-flying calibrations)
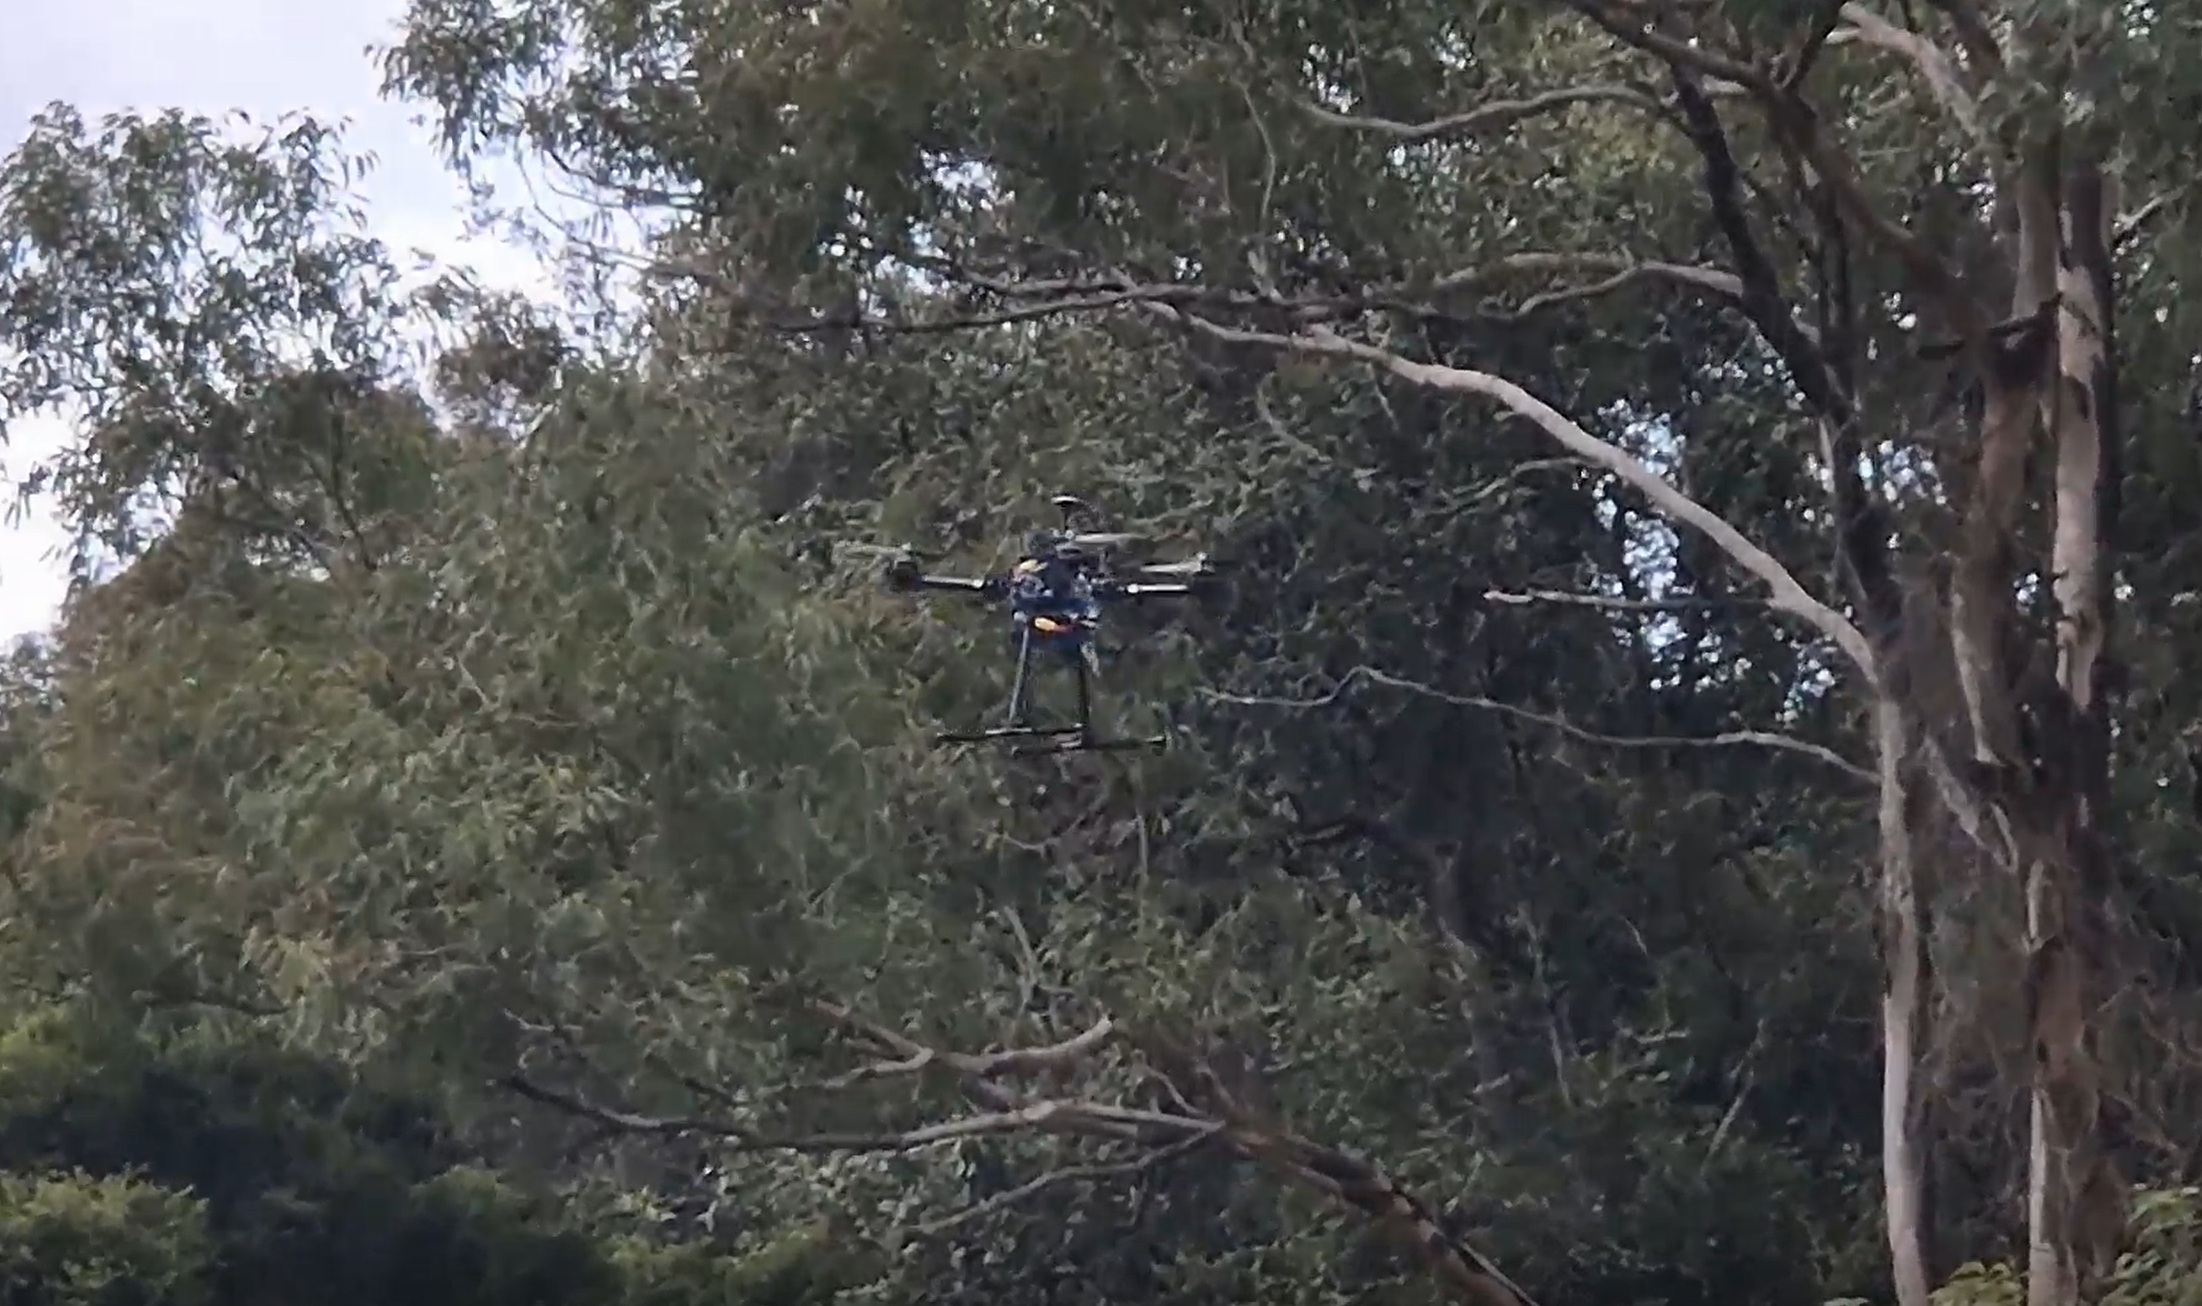
19th Jun 2026
UAV flight. Hover test flight, collecting baseline flight data
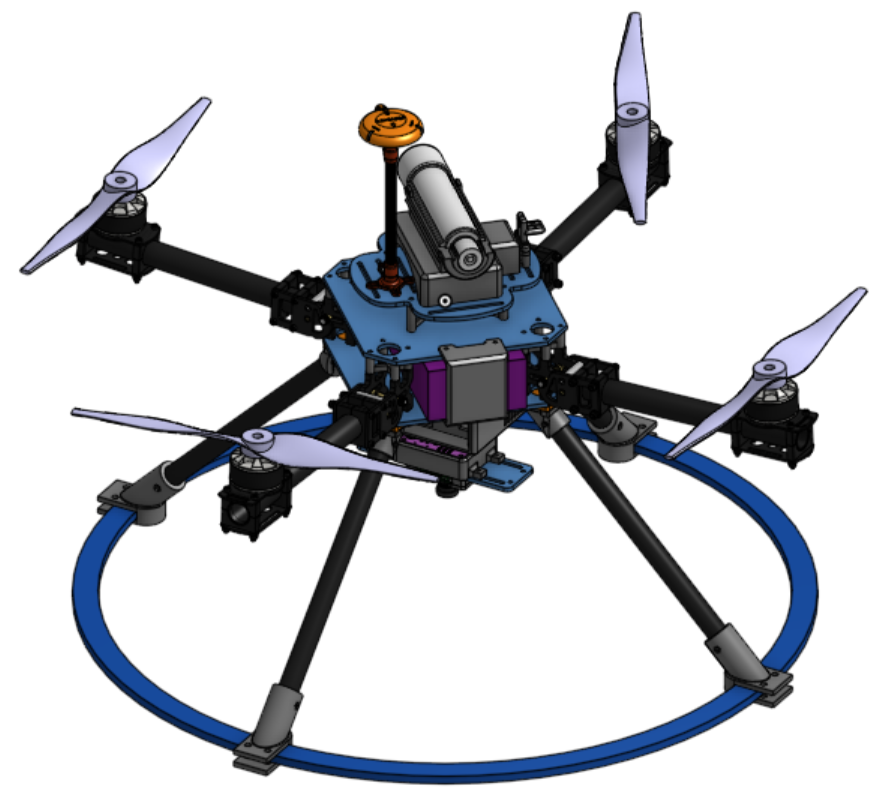
8th - 22nd Jul 2026
Mechanical overhaul of the UAV including:
Redesign of landing gear
Fabrication of stronger chassis parts
Mounting designed for WIFI antenna
Selected new ESCs for reading motor RPM data
Configured ubiquiti bullet WIFI antenna
23rd Jul 2026
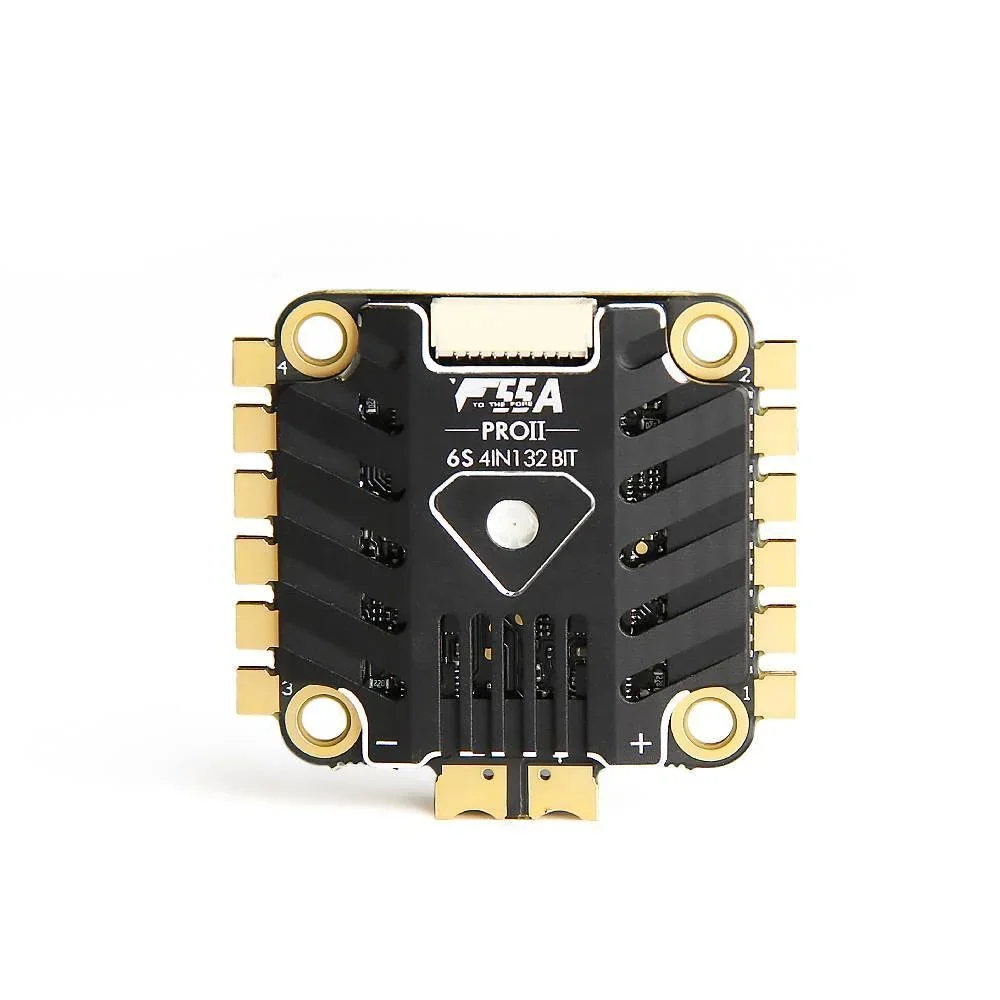
New, bi-directional ESCs configured (firmware flashed flashed and tuned)
24th Jul 2026
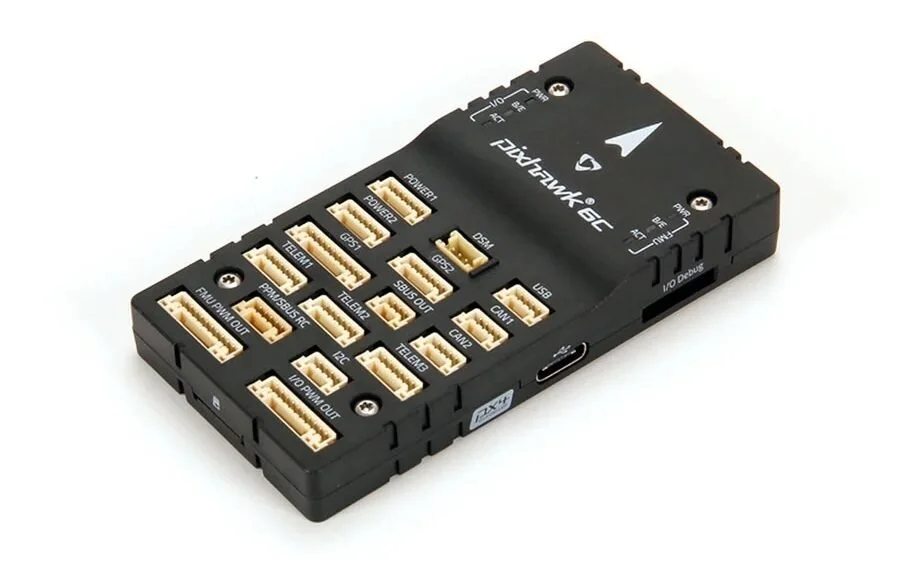
Updated pixhawk firmware on flight controller and configured bidirectional DSHOT on ESCs to be used for filtering out noise and improving flight performance
14th - 15th Aug 2026
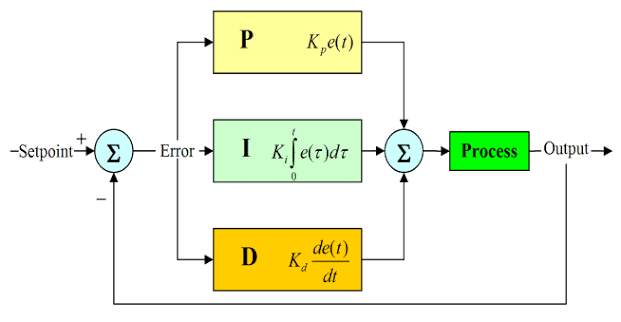
PID tuning of each axis
18th - 22nd Aug 2026
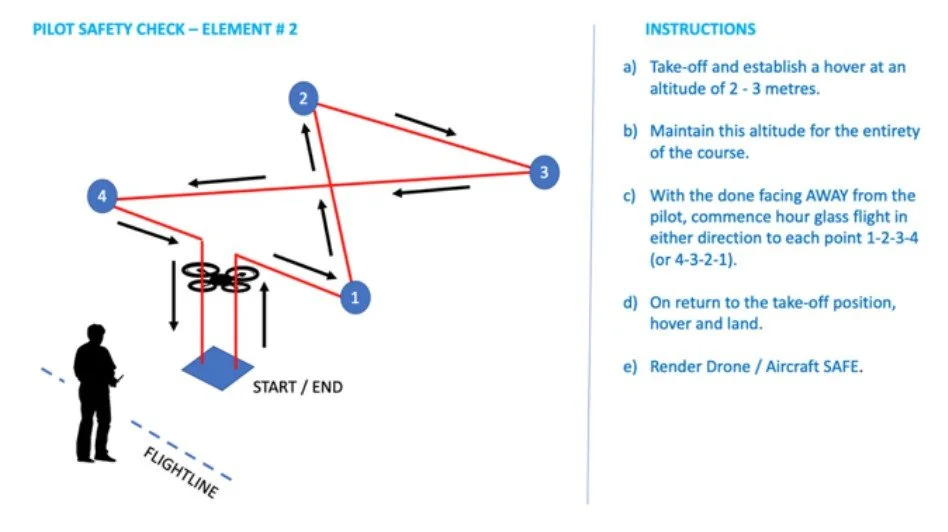
Created POR videos and documents
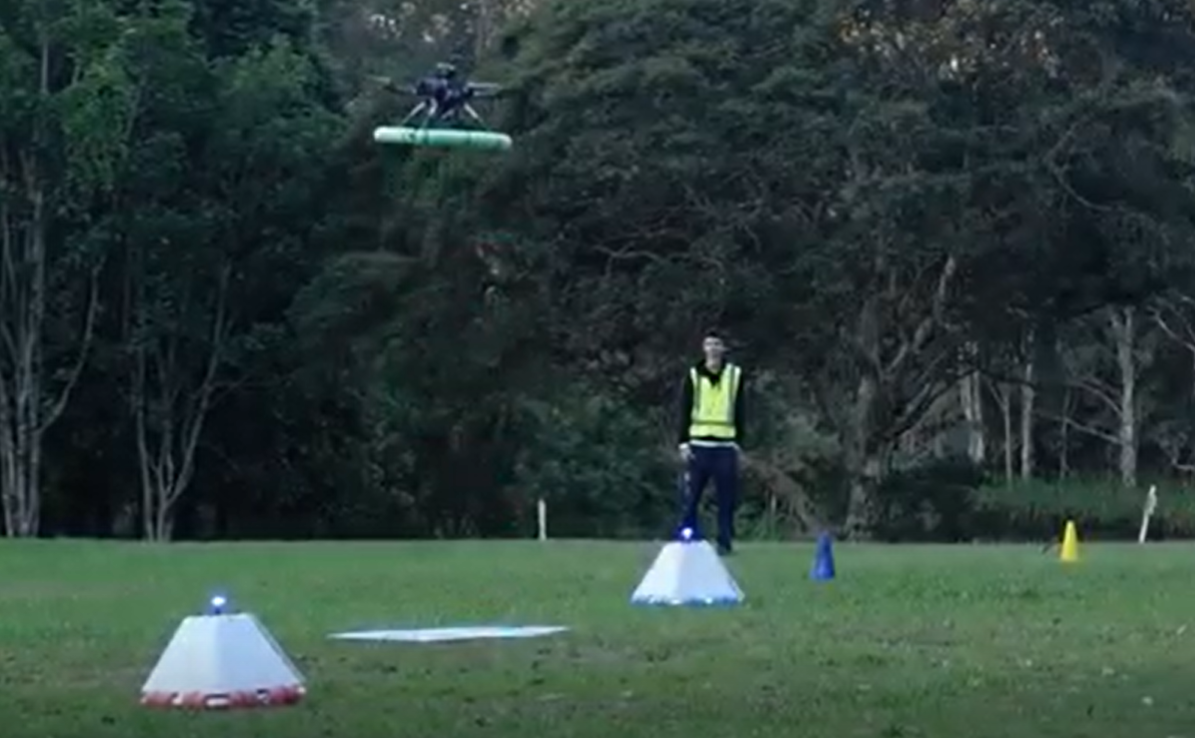
17th Aug 2026
NU Marine’s first fully autonomous flight!
UUV - Bastet
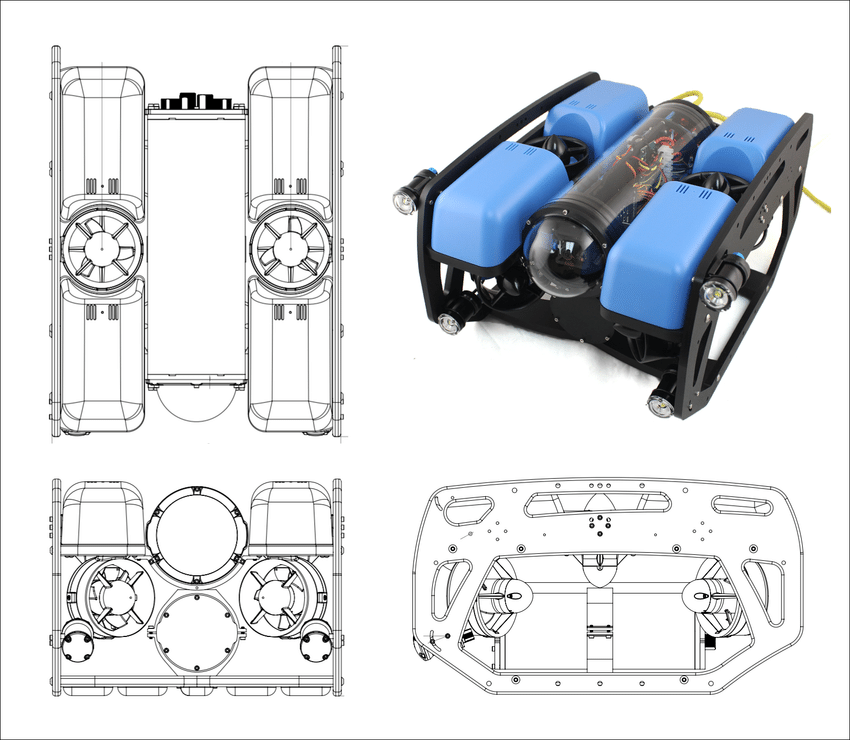
26th Jan 2026
Assembly of our BlueROV2 UUV, Bastet
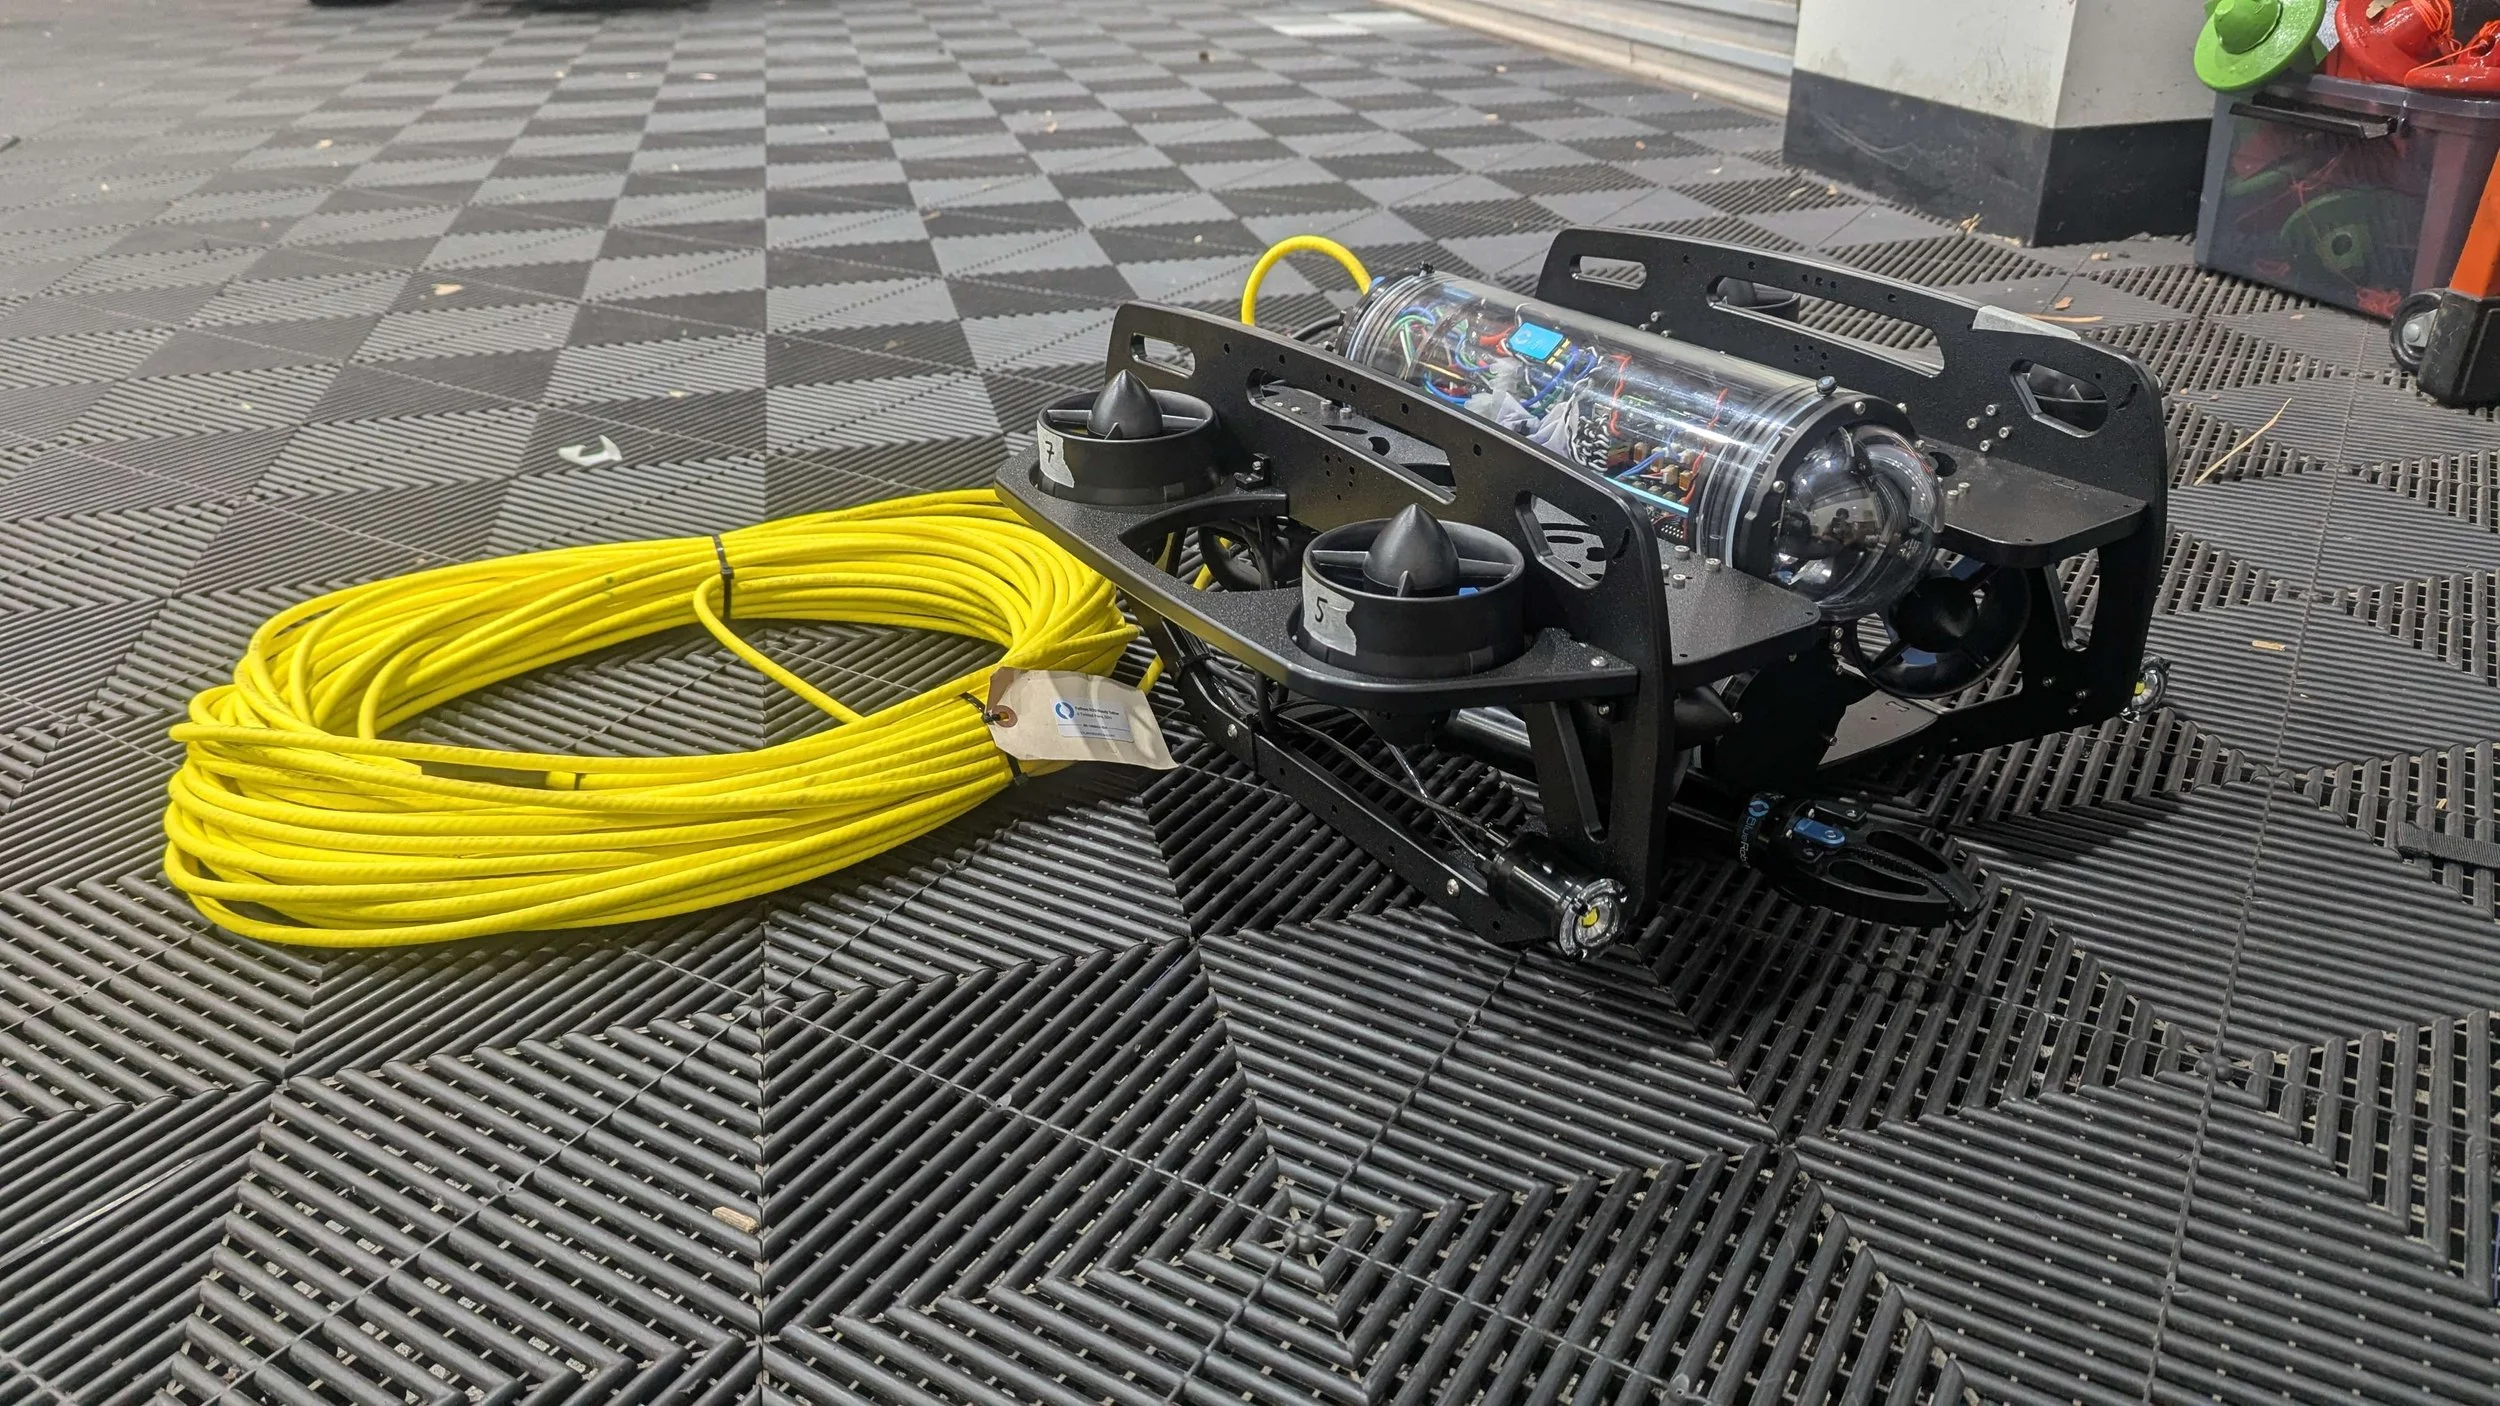
28th Jan 2026
Bench testing of Bastet (powered by power supply) and remote control configuration
13th Feb 2026
First SUB test day
System checks
Motor calibration
Emergency protocols validated
Practice tethered remote control operation
First buoyancy checks
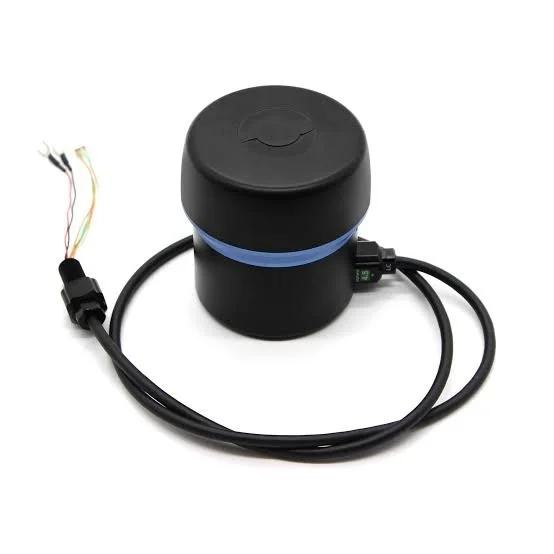
17th Feb 2026
Blue Robotics SONAR mounted and connected in workshop
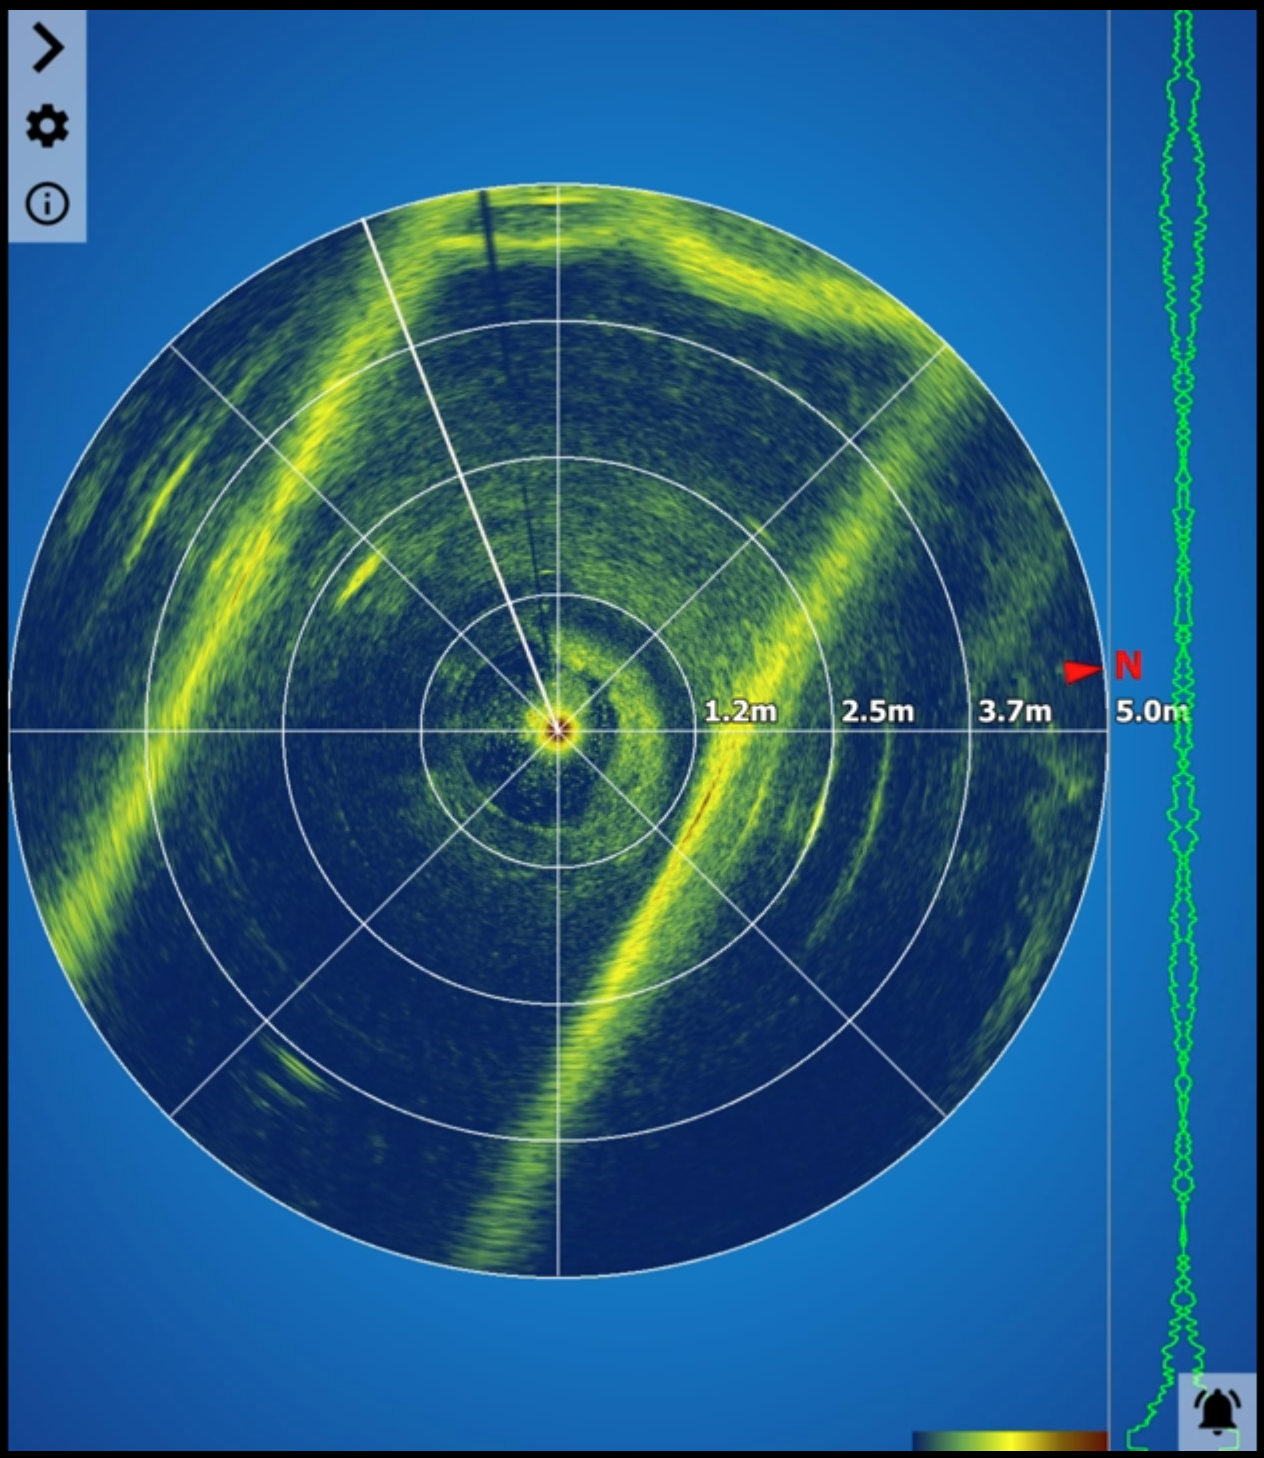
20th Feb 2026
SUB test day
Controller tuning
Tested SONAR using Ping Viewer
Validate that ROS can run python scripts/nodes to actuate motors
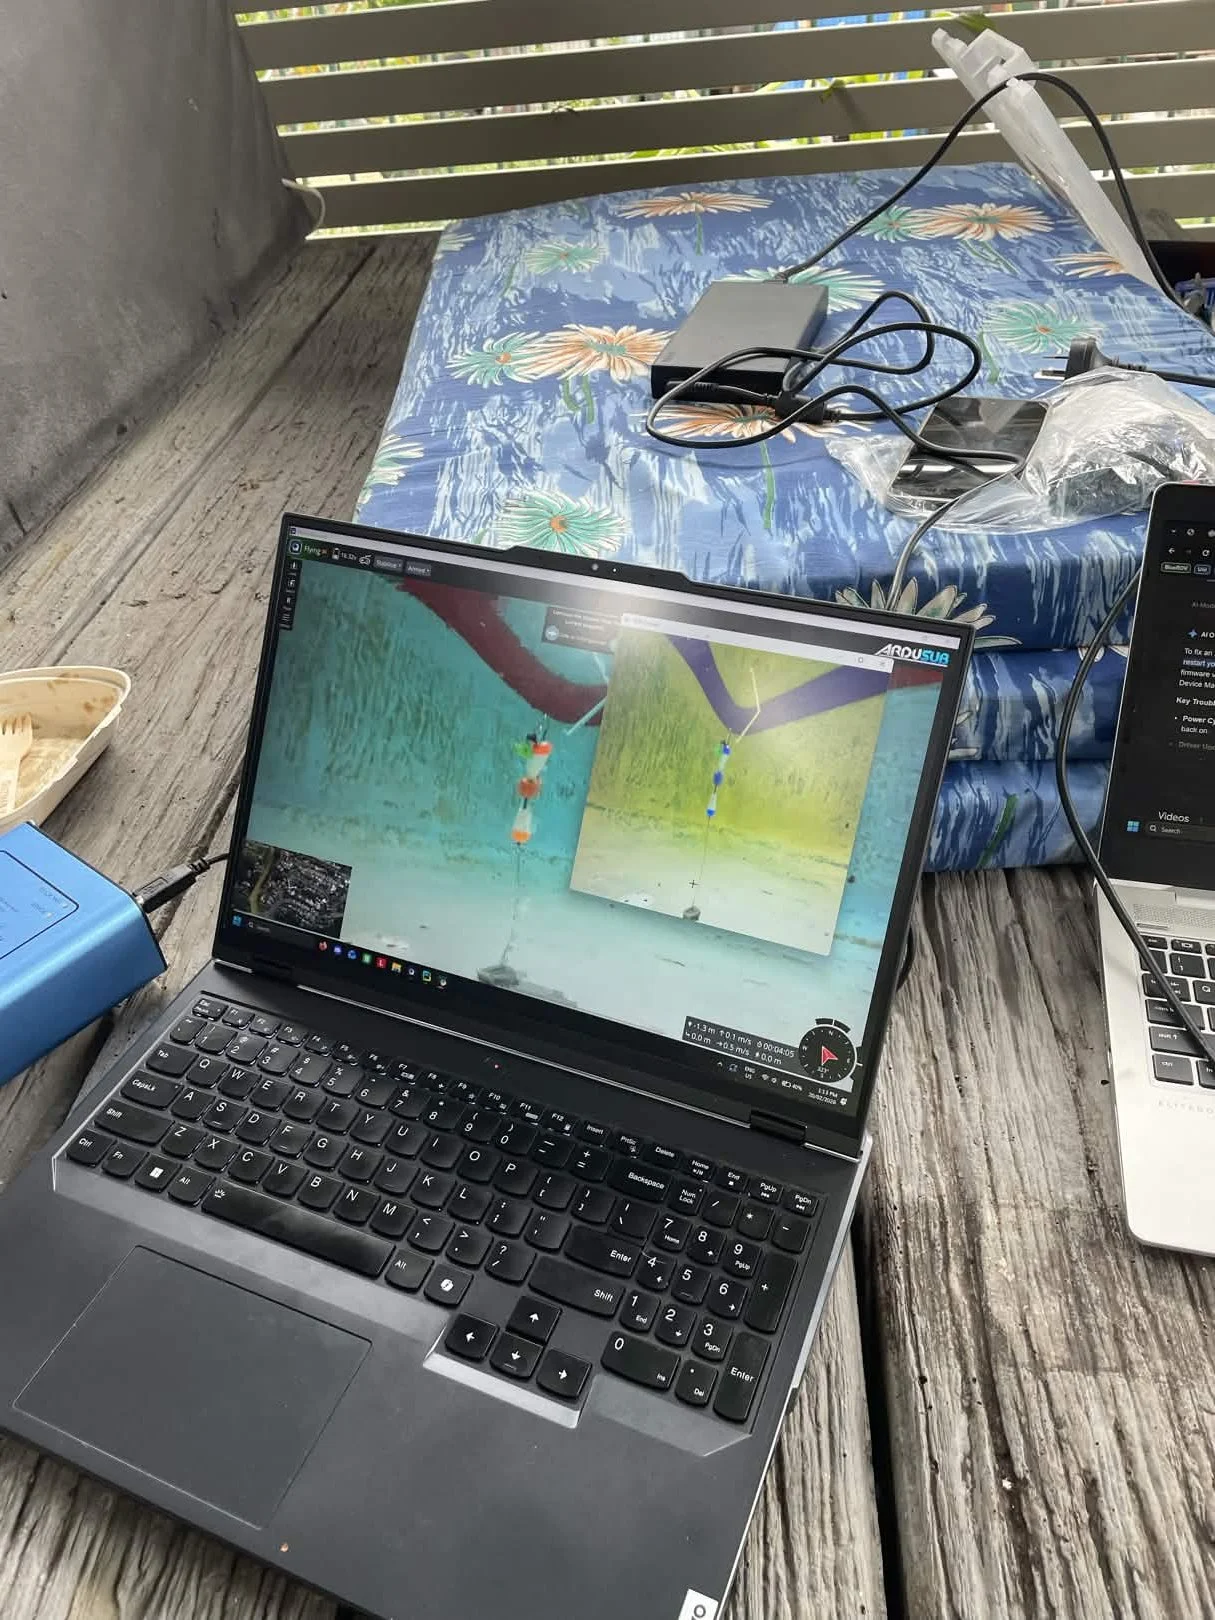
23rd Feb - 6th Mar 2026
Training camera vision model and research depth hold
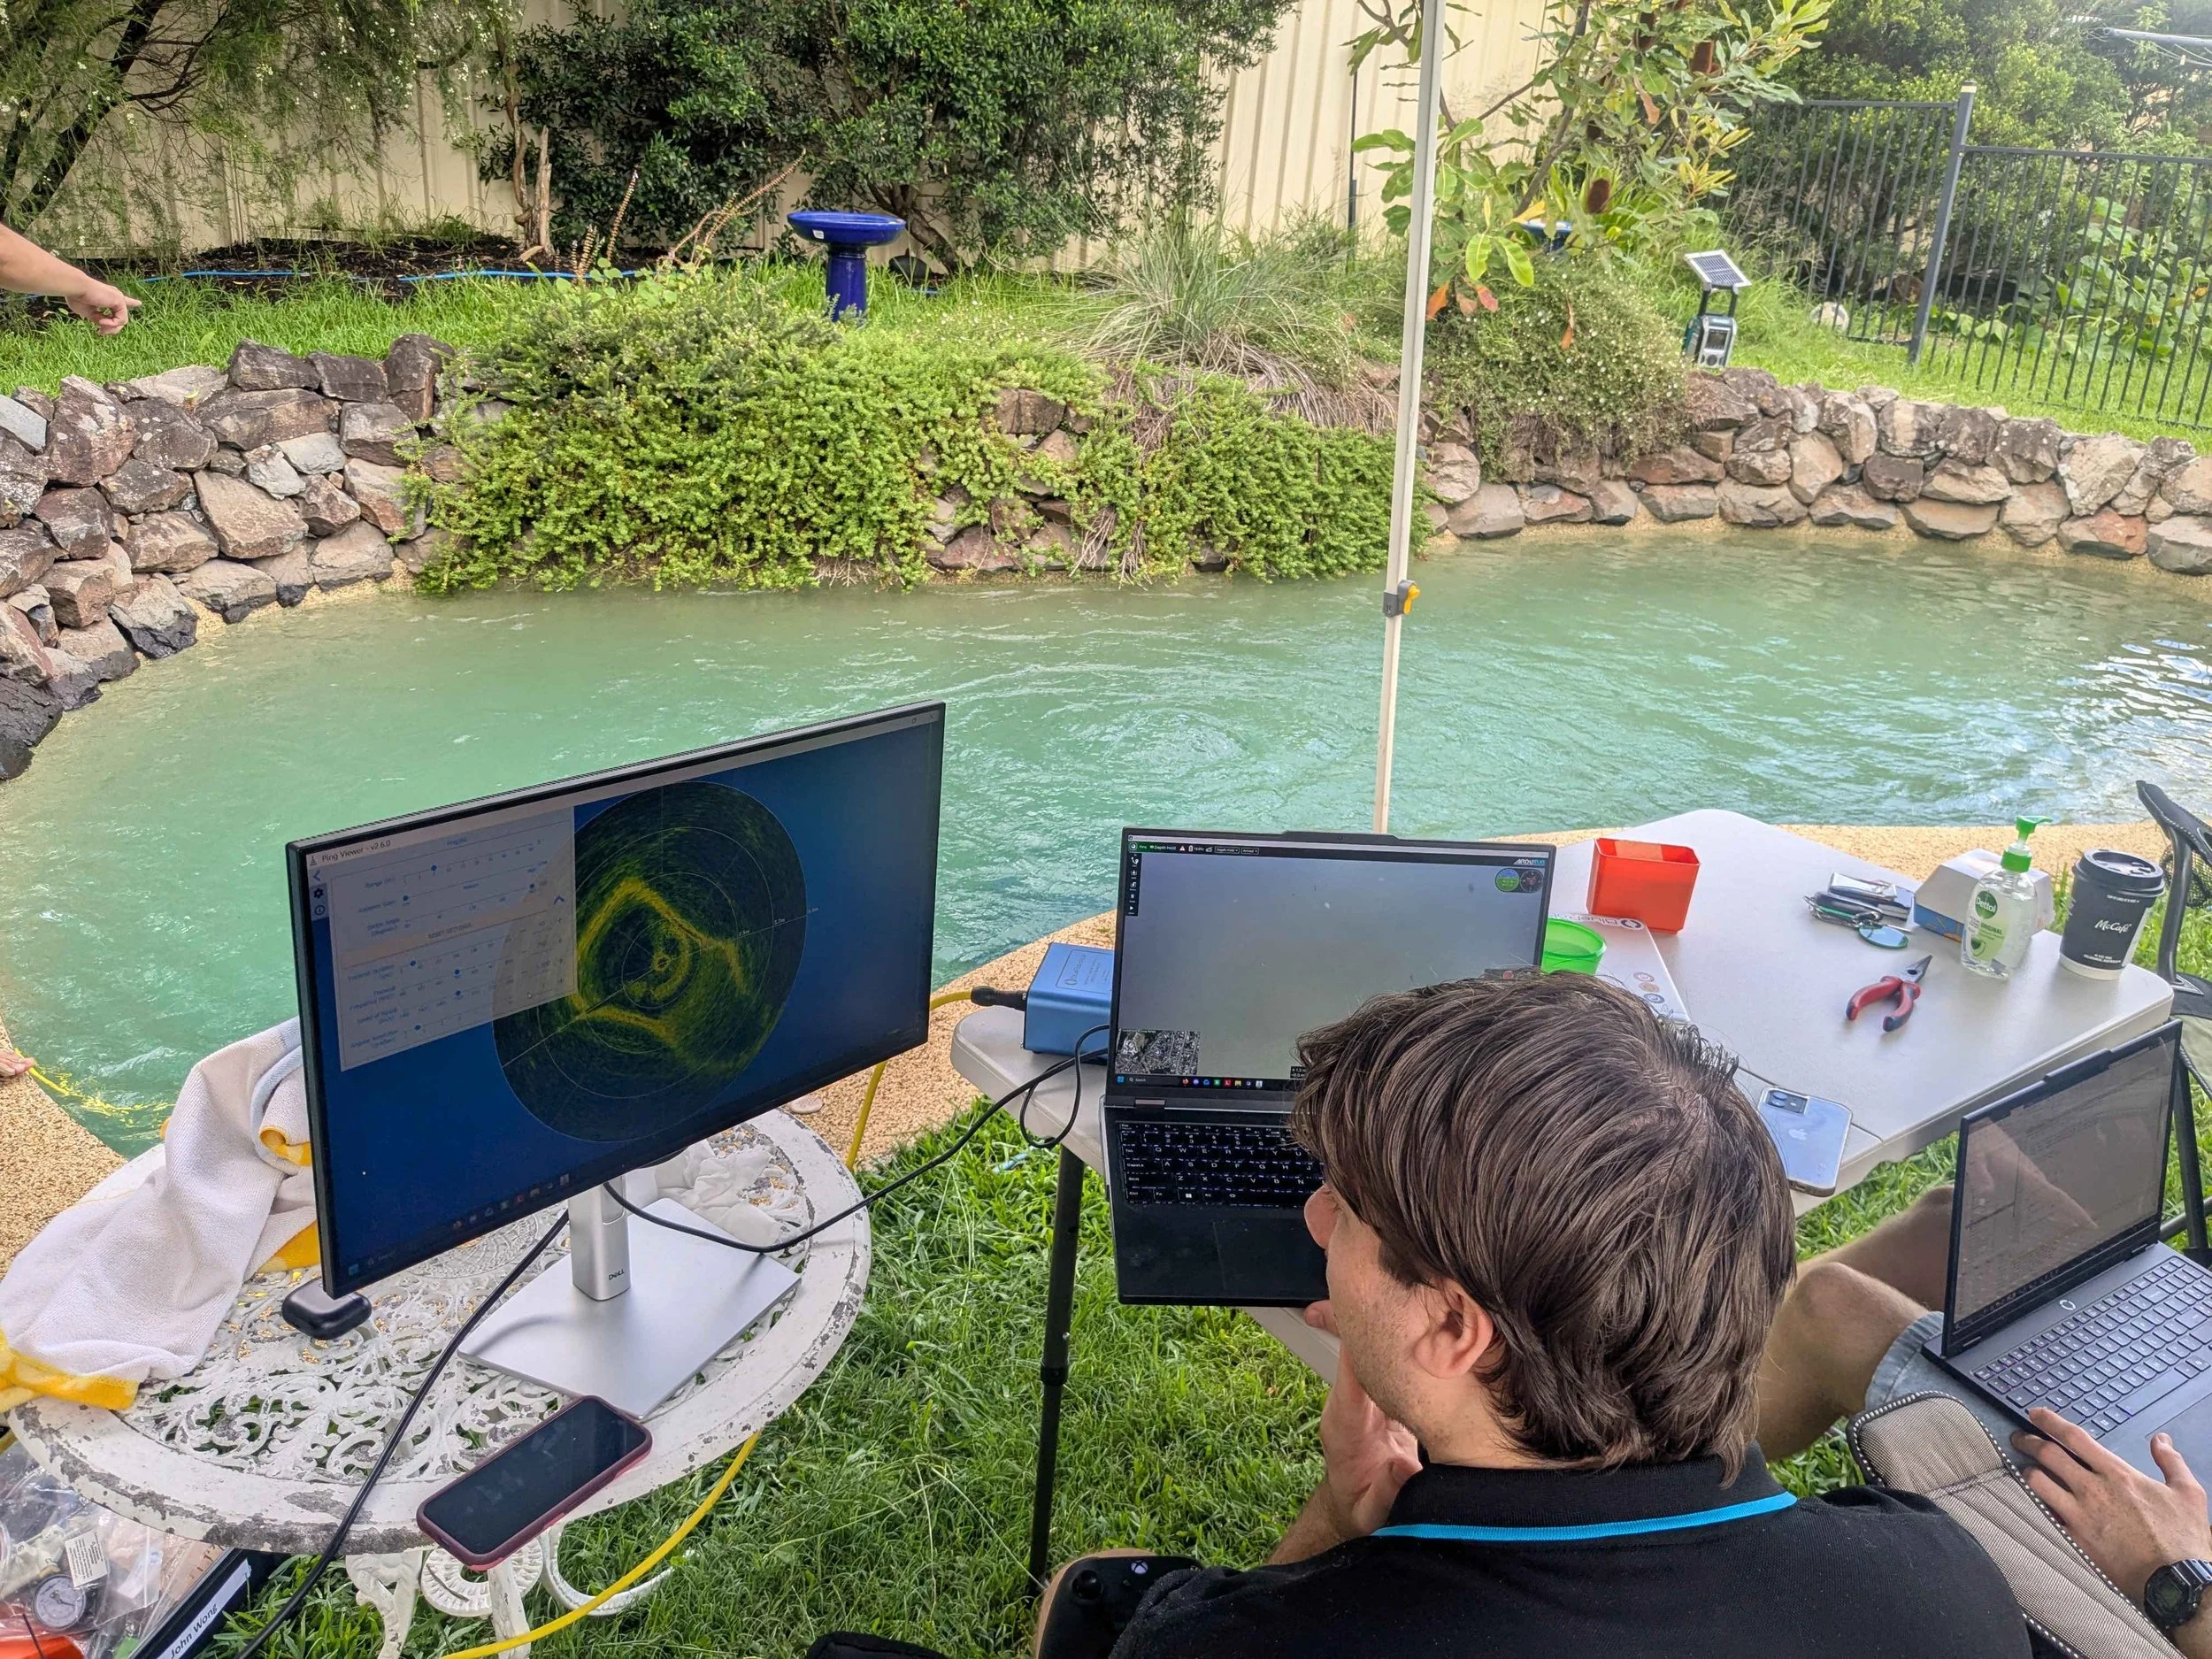
10th Mar 2026
SUB test day
Tune depth hold
Collect SONAR data of pipe in water
Training of camera vision model
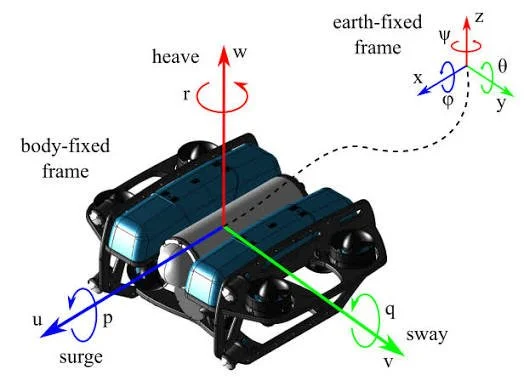
2nd Apr 2026
Research ability for BlueROV2 to hold a specified attitude
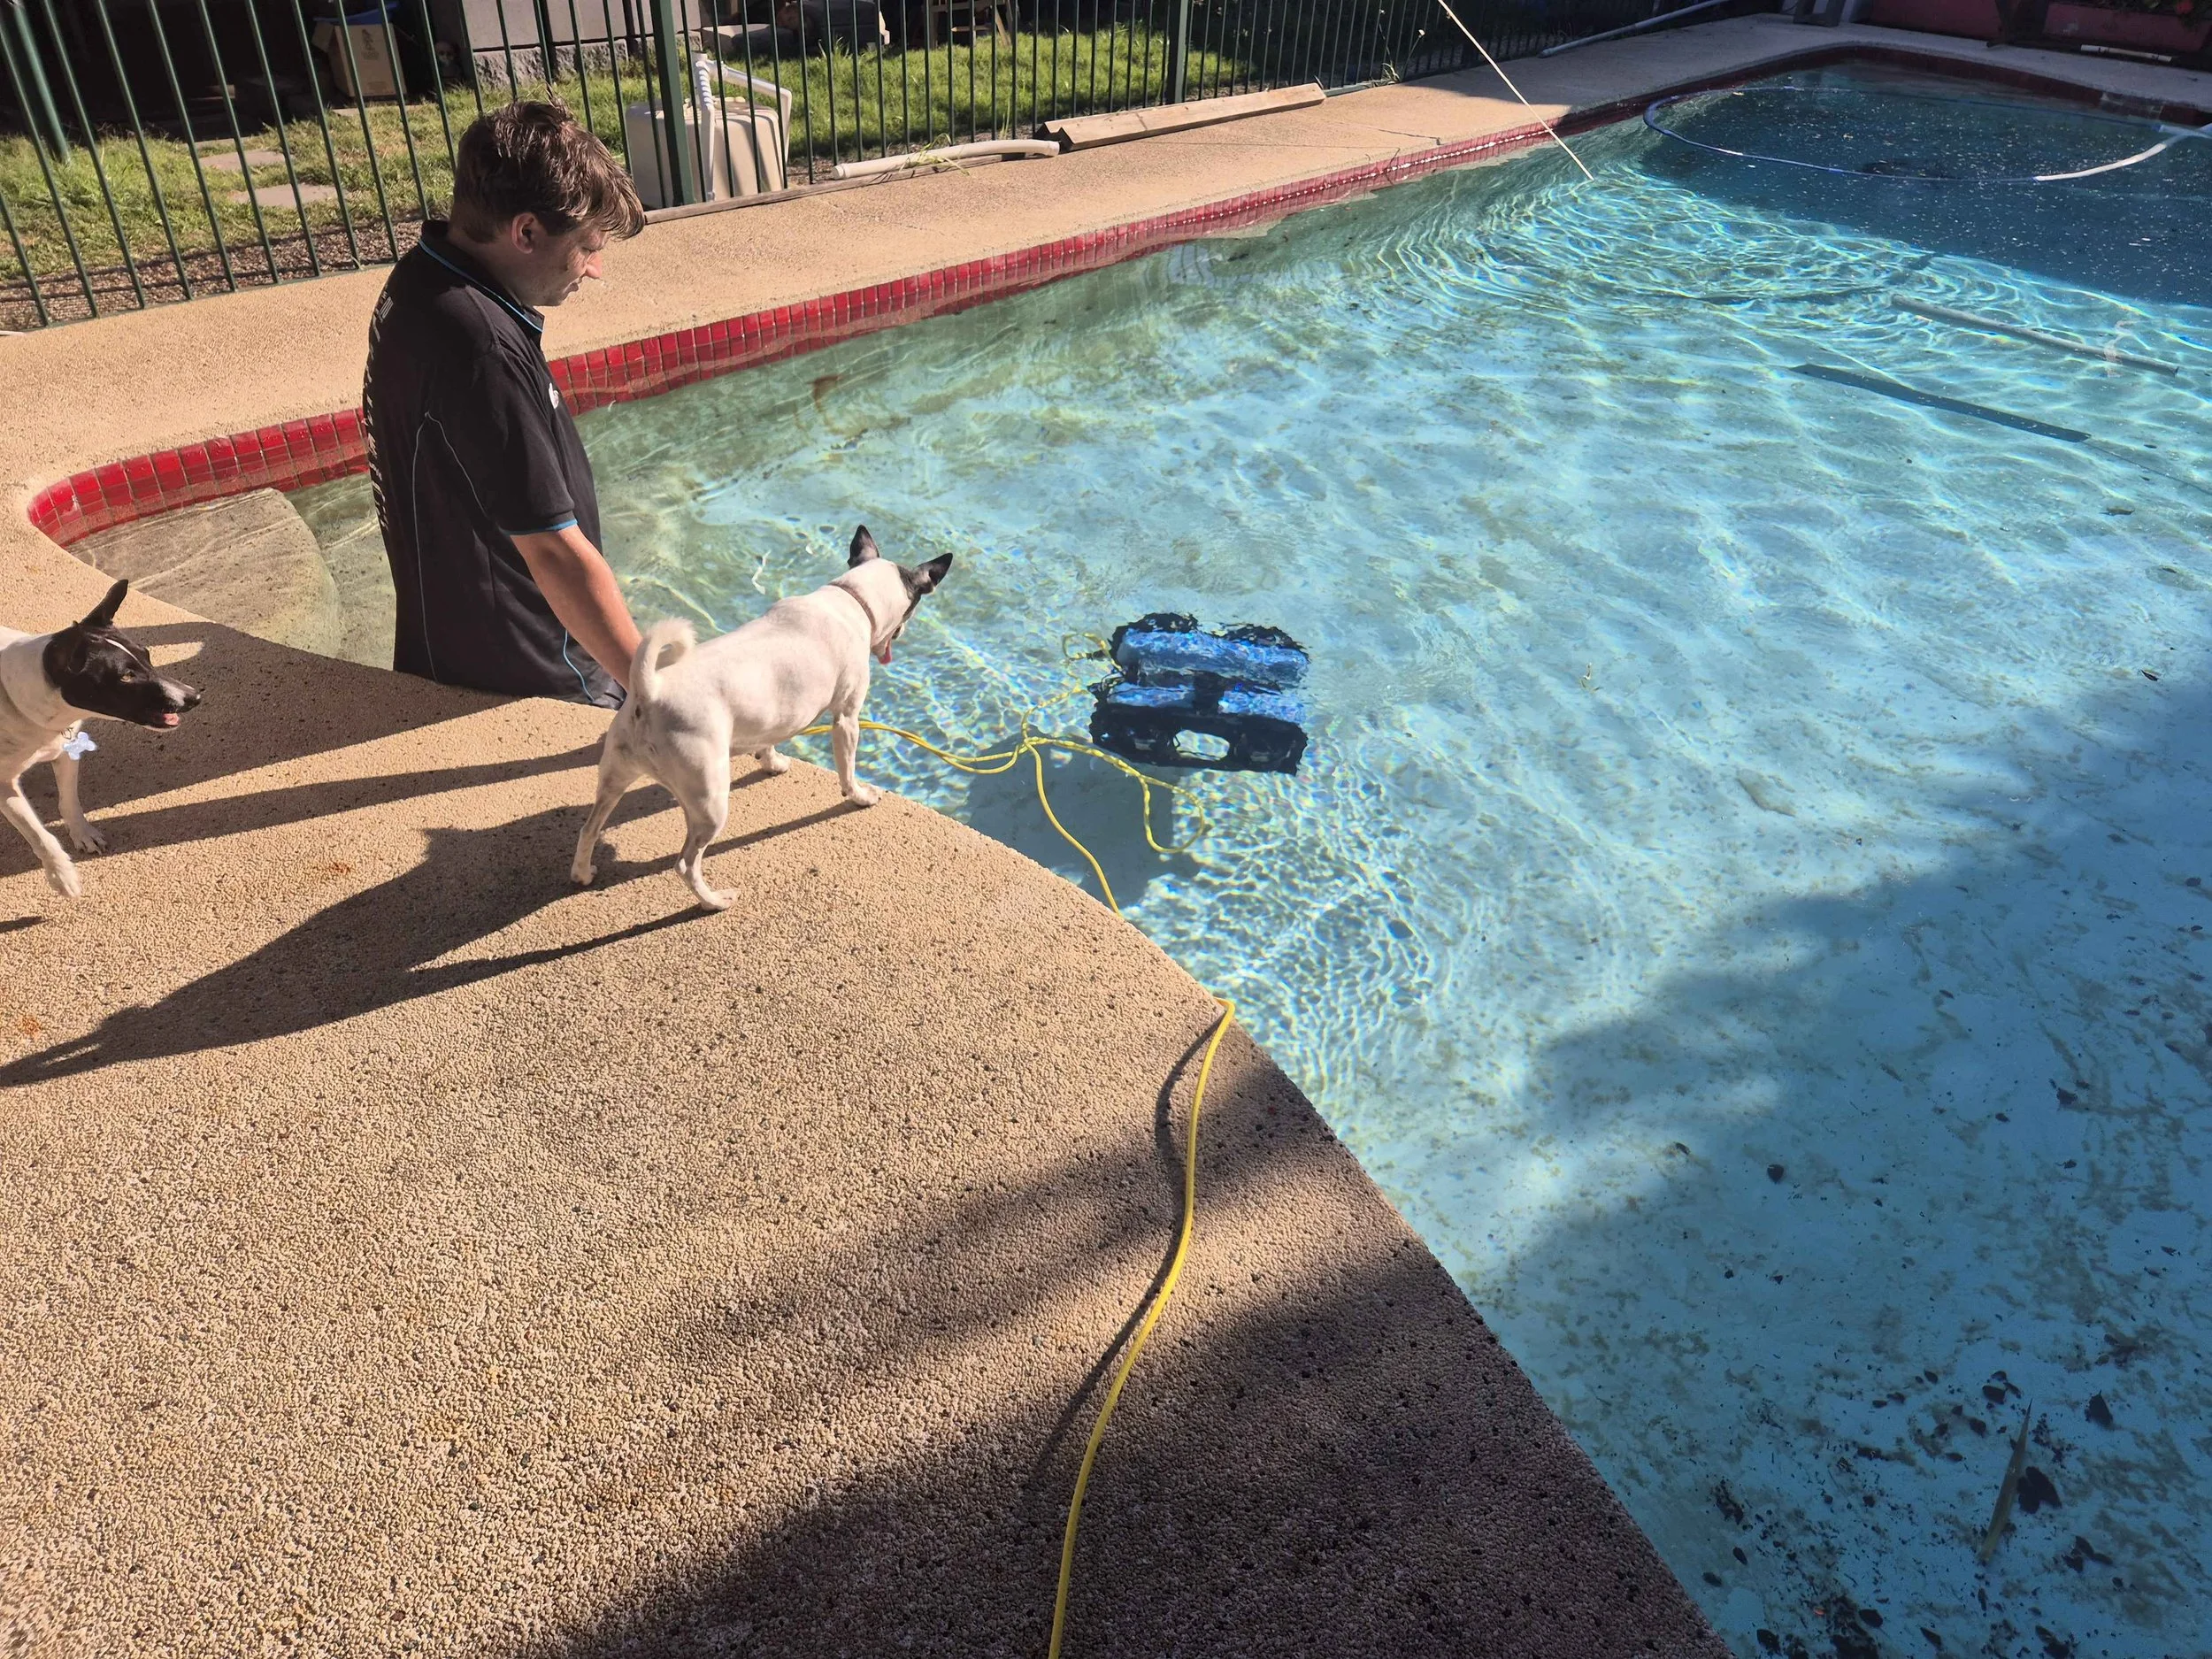
15th Apr 2026
SUB test day
Testing whether SONAR can detect pipe while not level (UUV is level when pitch = 0)
Velocity control of SUB motors using ROS node
Validated that SUB can detect and attempt to hold a specified attitude (however, position hold required additional sensors)
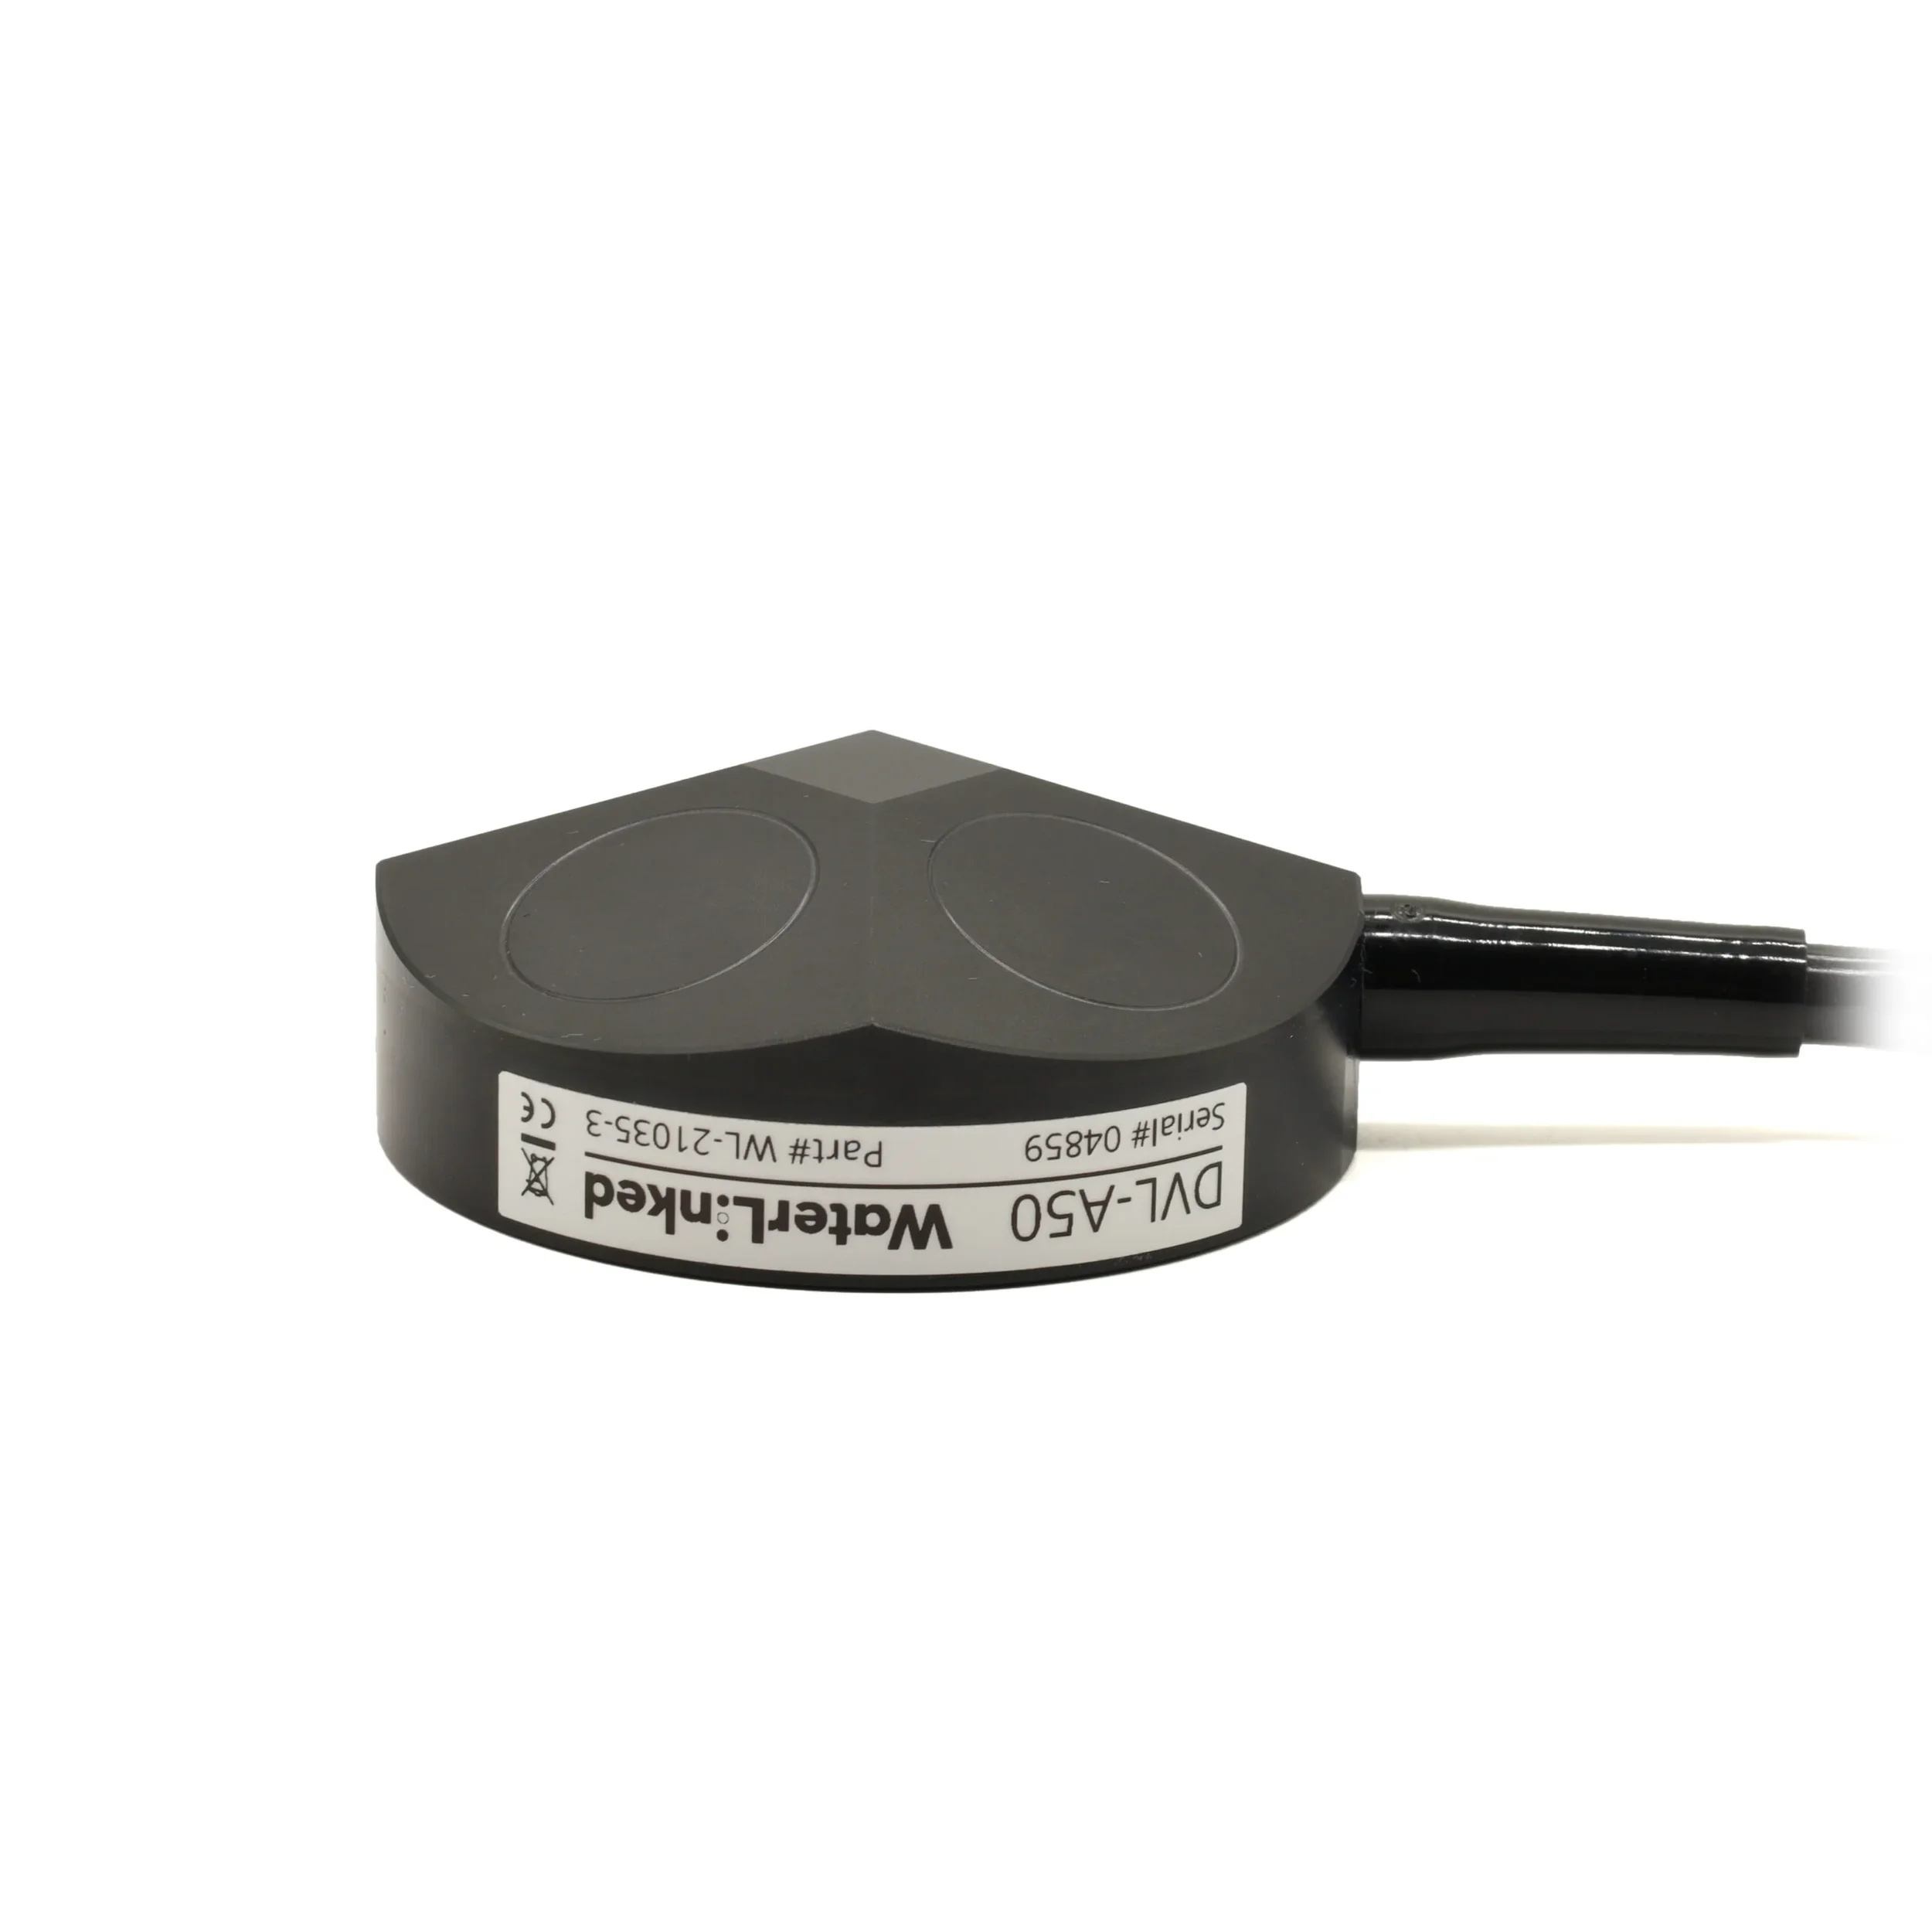
2nd Jul 2026
Mounted and tested Doppler Velocity Logger in our workshop
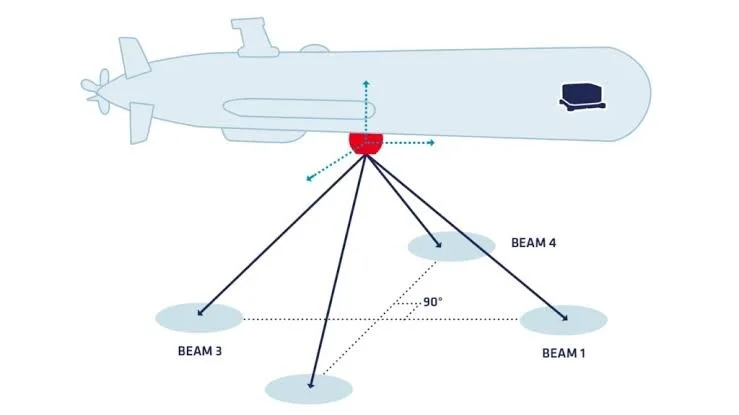
8th Jul 2026
SUB test day
Doppler Velocity Logger displays relative position and velocity
Flight controller enters auto mode and attempts to follow waypoints